
Product Short Description
Product Overview & Brief Introduction
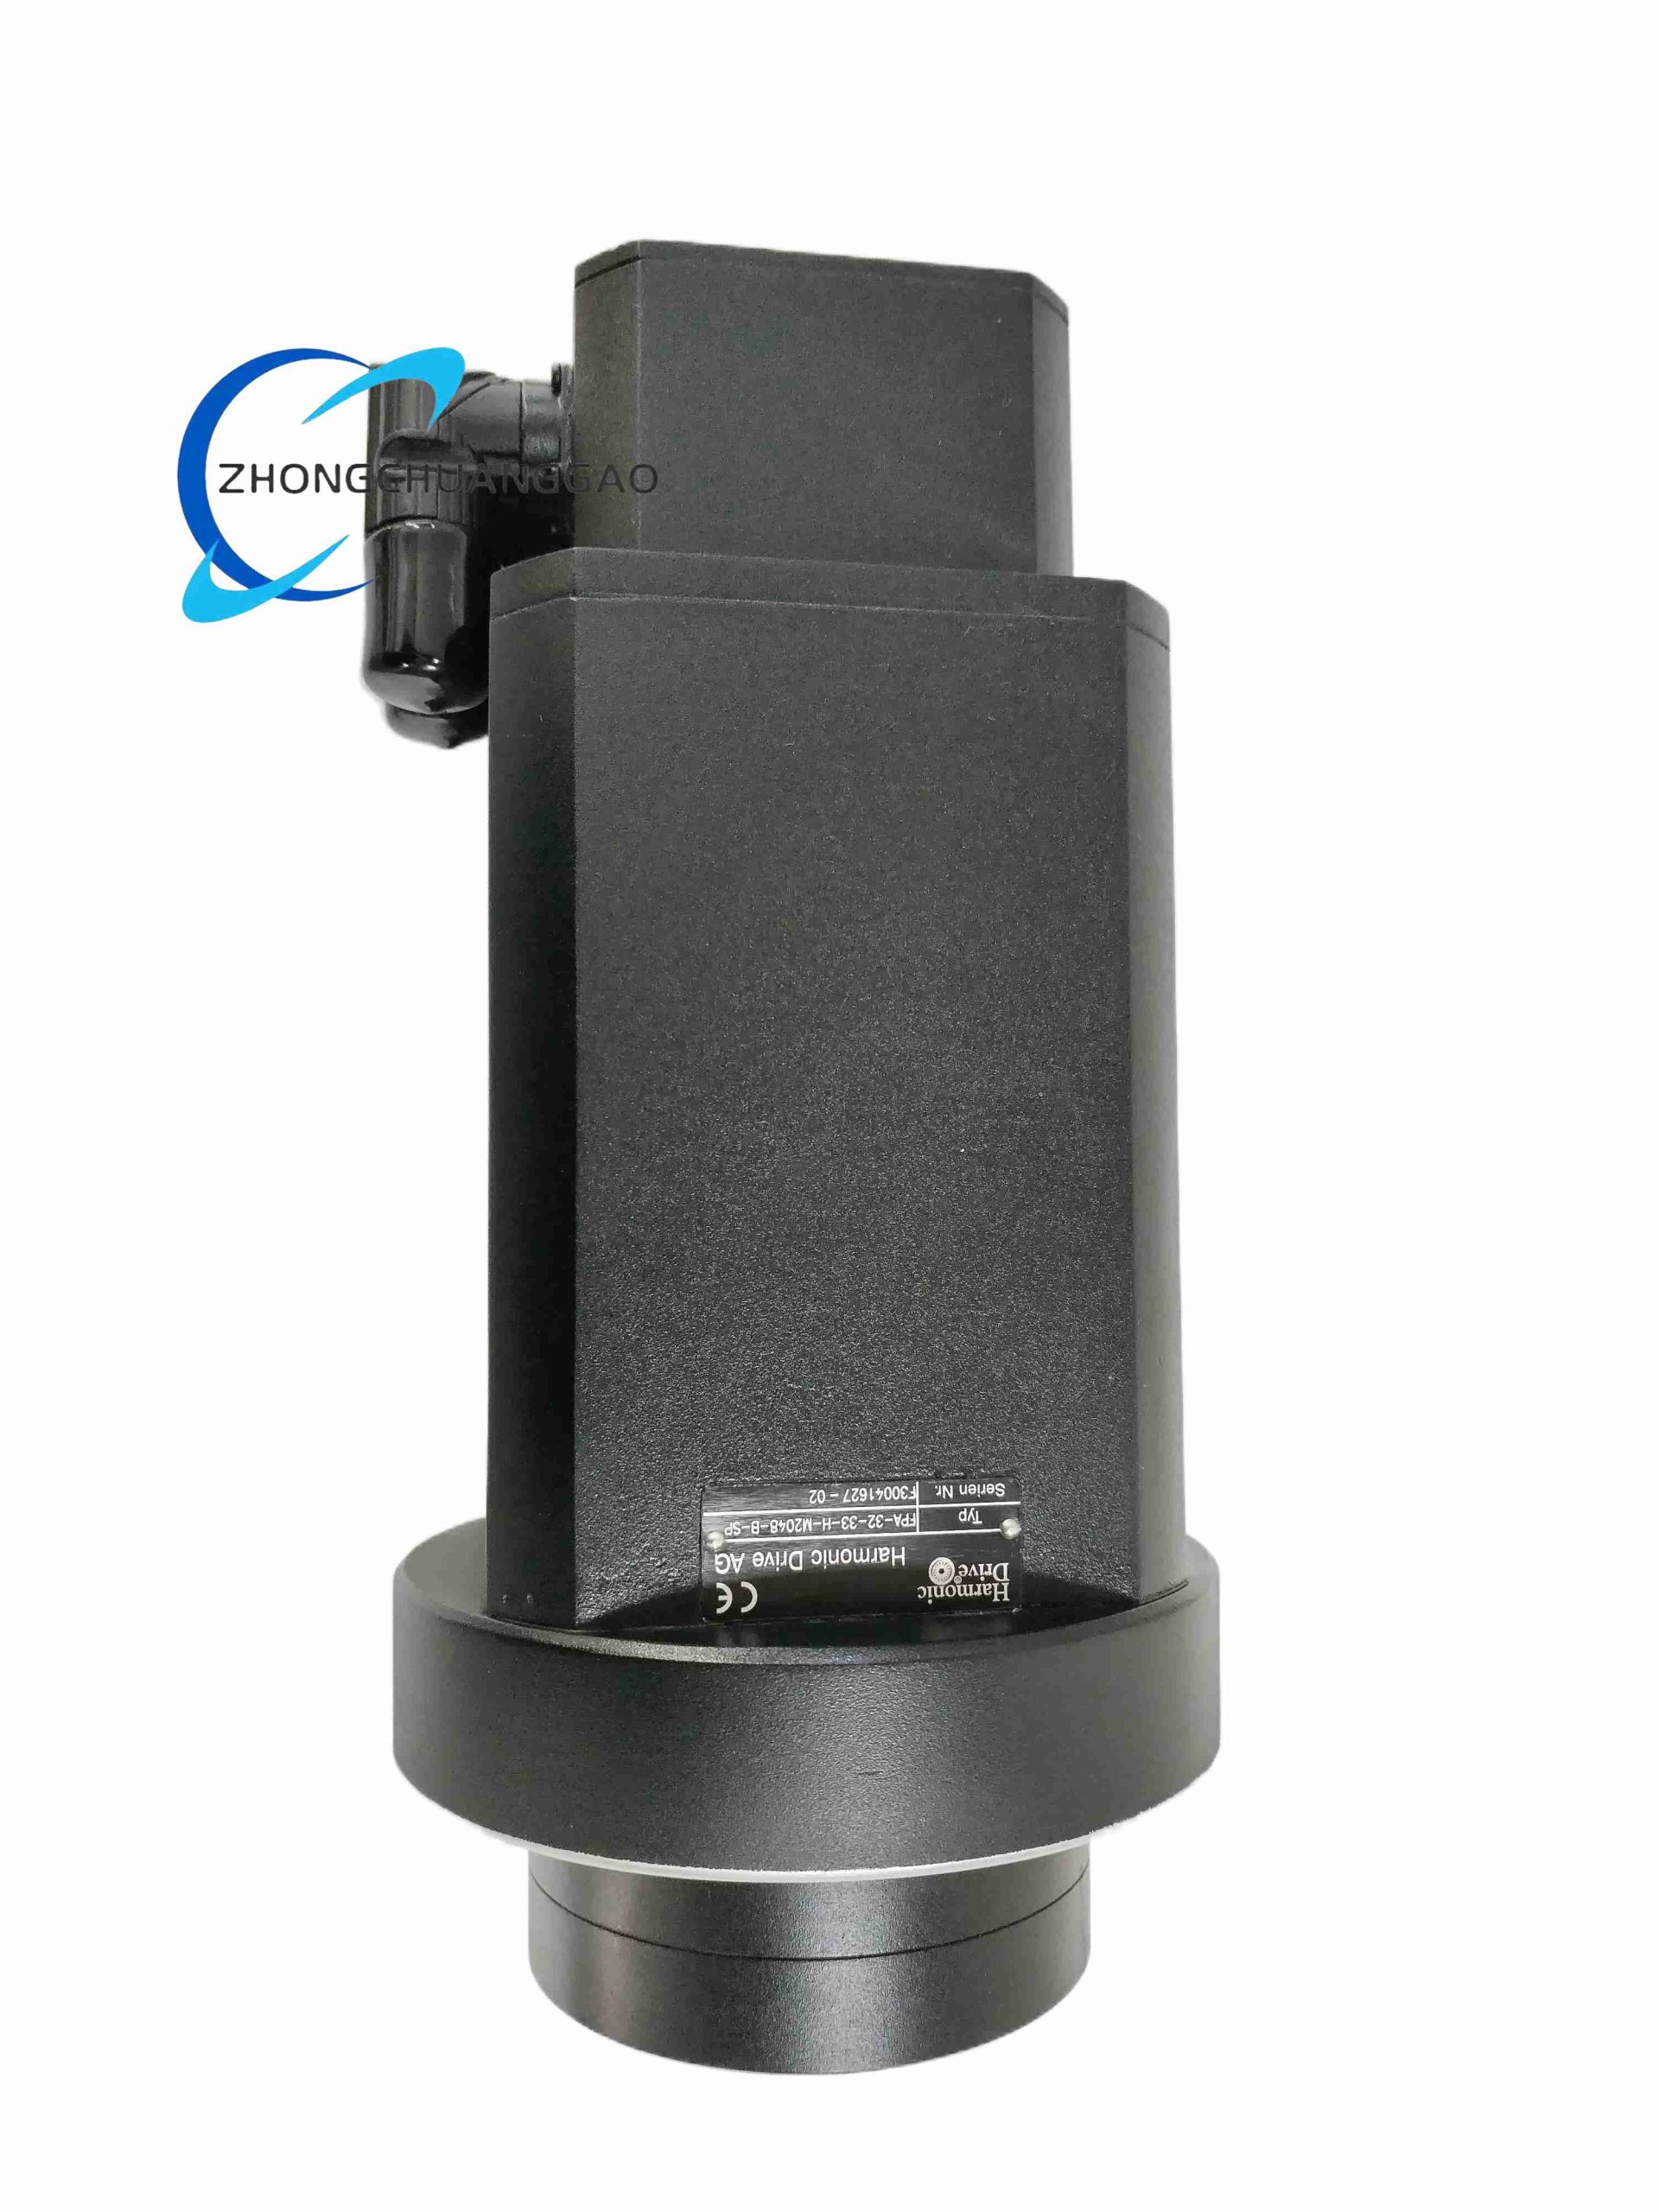
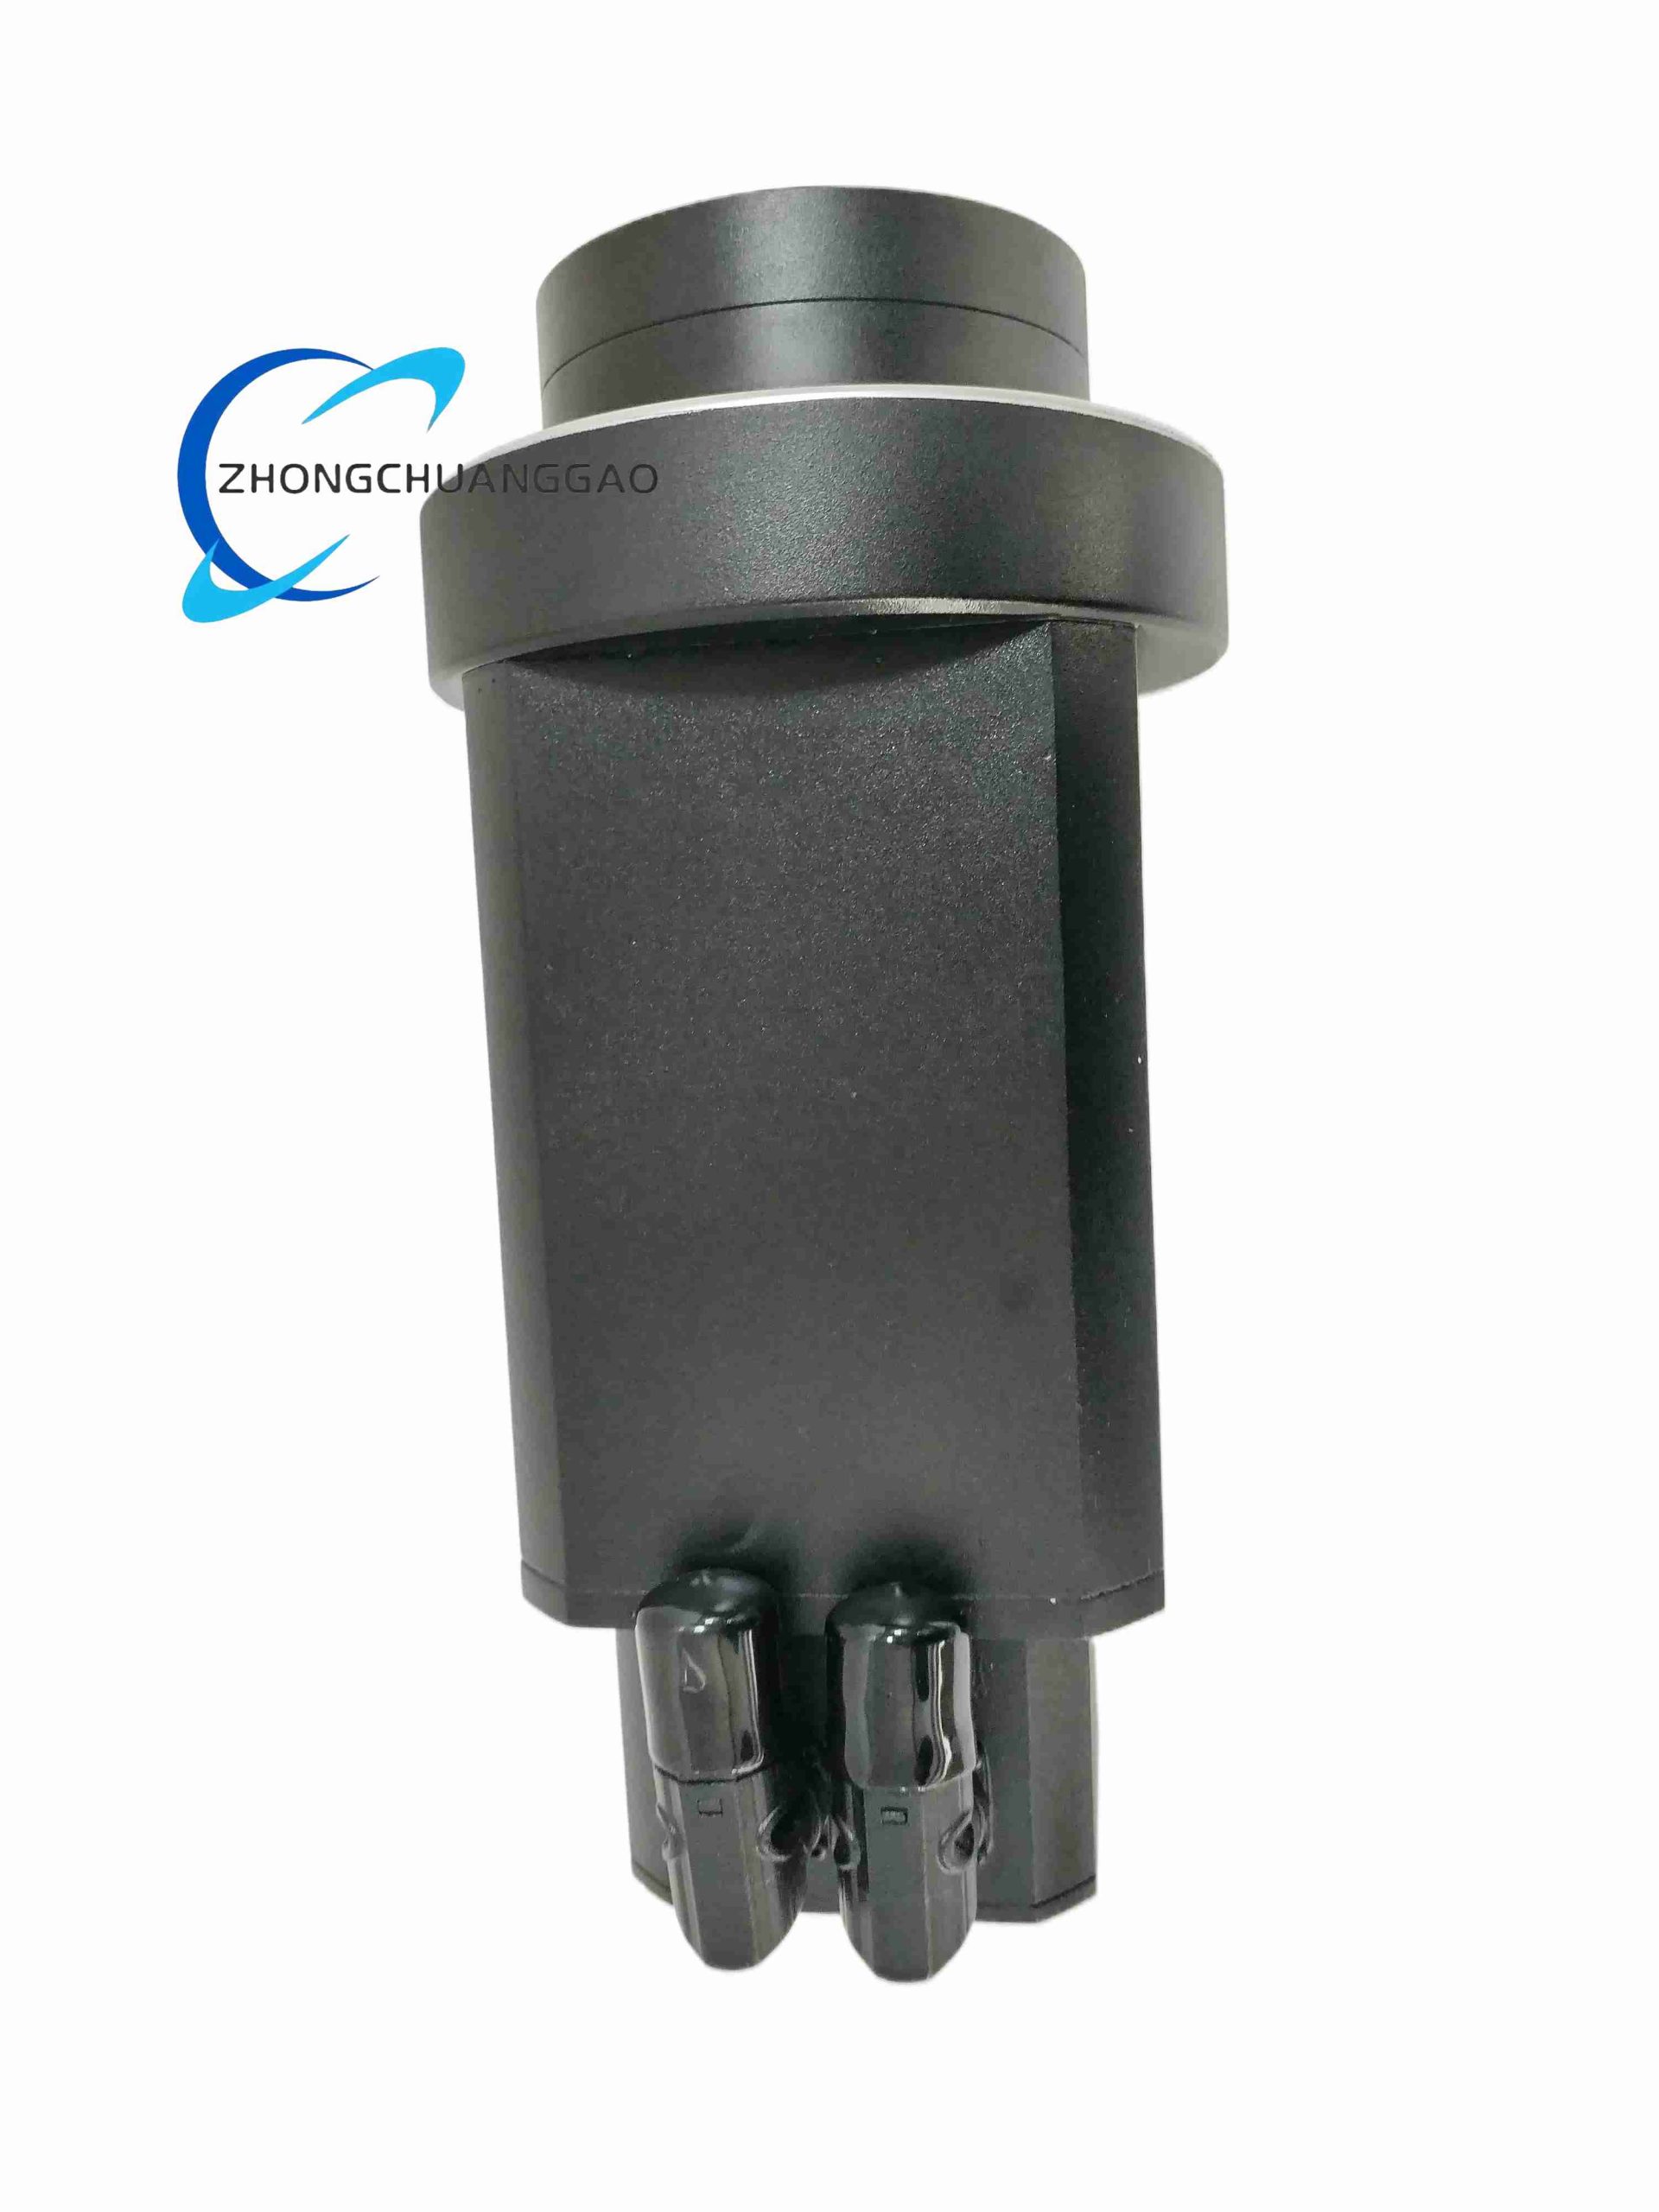
FPA-32-33 is a compact high-torque hollow-shaft AC servo actuator manufactured by Harmonic Drive, integrating precision strain wave harmonic gearing, brushless AC servo motor and absolute multi-turn position encoder into a single ultra-flat integrated unit. It delivers zero-backlash high-precision rotational positioning for industrial automation precision motion control applications requiring through-hole cable routing and compact footprint design.
Description
Core Technical Specifications & Performance Parameters
- Frame Size: FPA-32 standard 32mm motor frame
- Reduction Ratio: 33:1 strain wave harmonic gear reduction stage
- Rated Continuous Torque: 12 N·m continuous output torque
- Peak Instantaneous Torque: 30 N·m short-duration peak torque
- Maximum Output Rotational Speed: 120 RPM output shaft speed
- Position Feedback: Multi-turn absolute magnetic encoder (19-bit resolution)
- Backlash: ≤ 1 arc-min zero-clearance strain wave gearing
- Hollow Shaft Inner Diameter: 14mm through-hole for cable/air line routing
- Operating Temperature: 0°C ~ +40°C continuous duty
- Motor Supply Voltage: 200VAC three-phase servo drive power input
Function Features
- Ultra-flat integrated compact design combining motor, zero-backlash harmonic gearbox and absolute position encoder into one unit, eliminating separate motor/gearbox assembly alignment errors
- Large central hollow through-shaft allowing routing of pneumatic tubing, sensor cables and wiring through actuator center
- Multi-turn absolute encoder retains position coordinates after full power loss; no homing sequence required on system restart
- Zero backlash strain wave gearing delivers repeatable sub-arc-minute rotational positioning precision
- Low cogging torque brushless motor design for ultra-smooth slow-speed rotational motion without vibration
- IP54 standard enclosure protection against dust and light process water splashes
- Compatible with all Harmonic Drive HA series servo drive controllers for closed-loop motion control
Working Principle
Three-phase AC power from the servo drive energizes the integrated brushless stator windings, generating rotational magnetic torque on the motor rotor. Rotor rotation transfers motion into the strain wave harmonic gear reduction stage: flexible wave generator deformation drives the circular spline to deliver high torque, low-speed zero-backlash output rotation to the hollow output shaft. A multi-turn absolute magnetic encoder mounted directly to the output hollow shaft continuously measures rotational position and transmits high-resolution position feedback data back to the servo drive controller for closed-loop positioning control. The central hollow bore passes utilities through the actuator center without external cable routing interference.
Material Composition & Structural Characteristics
- Actuator Housing: Precision machined black anodized aluminum alloy front/rear housing flanges
- Harmonic Gear Components: High-strength alloy steel circular spline, flex spline, wave generator bearing assembly
- Motor Stator/Rotor: Silicon steel laminated stator core, rare-earth permanent magnet rotor
- Encoder Assembly: Sealed magnetic absolute encoder unit with stainless steel encoder disk
- Sealing Hardware: Fluorosilicone oil seals for internal gear lubricant retention
- Mounting Flange: Precision tapped aluminum mounting flange with standardized industrial robot bolt hole pattern
Installation Requirements
- Flange mounting via standardized front output flange bolt pattern; torque mounting fasteners to manufacturer specified 8N·m tightening torque
- Hollow shaft through-hole cable/tubing must maintain minimum 1mm clearance to avoid friction contact with rotating inner bore surface
- Install servo drive controller within 10-meter maximum cable length from actuator encoder connector
- Vertical or horizontal mounting permitted; lubrication maintenance cycle adjusted for vertical overhead mounting configurations
- For high-speed continuous operation, install auxiliary forced-air cooling fan to maintain housing temperature below 45°C
Application Scenarios
- Semiconductor wafer handling robotic arm joint precision rotary actuators
- Medical automated lab equipment rotary positioning stages
- Precision optical inspection turntable closed-loop positioning drives
- Electronics assembly pick-and-place rotary axis servo units
- Aerospace test bench low-backlash precision rotation actuators
Usage Precautions
- Never exceed 30N·m peak torque rating for continuous operation; peak torque limited to <5 second intermittent duty cycles
- Avoid side radial loading on hollow output shaft; use separate support bearings for offset external load masses
- Schedule factory-specified grease re-lubrication every 5,000 operating hours to prevent harmonic gear flex spline wear
- Protect actuator hollow shaft bore from metal shavings, dust and liquid contamination during machine assembly
- Do not perform rapid full-directional rotation reversals at maximum peak torque to extend gear service life
Reviews
There are no reviews yet.