
Product Short Description
Product Introduction:
The 8MSA3L is a compact, low‑inertia permanent‑magnet synchronous servo motor from B&R’s 8MSA family, with a frame size 3 (flange approx. 80×80 mm). The “L” denotes a low‑inertia variant optimised for high‑dynamic, high‑frequency cyclic motion. It integrates an absolute encoder for battery‑free position retention.
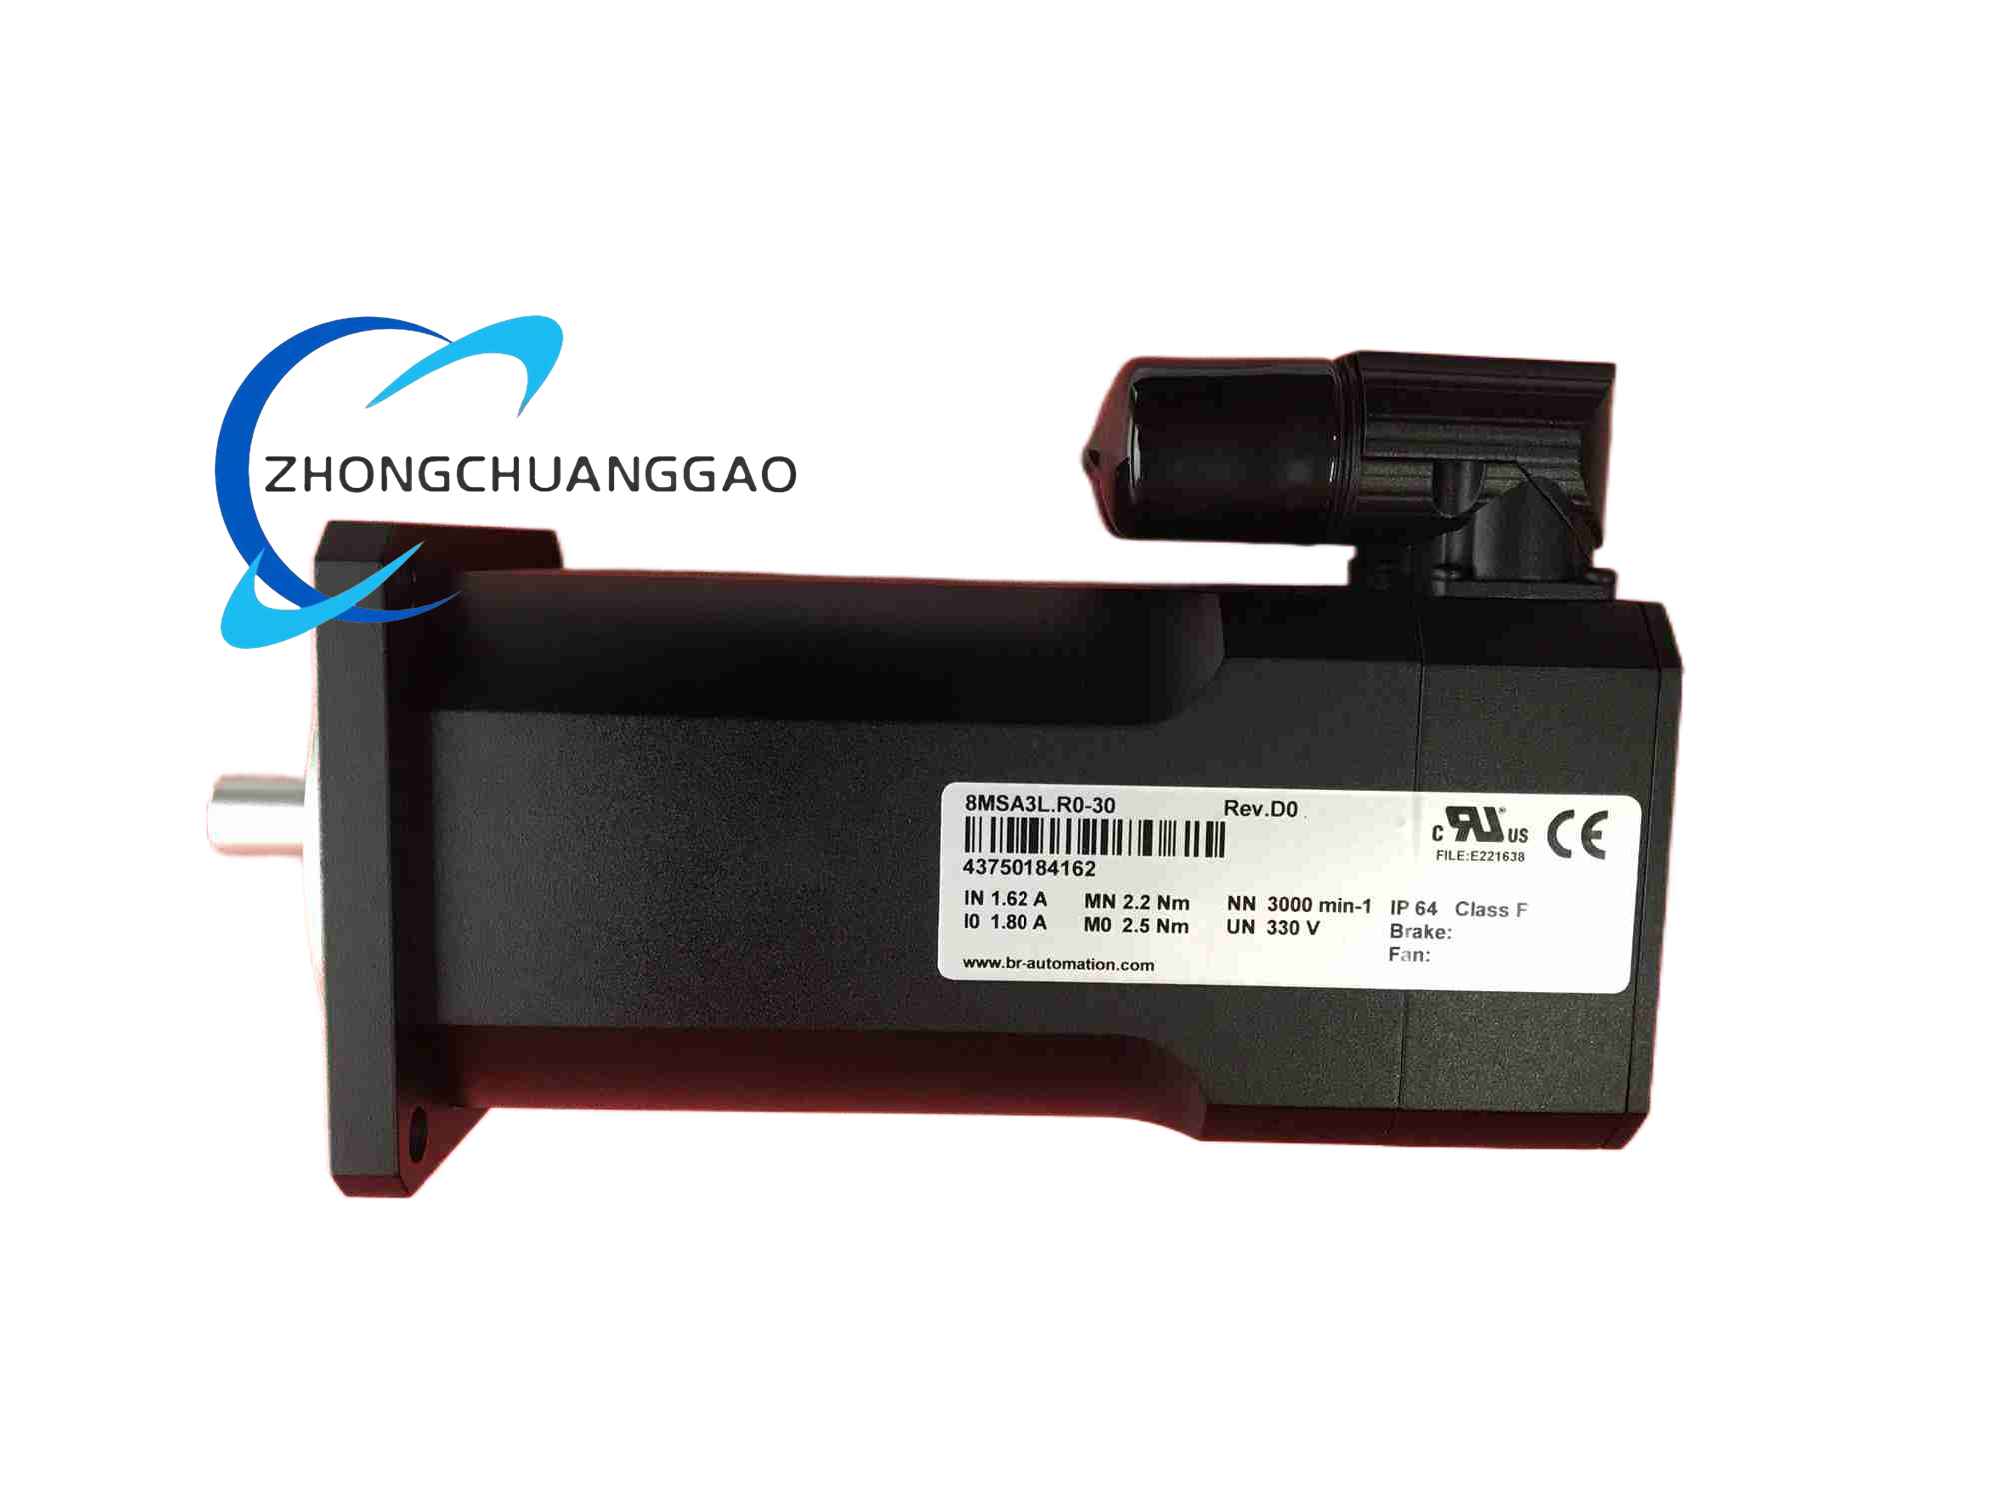
Description
Technical Specifications (representative 8MSA3L.E0‑31):
|
Parameter
|
Value
|
|---|---|
|
Flange size
|
80 × 80 mm (Frame 3)
|
|
Rated power (est.)
|
0.4–0.85 kW
|
|
Rated torque (est.)
|
2.7–3.2 Nm @ 3000 rpm
|
|
Peak torque (est.)
|
Up to 8.1 Nm (short‑term)
|
|
Maximum speed
|
4500–6000 rpm (variant dependent)
|
|
Feedback
|
Multi‑turn absolute encoder (EnDat 2.2 or Hiperface DSL, 17‑bit single‑turn + 12‑bit multi‑turn)
|
|
Shaft type
|
Smooth shaft or single keyway (DIN 6885)
|
|
Holding brake
|
None (–31 variant)
|
|
Cooling
|
Natural convection (self‑cooling)
|
|
Protection class
|
IP65 (shaft end), IP54 (rear cover)
|
|
Insulation class
|
F (155 °C)
|
|
Temperature sensor
|
PTC/KTY84 integrated
|
|
Mounting
|
IEC B5 flange (4× threaded holes)
|
|
Operating temperature
|
0–40 °C (standard), –15 to 55 °C (extended)
|
|
Humidity
|
5–95 % non‑condensing
|
|
Certifications
|
CE, UL, cUL, RoHS, EAC
|
|
Compatible drives
|
B&R ACOPOS 8 / ACOPOS 1045 / ACOPOS 1090 series
|
|
Magnet material
|
Surface‑mounted NdFeB, sine‑wave commutation
|
Functional Features:
-
Low rotor inertia for extremely fast acceleration/deceleration cycles
-
Absolute encoder retains position after power loss – no homing required
-
Battery‑free absolute feedback (EnDat 2.2) reduces maintenance
-
Compact 80×80 mm footprint for space‑constrained installations
-
Auto‑recognition of motor parameters via B&R Automation Studio
-
IP65 shaft end seal protects against dust and water ingress
Material & Structural Characteristics:
-
Stator: Grain‑oriented silicon steel laminations, 0.35 mm thickness
-
Rotor: NdFeB permanent magnets, surface‑mounted for smooth sinusoidal back‑EMF
-
Housing: Aluminium alloy, anodised
-
Shaft: Hardened alloy steel, chrome‑plated, optional keyway
-
Bearings: Sealed deep‑groove ball bearings, grease‑lubricated
-
Connectors: M23 circular connectors for power and encoder (gold‑plated contacts, IP67)
Working Principle:
Three‑phase permanent‑magnet synchronous motor with sine‑wave PWM drive from the ACOPOS inverter. The absolute encoder continuously reports rotor position to the drive, enabling field‑oriented control (FOC) for precise torque and speed regulation.
Application Scenarios:
-
Small robot joints and articulated arms
-
Feeder axes in packaging machinery (high cyclic rate)
-
Cross‑seal and longitudinal‑seal drives in flow wrapping
-
Tension roller control in printing and converting
-
Semiconductor wafer handling and pick‑and‑place
Installation Requirements:
-
Mount on a rigid, flat surface using four M5 bolts (torque 2.5 N·m)
-
Ensure minimum 50 mm clearance around the motor for airflow
-
Use shielded cable for both power and encoder connections
-
Grounding resistance must be ≤ 1 Ω
-
For variants with brake, connect brake power via dedicated drive output
-
Ambient temperature: –10 °C to +55 °C
Usage Precautions:
-
Do not exceed rated peak current for more than 5 seconds
-
Do not disassemble the encoder housing – calibration will be permanently lost
-
Ensure proper cable strain relief at the M23 connector to prevent fatigue failure
-
Regularly inspect bearing condition after 10,000 operating hours
-
Do not operate in corrosive atmospheres without additional enclosure
-
The low‑inertia design is sensitive to load mismatches; verify inertia ratio with drive during commissioning

Reviews
There are no reviews yet.