
Product Short Description
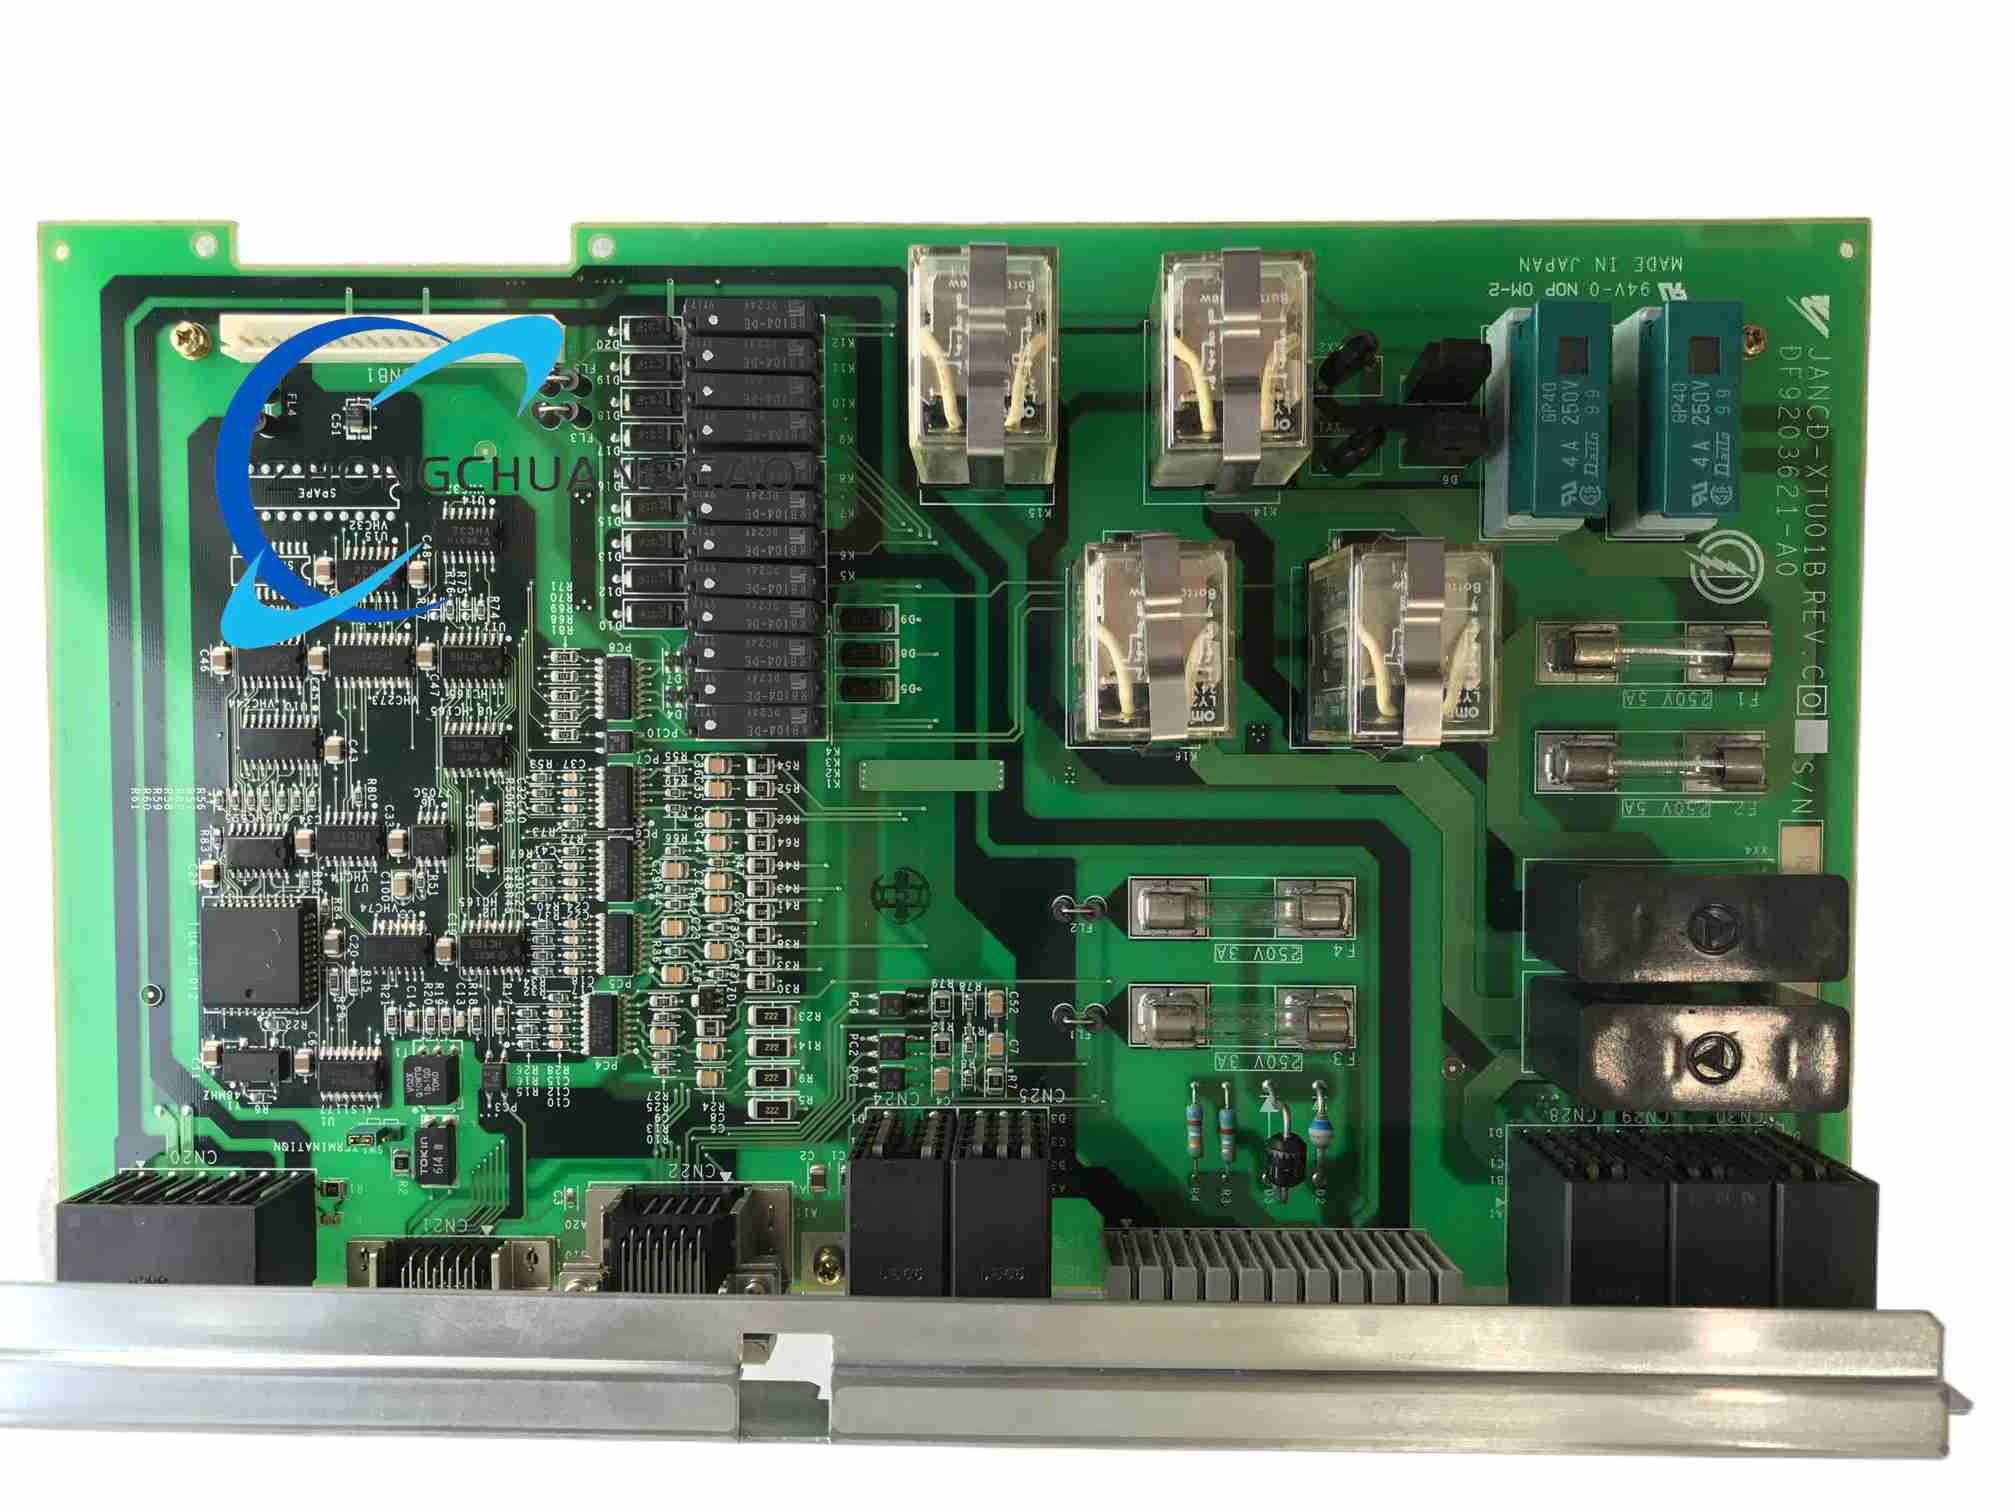
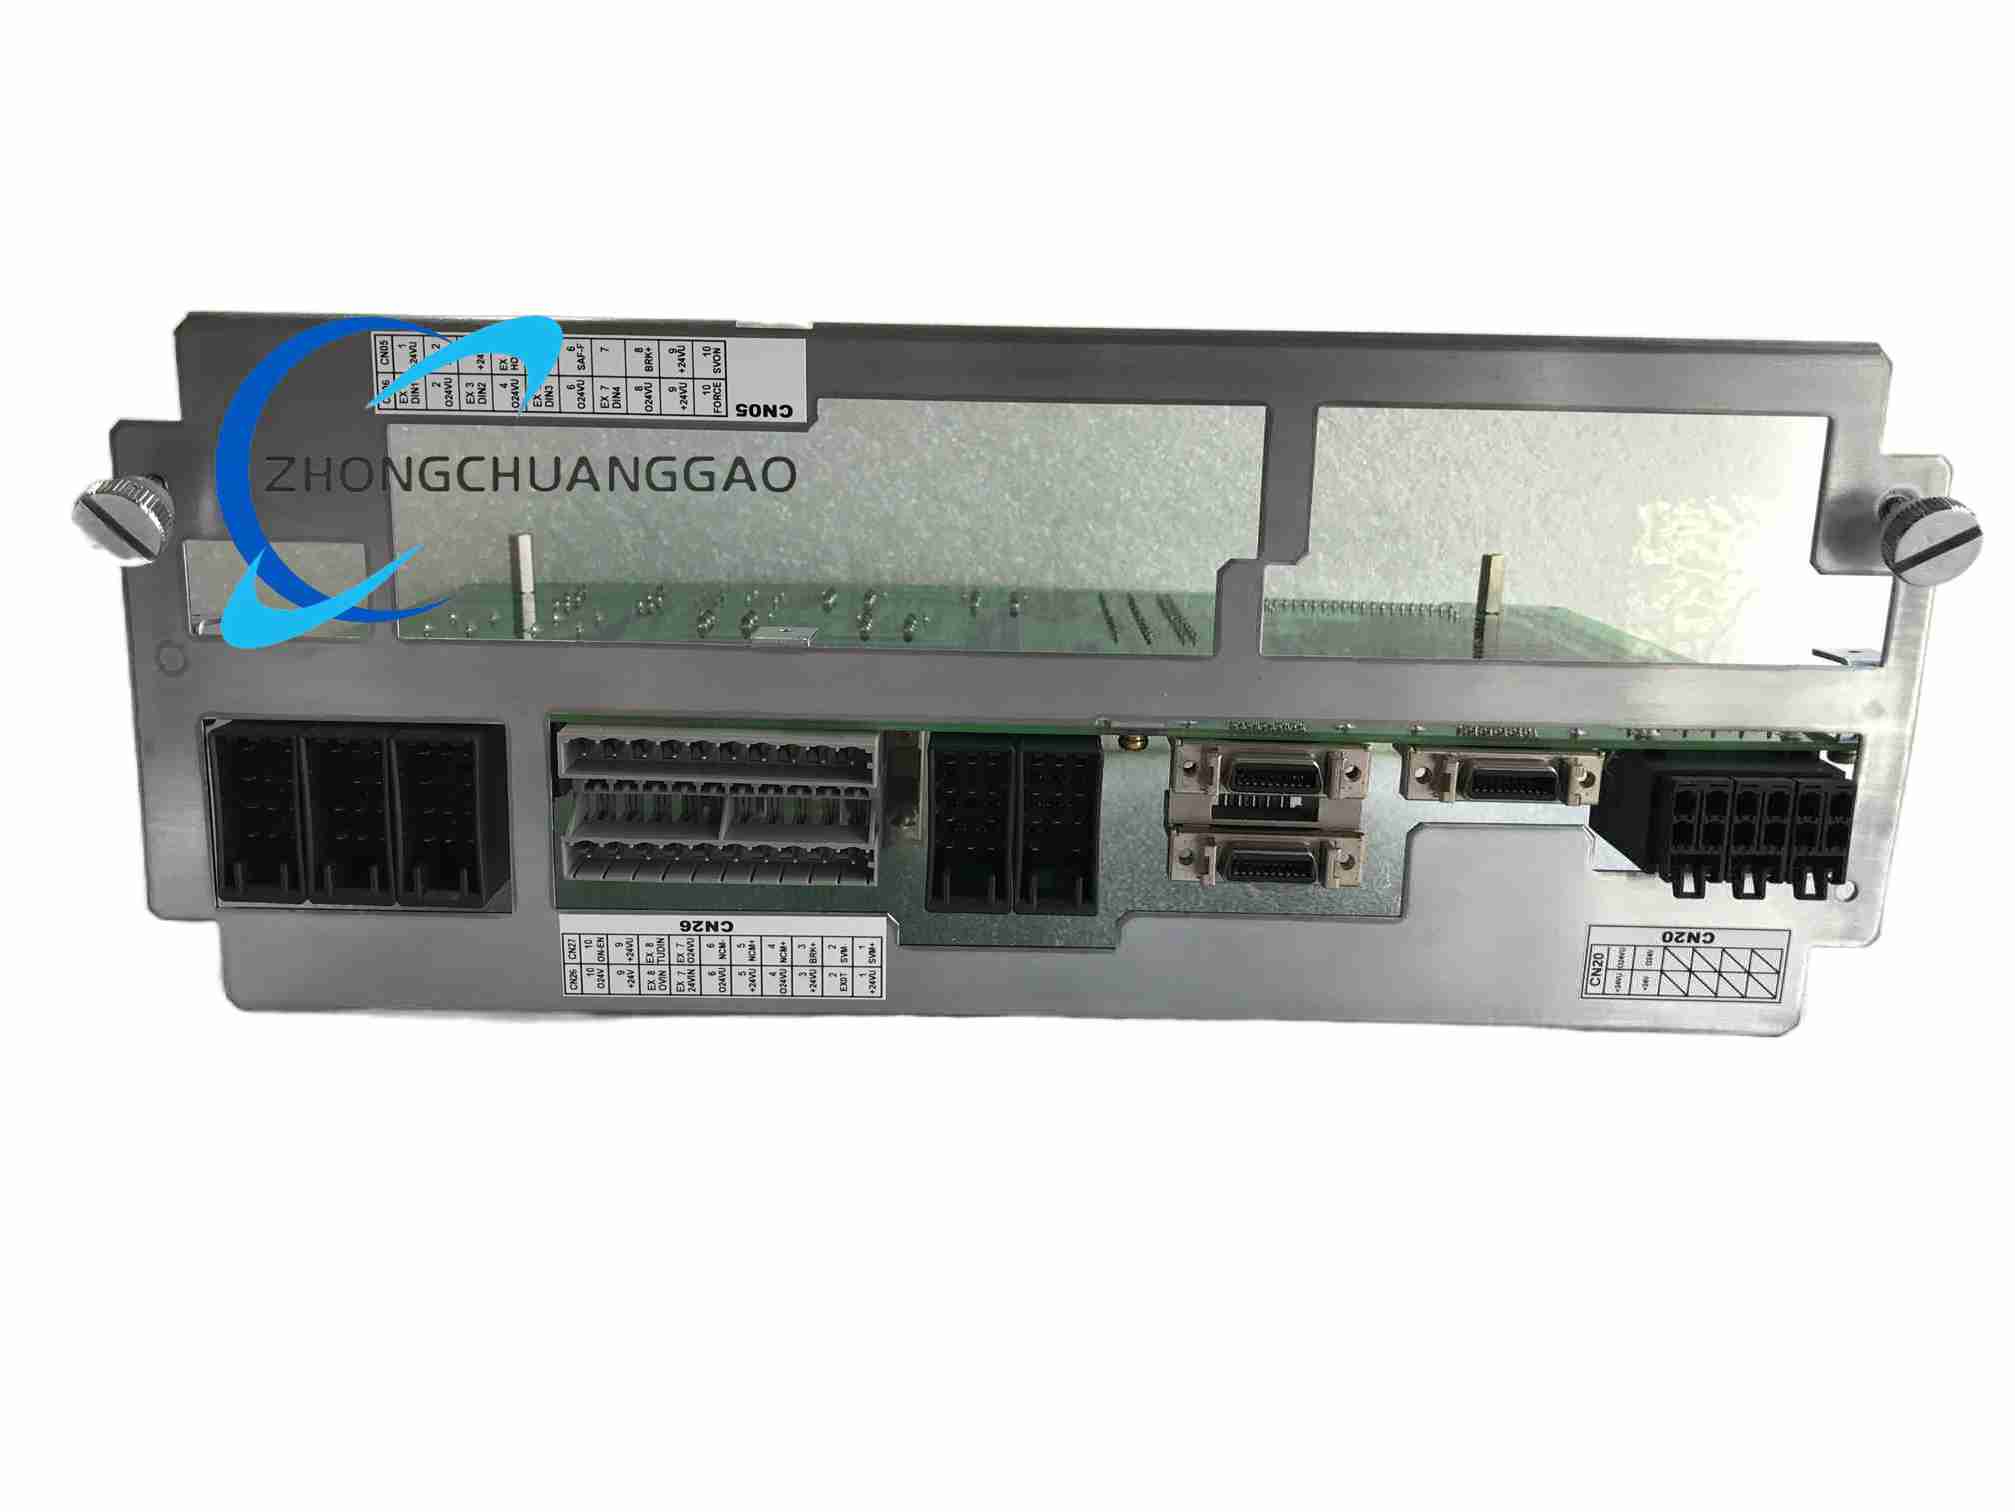
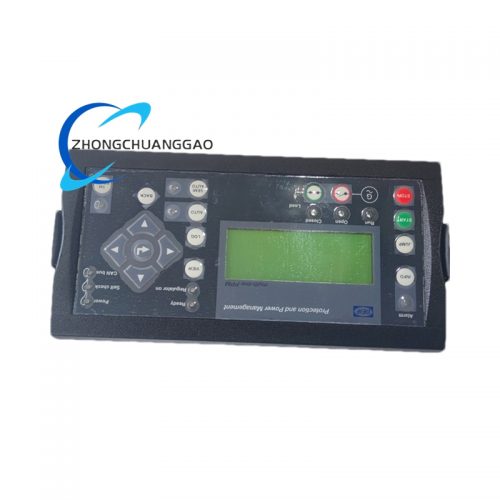
Product Name: Yasnac XRC Communication Interface Module
Product Introduction: This is a multi-protocol communication interface module for Yaskawa Yasnac XRC robot controller systems. It enables integration of the robot controller with various industrial networks and host control systems.
Description
Technical Specifications:
- Supported protocols: PROFIBUS-DP, Modbus Master, DeviceNet
- Power supply: 24 VAC/DC ±10%
- Current consumption: 0.5 A maximum
- Operating temperature: -10°C to +60°C
- Storage temperature: -25°C to +70°C
- Humidity: 10% to 90% RH (non-condensing)
- Vibration resistance: 10 m/s², 10 to 150 Hz
- Shock resistance: 150 m/s², 11 ms
- Dimensions: 200 mm x 150 mm x 100 mm (approximate)
- Weight: ~0.9 kg
Function Features:
- Supports multiple industrial fieldbus protocols for flexible system integration
- Enables data exchange between robot controller and PLC/HMI/SCADA systems
- Built-in protocol conversion and data mapping functions
- Status indicators for power, communication activity, and fault conditions
- Configurable I/O data mapping via setup software
- Supports both master and slave operation modes (protocol dependent)
Application Scenarios:
- Robot cell integration with factory automation networks
- PLC to robot controller communication
- SCADA system monitoring of robot status
- Flexible manufacturing systems with multiple robots
- Automotive production line robot integration
- Material handling robot fleet coordination
Performance Parameters:
- PROFIBUS-DP baud rate: Up to 12 Mbps
- Modbus RTU speed: Up to 19.2 kbps
- DeviceNet baud rate: 125 kbps / 250 kbps / 500 kbps
- Maximum I/O data size: 244 bytes input / 244 bytes output
- Data update cycle: 10 ms (typical)
- Isolation voltage: 500 VAC between communication ports and logic circuit
Material Composition:
- Enclosure: Sheet steel with powder coating
- PCB: FR-4 glass epoxy with copper traces
- Connectors: Fieldbus-specific connectors (D-sub, terminal block)
- Isolation components: Optocouplers and pulse transformers
- Heat sink: Aluminum alloy for power regulation
Structure Characteristics:
- Panel-mount or DIN-rail mountable design
- Front panel with LED status indicators for each protocol
- Removable terminal blocks for easy field wiring
- Compact form factor for cabinet installation
- Rugged industrial construction
- Built-in surge protection on communication ports
Working Principle:
- Receives data from robot controller via internal serial bus
- Converts robot data format to selected fieldbus protocol
- Transmits data to host system over industrial network
- Receives commands and data from host system and converts to robot controller format
- Handles protocol handshaking and error checking automatically
- Provides real-time status updates to controller and host system
Installation Requirements:
- Mount on DIN rail or panel inside control cabinet
- Connect to robot controller via dedicated communication cable
- Wire fieldbus cable according to protocol specifications
- Apply proper termination resistors at network endpoints
- Ground module chassis to system ground
- Configure network address and parameters via setup software before operation
Usage Notes:
- Verify network address settings before applying power
- Use only shielded cables for fieldbus connections
- Do not exceed maximum cable length for selected baud rate
- Disconnect power before wiring or module replacement
- Periodically inspect cable connections for tightness
- Do not expose module to moisture or corrosive atmospheres
Reviews
There are no reviews yet.