
Product Short Description
Product Brief Overview
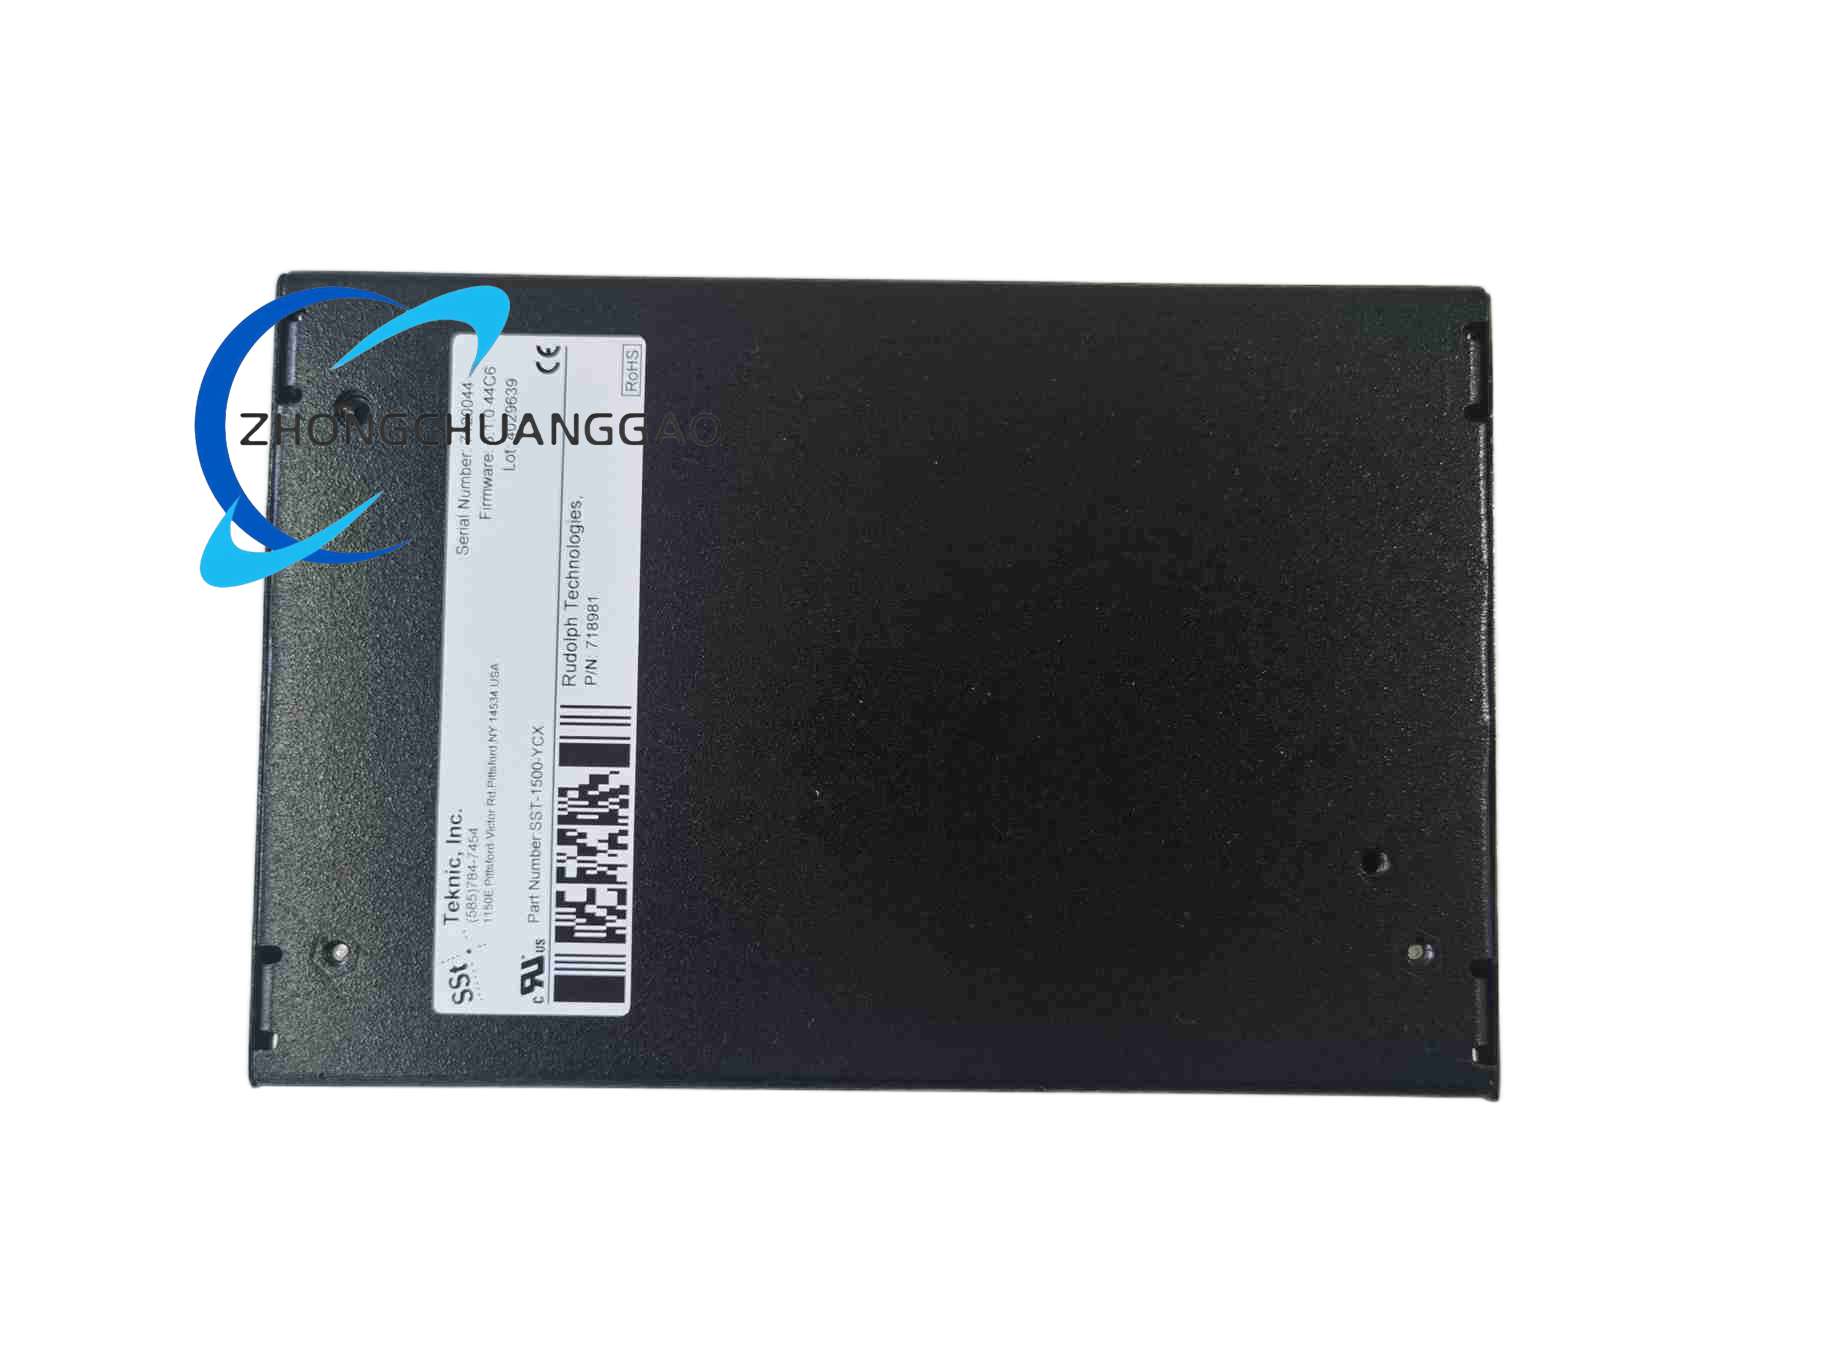
Description
- First digit “3”: Pre-calibrated motor matching parameter group, corresponding to Teknic standard 1500W three-phase permanent magnet brushless servo motor model series with built-in 24V electromagnetic holding brakes, including pre-stored motor pole number, rated stator current, back EMF constant, rotor inertia and matched 23-bit absolute encoder resolution parameters, fully matching all standard Teknic 1500W brake-equipped servo motors without manual parameter input.
- Second digit “1”: Pre-calibrated basic motion control gain parameter group No.1, factory preset standard universal gain values for position loop proportional gain, speed loop proportional/integral gain and current loop gain, suitable for most medium-inertia medium-load gravity vertical lifting axes and multi-joint robot vertical joint axes under standard operating speed conditions, realizing stable servo motion without mechanical oscillation or positioning overshoot after power-on without additional gain debugging.
- Third digit “0”: Pre-calibrated brake timing parameter group No.0, factory preset standard universal brake release delay time (200ms) and brake lock delay time (300ms), matching the standard mechanical brake spring response speed of Teknic 1500W brake servo motors, effectively preventing vertical axis sliding and brake friction plate excessive wear under most standard gravity load operating conditions.
Complete Technical Specifications
Core Function Features
- Pre-stored complete motor matching parameter group No.3: All critical motor characteristic parameters required for servo drive-motor matching are pre-written into internal flash memory at the factory, including motor pole count, rated operating current, continuous torque rating, peak torque rating, back EMF voltage constant, rotor mechanical inertia value and matched absolute encoder resolution parameters. After the servo drive is connected to a standard Teknic 1500W brake-equipped servo motor on-site, engineers only need to execute a one-click motor parameter load command via ServoTools software or front panel physical buttons to activate the pre-stored motor matching parameters, eliminating time-consuming manual entry of dozens of motor characteristic parameters and avoiding configuration errors caused by manual data input.
- Pre-stored universal medium-inertia motion control gain parameter group No.1: Factory pre-set optimized proportional/integral gain values for position loop, speed loop and current loop, calibrated under standard medium-inertia mechanical load test conditions to achieve stable motion performance without mechanical oscillation, positioning overshoot or slow motion response under most conventional vertical gravity load axis operating speed ranges. For mass-produced standardized automated equipment with unified mechanical load inertia and operating speed requirements, the pre-stored gain parameters can be directly activated and used without additional on-site gain tuning and debugging work, greatly shortening equipment electrical debugging time and realizing consistent standardized motion performance for all mass-produced equipment units.
- Pre-stored standard brake timing delay parameter group No.0: Factory pre-calibrated universal brake release delay time (200 milliseconds) and brake lock delay time (300 milliseconds), matched to the standard mechanical spring response speed of Teknic’s built-in motor holding brake assemblies. After activating this pre-stored brake timing parameter group, the servo drive automatically executes standardized brake release and lock delay timing logic during motor start and stop operation, effectively eliminating vertical mechanical axis sliding caused by insufficient delay time and excessive friction wear of brake friction plates caused by overly short lock delay time under standard medium gravity load operating conditions. If the equipment mechanical load weight, operating speed or brake assembly specifications are customized and different from standard specifications, engineers can still manually modify all brake timing delay parameters via ServoTools software or front panel local adjustment buttons, and save modified customized parameter sets to the internal flash memory for independent storage and recall, retaining full parameter modification flexibility while providing factory pre-calibrated standard parameter groups for rapid mass production debugging.
Material Composition & Structural Characteristics
Installation Requirements
Application Scenarios
- Mass-produced vertical lifting automated packaging machinery production lines
- Standardized medium-load articulated assembly robot mass production assembly lines
- Uniform-specification vertical material lifting three-dimensional warehouse automated transfer equipment
- Mass-manufactured PCB vertical lifting feeding automated electronic production line equipment
- Standard vertical positioning laboratory automatic sample testing mass-produced equipment
Working Principle
When the servo drive is powered on for the first time after equipment assembly, the main control chip first reads the three groups of factory pre-calibrated fixed parameter sets (motor matching group 3, motion gain group 1, brake timing group 0) pre-stored in the internal non-volatile flash memory chip. Engineering personnel can send a one-click parameter activation command via the upper PC ServoTools configuration software or through physical operation buttons on the front panel of the servo drive to load all three pre-calibrated parameter groups into the servo drive’s real-time motion control operation memory space. After the one-click parameter loading operation is completed, all motor matching characteristic parameters, multi-loop motion control gain parameters and brake timing delay parameters take effect immediately, and the servo drive enters a stable standardized closed-loop motion control operating state without any additional manual parameter input or gain tuning steps. All real-time motion control closed-loop operation logic, brake timing control logic and safety protection fault detection logic operate according to the identical internal working flow of the standard YCX model after the pre-calibrated parameters are loaded into the real-time operation memory. If on-site mechanical load, operating speed or brake assembly specifications deviate from standard factory calibration conditions, engineers can manually adjust any single parameter value via configuration software or front panel buttons, save the modified customized parameter set as an independent storage group inside flash memory, and freely switch between the original factory pre-calibrated “3-1-0” standard parameter group and user-modified customized parameter groups at any time during equipment debugging or maintenance work, retaining complete parameter adjustment flexibility while providing factory pre-calibrated standard parameters for rapid mass production equipment debugging.
Use Precautions
- The factory pre-calibrated parameter group “3” is exclusively matched to standard Teknic 1500W brushless servo motors equipped with built-in 24V electromagnetic holding brakes. Do not activate this pre-stored motor parameter group to drive non-Teknic brand 1500W servo motors, or Teknic 1500W servo motor variants without built-in holding brakes. Mismatched motor parameter loading will lead to severe motor vibration, abnormal operating noise, motor overheating, servo drive overcurrent fault alarms and permanent burnout damage to both the servo drive power module and servo motor winding insulation layers. If non-standard or non-Teknic brand servo motors are matched to the drive, all factory pre-stored motor parameters must be cleared, and complete motor characteristic parameters must be manually input and calibrated on-site by professional motion control engineering personnel.
- The factory pre-calibrated motion gain parameter group “1” and brake timing parameter group “0” are calibrated under standard medium-inertia mechanical load and medium operating speed test conditions. When this servo drive is applied to automated equipment axes with ultra-large mechanical load inertia, ultra-high continuous operating speed, ultra-heavy gravity load weight or customized modified mechanical brake assembly structures, directly activating the factory pre-stored standard parameter groups may lead to mechanical motion oscillation, severe positioning overshoot, slow motion dynamic response speed, vertical axis sliding during brake release or excessive brake friction plate wear during long-term continuous equipment operation. Under such non-standard mechanical operating conditions, engineering personnel must perform targeted on-site tuning and modification of position/speed/current loop gain parameters and brake release/lock delay timing parameters after activating the factory pre-calibrated standard parameter groups, conduct multiple repeated full-speed full-load motion test cycles to verify stable motion performance without oscillation, overshoot or brake sliding wear faults, and save the modified customized parameter set to internal flash memory for subsequent equipment maintenance and restart use.
Reviews
There are no reviews yet.