
Product Short Description
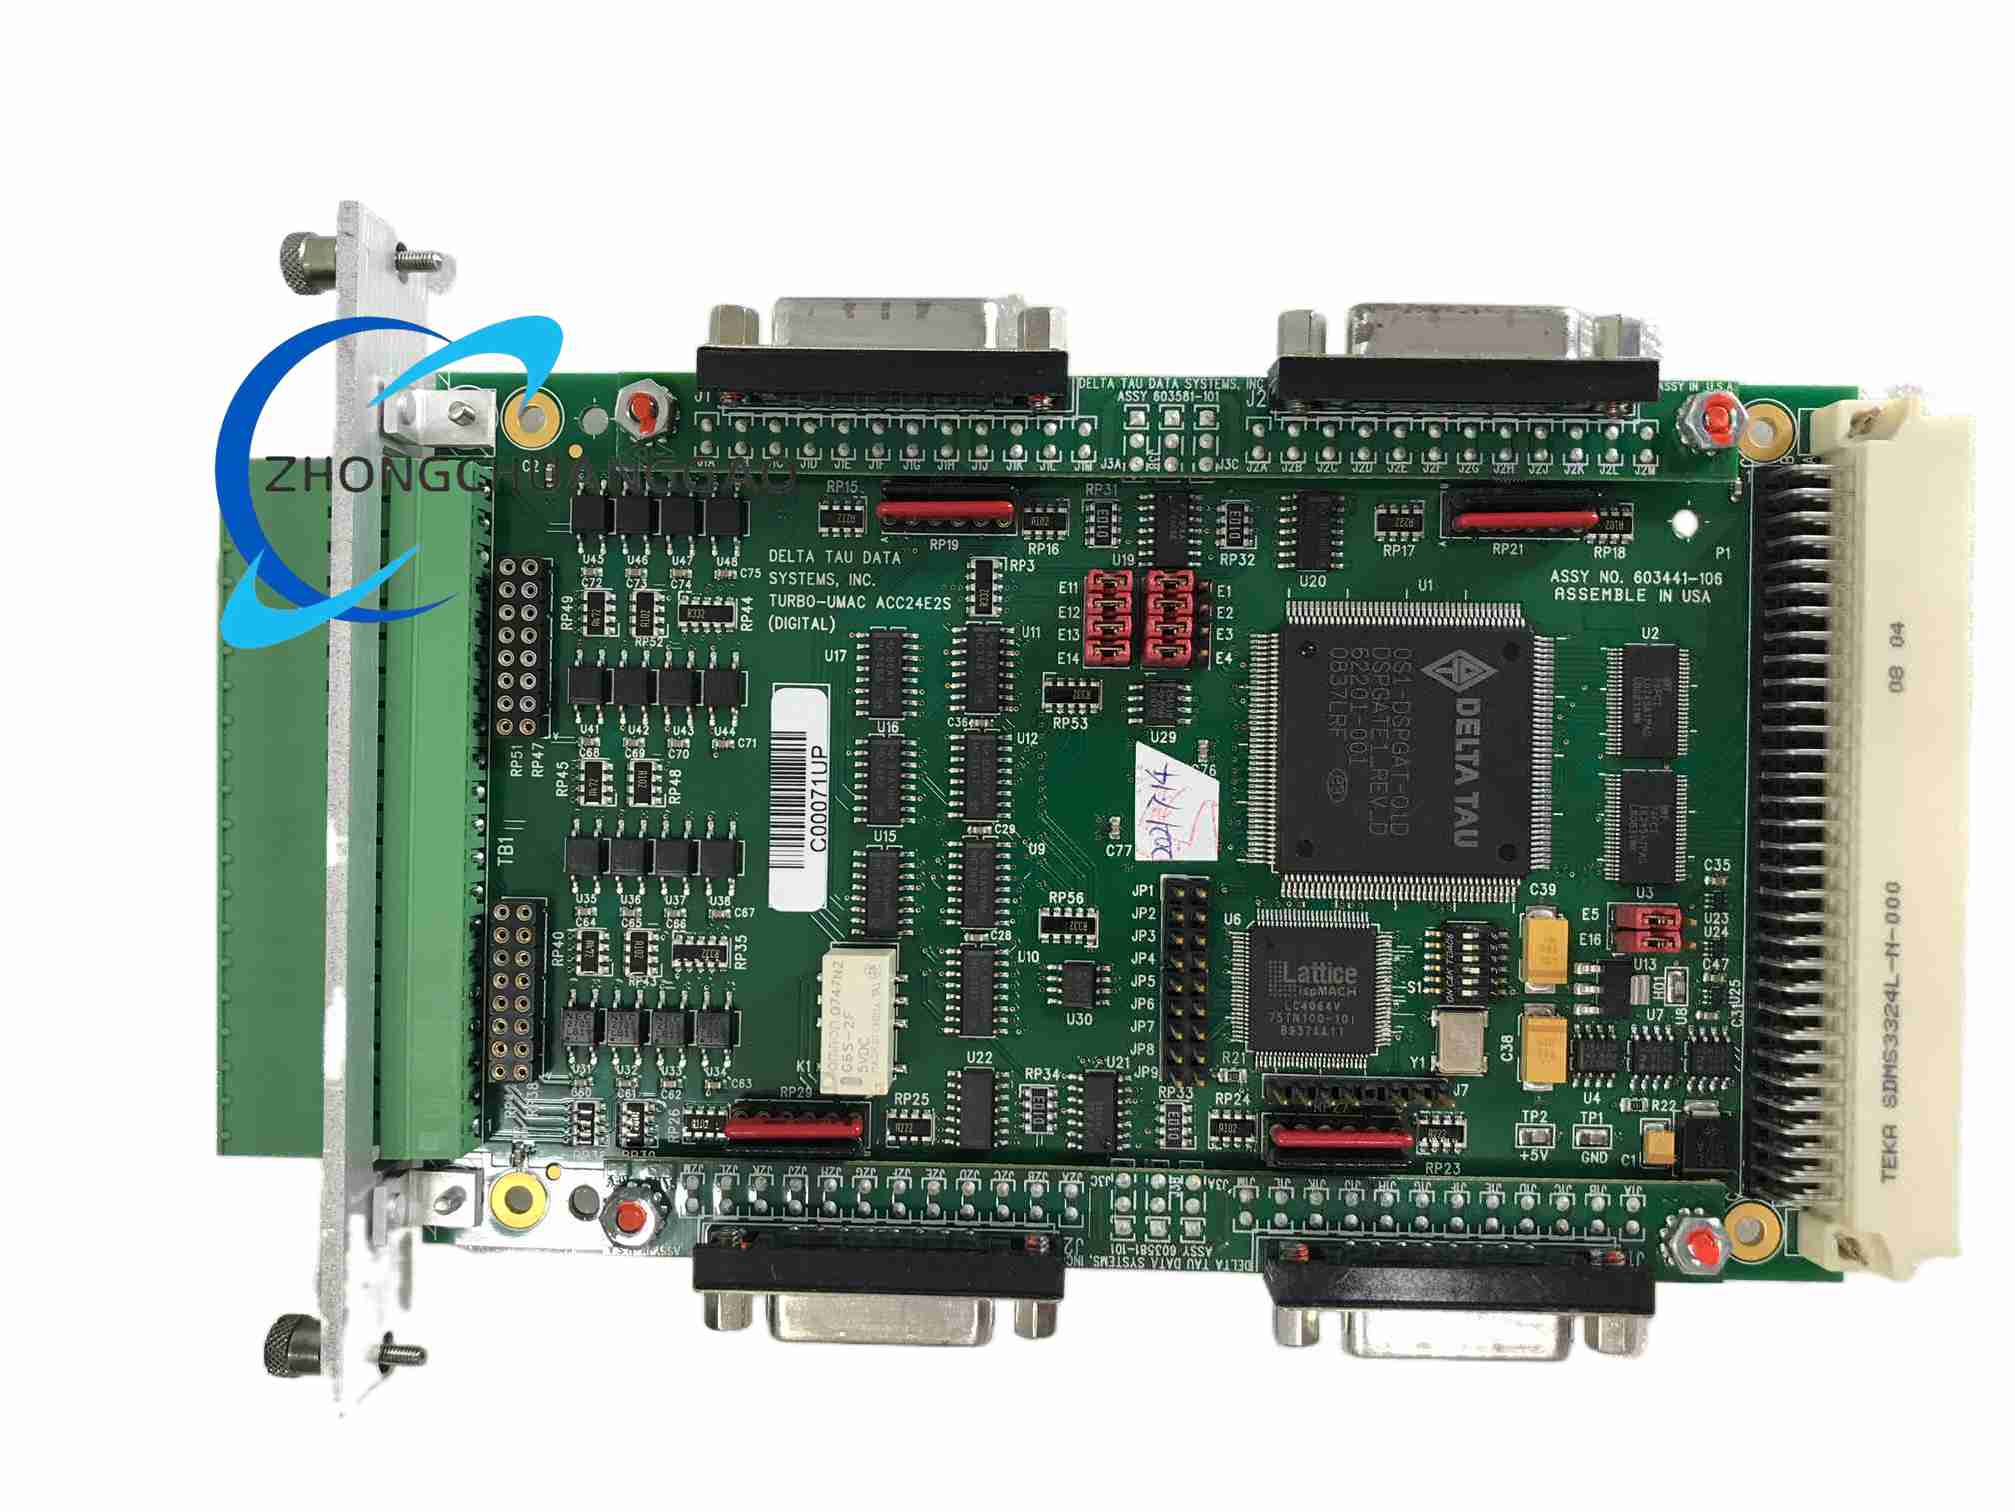
Product Overview: The ACC-24E2S belongs to the same Delta Tau (OMRON) accessory board family as the ACC-24E2A, designed for the UMAC and Turbo PMAC2 motion-control platforms. It provides servo interface functionality with DB-type connectors for field wiring, interfacing the PMAC CPU with analog servo drives and feedback devices. The “S” variant is positioned for systems that require the ACC-24E2 form factor with specific connector and configuration options suited to the application’s wiring and mounting preferences.
Description
Technical Specifications:
-
Compatible Controllers: PMAC2, Turbo PMAC2, PMAC Clipper, UMAC frames
-
Interface Form: DB-series connectors for analog output and encoder feedback
-
Analog Output: ±10 V class differential output, 16-bit resolution
-
Encoder Feedback: Differential RS-422 A/B/Z inputs, supporting 4× quadrature decoding
-
Servo Loop: Hardware PID with feed-forward, electronic gearing and camming
-
Bus Interface: UMAC/Turbo PMAC2 backplane
-
Power Supply: From host backplane (+5 V / ±12 V)
-
Operating Temperature: 0 °C to +60 °C
-
Mounting: 3U Eurocard rack slot or UMAC carrier
Key Features:
-
Drop-in compatibility with Delta Tau motion controllers, identical development environment to the ACC-24E2A
-
DB connectors simplify field wiring and maintenance compared to HD D-sub in certain cabinet layouts
-
Full access to Power PMAC scripting, electronic gearing, cam profiling and coordinated multi-axis interpolation
-
Deterministic servo update for stable closed-loop control
Application Scenarios: Retrofit of existing UMAC-based machine tools, packaging machinery, general-purpose automation cells, and applications where the DB connector style is preferred for cabinet wiring standards.
Installation Requirements:
-
Install into the assigned UMAC backplane slot; verify the ejector mechanism is fully seated
-
Use shielded cables for all analog and encoder signals; separate signal trays from power trays
-
Confirm backplane supply voltage before applying power
Usage Notes:
-
Do not power the board standalone; it must draw power from the host controller backplane
-
Keep the firmware of the PMAC CPU and accessory board aligned to avoid communication errors
-
For high-EMI environments, add external signal isolation between the board and field devices
Reviews
There are no reviews yet.