
Product Short Description
Product Overview
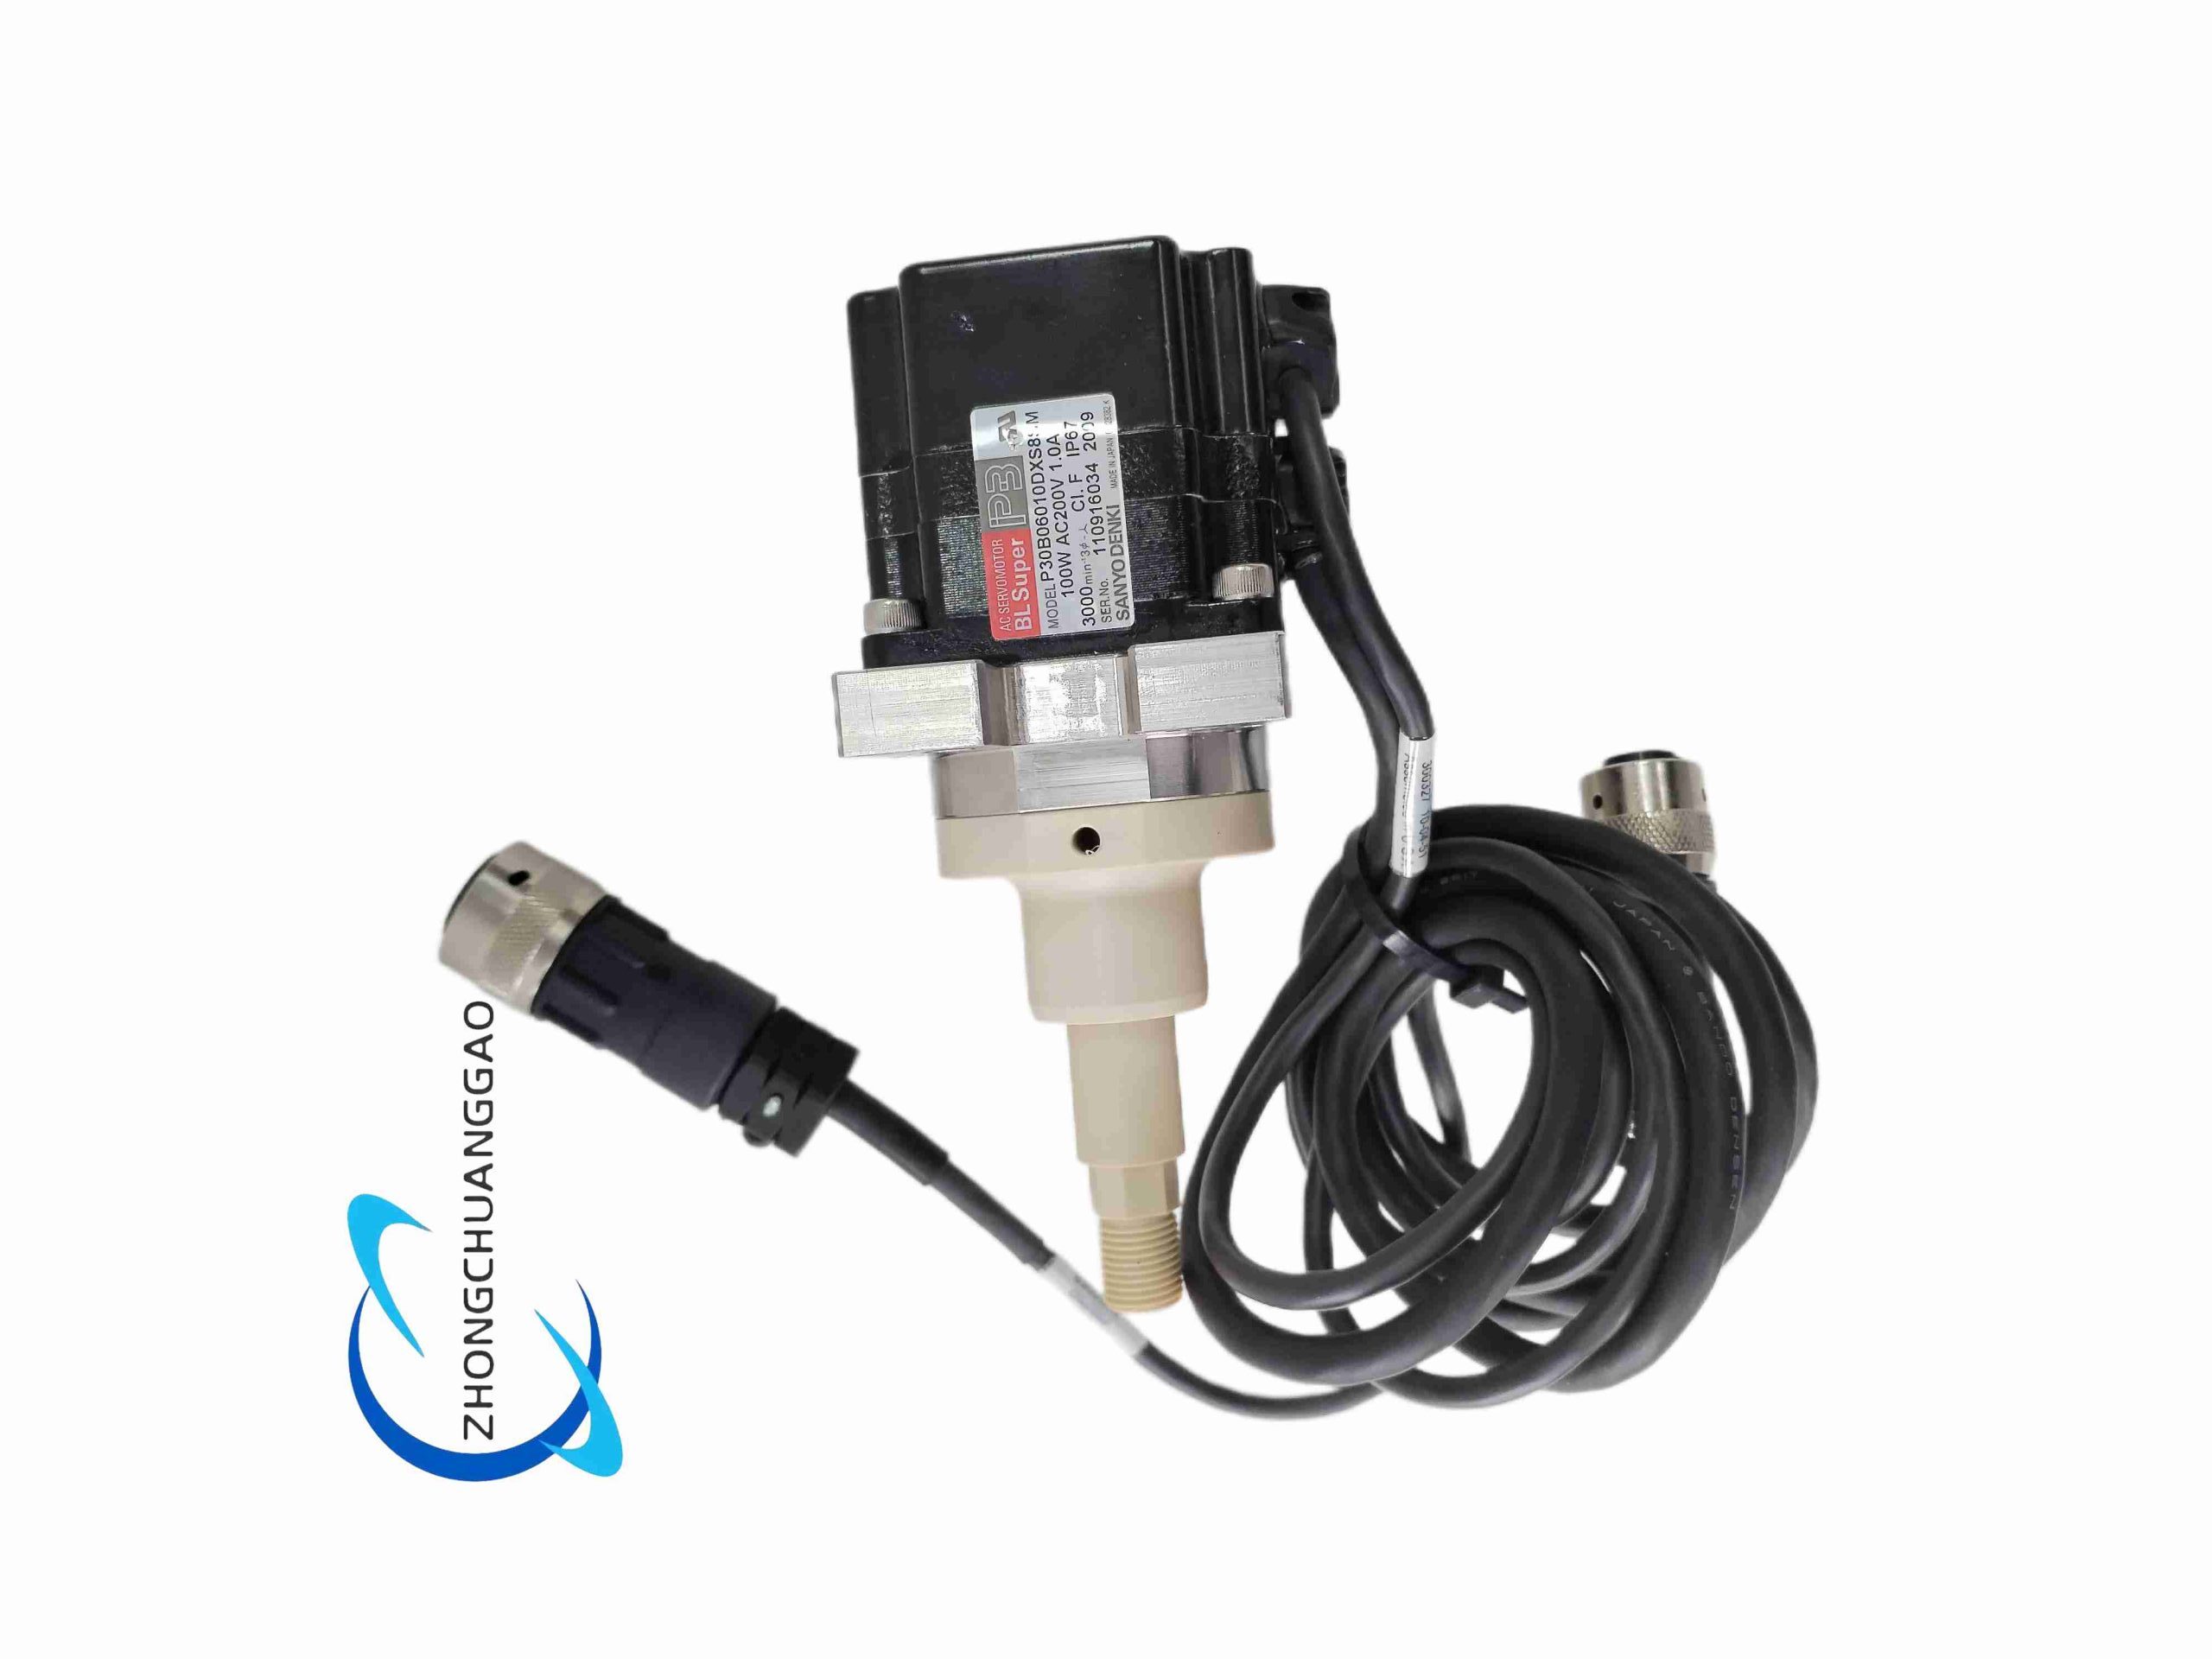
The P30B06010DXS8SM belongs to Sanyo Denki P30B series medium-power servo motors with a 60mm standard mounting flange and rated power of 300W, designed for feed and rotary driving of medium-sized automated equipment. Equipped with a 23-bit multi-turn absolute encoder to eliminate homing procedures. The brake-free design shortens overall motor length for installation in compact spaces with no vertical load sliding risk. Reinforced double-layer sealing upgrades IP65 protection performance, adapting to machine tools, injection molding auxiliary machinery and automated production lines. When matched with Sanyo Denki RS series servo drives, high-precision full closed-loop motion control can be realized.
Description
Model Code Definition
- P30B: Medium-inertia servo motor series
- 060: 60mm mounting flange size
- 10: Rated power 300W
- DXS8: 23-bit multi-turn absolute encoder
- S: No built-in electromagnetic brake
- M: Reinforced dustproof and waterproof sealing structure
Electrical Parameters
- Rated Power: 300W
- Rated Torque: 0.955N·m
- Peak Torque: 2.86N·m
- Rated Speed: 3000rpm
- Max Speed: 5000rpm
- Rated Current: 2.3A
- Input Voltage: 3-phase AC200V
- Encoder: 23-bit multi-turn absolute encoder with backup battery for power-off origin memory
- Brake Configuration: No built-in brake; external brake modules required for vertical load applications
Mechanical Dimensions
- Mounting Flange: 60×60mm
- Output Shaft Diameter: 14mm with standard flat key
- Overall Length (brake-free compact design): 96mm
- Net Weight: 0.86kg
Environmental & Protection Parameters
- Protection Class: IP65 (double-layer fluorine rubber shaft oil seal, thickened waterproof cable gland)
- Operating Temperature: 0℃ ~ 45℃
- Storage Temperature: -20℃ ~ 70℃
- Vibration Resistance: 10~55Hz, amplitude 0.2mm
- Humidity: 20% ~ 85% non-condensing
Functional Features
- 23-bit ultra-high resolution multi-turn absolute encoder retains full position data after power failure. Direct coordinate reading upon power-up removes mechanical homing steps and improves production line cycle efficiency.
- Medium-inertia rotor design delivers abundant torque reserve to prevent step loss under heavy load startup and shutdown, with repetitive positioning accuracy up to ±0.001mm for precision machining applications.
- Brake-free compact body reduces overall volume, lowering mechanical design constraints for equipment with confined internal installation space.
- Double-layer fluorine rubber shaft oil seal and reinforced waterproof sealing enhance resistance to cutting fluid and oil mist erosion compared to standard models.
- Low-vibration, low-noise winding design eliminates jitter at speeds below 50rpm, suitable for precision visual inspection and alignment equipment.
- Compatible with EtherCAT, Modbus and pulse command control interfaces, supporting connection with mainstream PLC and motion controllers.
Material & Structural Composition
- Motor Housing: Integrally molded die-cast aluminum alloy with hard anodized surface for corrosion resistance, light weight and high structural rigidity.
- Stator Assembly: Laminated high-purity silicon steel core with Class F high-temperature resistant enameled windings (155℃), maintaining stable performance under long-term full-load operation.
- Rotor Assembly: High-stability neodymium iron boron permanent magnets with strong anti-demagnetization performance; quenched and tempered 45# stainless steel output shaft with superior wear and impact resistance.
- Sealing Components: Double-layer fluorine rubber oil seals and thickened elastic rubber gaskets block intrusion of water vapor, dust and cutting oil into the motor interior.
- Independent Encoder Sealed Cavity: Epoxy encapsulated circuit board isolated from the motor power cavity, preventing encoder chip damage from high winding temperature and oil contamination.
- Cable Fittings: Thickened brass waterproof cable glands with anti-aging rubber sheaths to avoid water ingress from cracked cable jackets under bending stress.
Working Principle
The three-phase servo drive outputs sinusoidal alternating current into stator windings to generate a continuous rotating magnetic field. Permanent magnets embedded in the rotor couple with the stator magnetic field to drive synchronous rotation of the output shaft.
A rigidly coupled absolute encoder mounted on the shaft continuously collects real-time rotor angle, rotational speed and multi-turn position data, transmitting feedback signals to the servo drive to form a full closed-loop control circuit. The drive dynamically adjusts output current magnitude by comparing target motion coordinates and actual encoder feedback values, precisely regulating output torque, rotational speed and positioning to achieve high-precision point-to-point, speed and synchronous motion control.
This model is not equipped with an integrated power-loss electromagnetic brake. External brake modules must be installed for vertical lifting load applications to prevent uncontrolled load sliding upon power cut-off.
Installation Requirements
- Flange Mounting Standard: Secure the 60mm standard flange with 4 M5 bolts tightened to 2.0N·m. Ensure no foreign debris between flange mating surfaces to avoid tilted installation.
- Coaxiality Tolerance: Coaxial deviation between motor output shaft and load coupler/lead screw must not exceed 0.03mm. Eccentric mounting will trigger severe high-speed vibration and rapid bearing wear.
- Cable Routing Specifications: Separate power cables and shielded encoder cables in dedicated metal trunking, maintaining a minimum 20cm clearance from high-power inverter and contactor power lines. Both ends of cable shielding must be reliably grounded to suppress electromagnetic interference.
- Heat Dissipation Clearance: Reserve a minimum 35mm ventilation gap around the motor housing. Do not wrap thermal insulation materials around the motor body. Auxiliary cooling fans are recommended for continuous full-load operation.
- Grounding Specifications: Connect the motor metal housing ground wire to the equipment’s main protective earth bus bar to eliminate static electricity and electromagnetic interference, stabilizing encoder signal transmission.
- Environmental Installation Restriction: Do not mount the motor in areas with continuous direct spraying of water mist or cutting oil. Install simple protective shields to extend oil seal service life.
Application Scenarios
- Medium-Sized Automated Production Lines: Transfer machines, loading/unloading manipulators, conveyor positioning axes
- CNC Machining Equipment: Small machining centers, engraving and milling machines, grinder feed drives
- Injection Molding Auxiliary Equipment: Manipulator pick-up axes, die-cut positioning mechanisms
- 3C Automation Equipment: Large automatic laminators, automatic screw lockers, precision inspection machines
- Packaging Machinery: Fully automatic sealing machines, slitting machines, carton forming equipment
- Material Transfer Modules: Medium-sized linear slides, rotary indexing tables
Operation & Maintenance Precautions
- This motor model has no built-in brake. External electromagnetic brake modules are mandatory for vertical lifting and heavy-load sliding-risk working conditions; vertical load operation without braking devices is strictly prohibited.
- Never subject the output shaft to violent impact or hammering. External impact force will damage the precision encoder grating and internal bearings irreversibly.
- Inspect the shaft oil seal every 3 months during continuous operation. Replace aged, hardened or leaking oil seals promptly to prevent oil contamination of internal windings.
- The encoder backup battery must be replaced every 4 years to avoid loss of origin position data after power failure.
- Prohibit prolonged motor stall operation; stall current will surge rapidly and burn stator winding coils.
- Avoid violent pulling of power and encoder signal cables during handling and installation. Internal wire breakage from tensile force leads to communication faults and uncontrolled motor operation.
Reviews
There are no reviews yet.