
Product Short Description
Product Overview
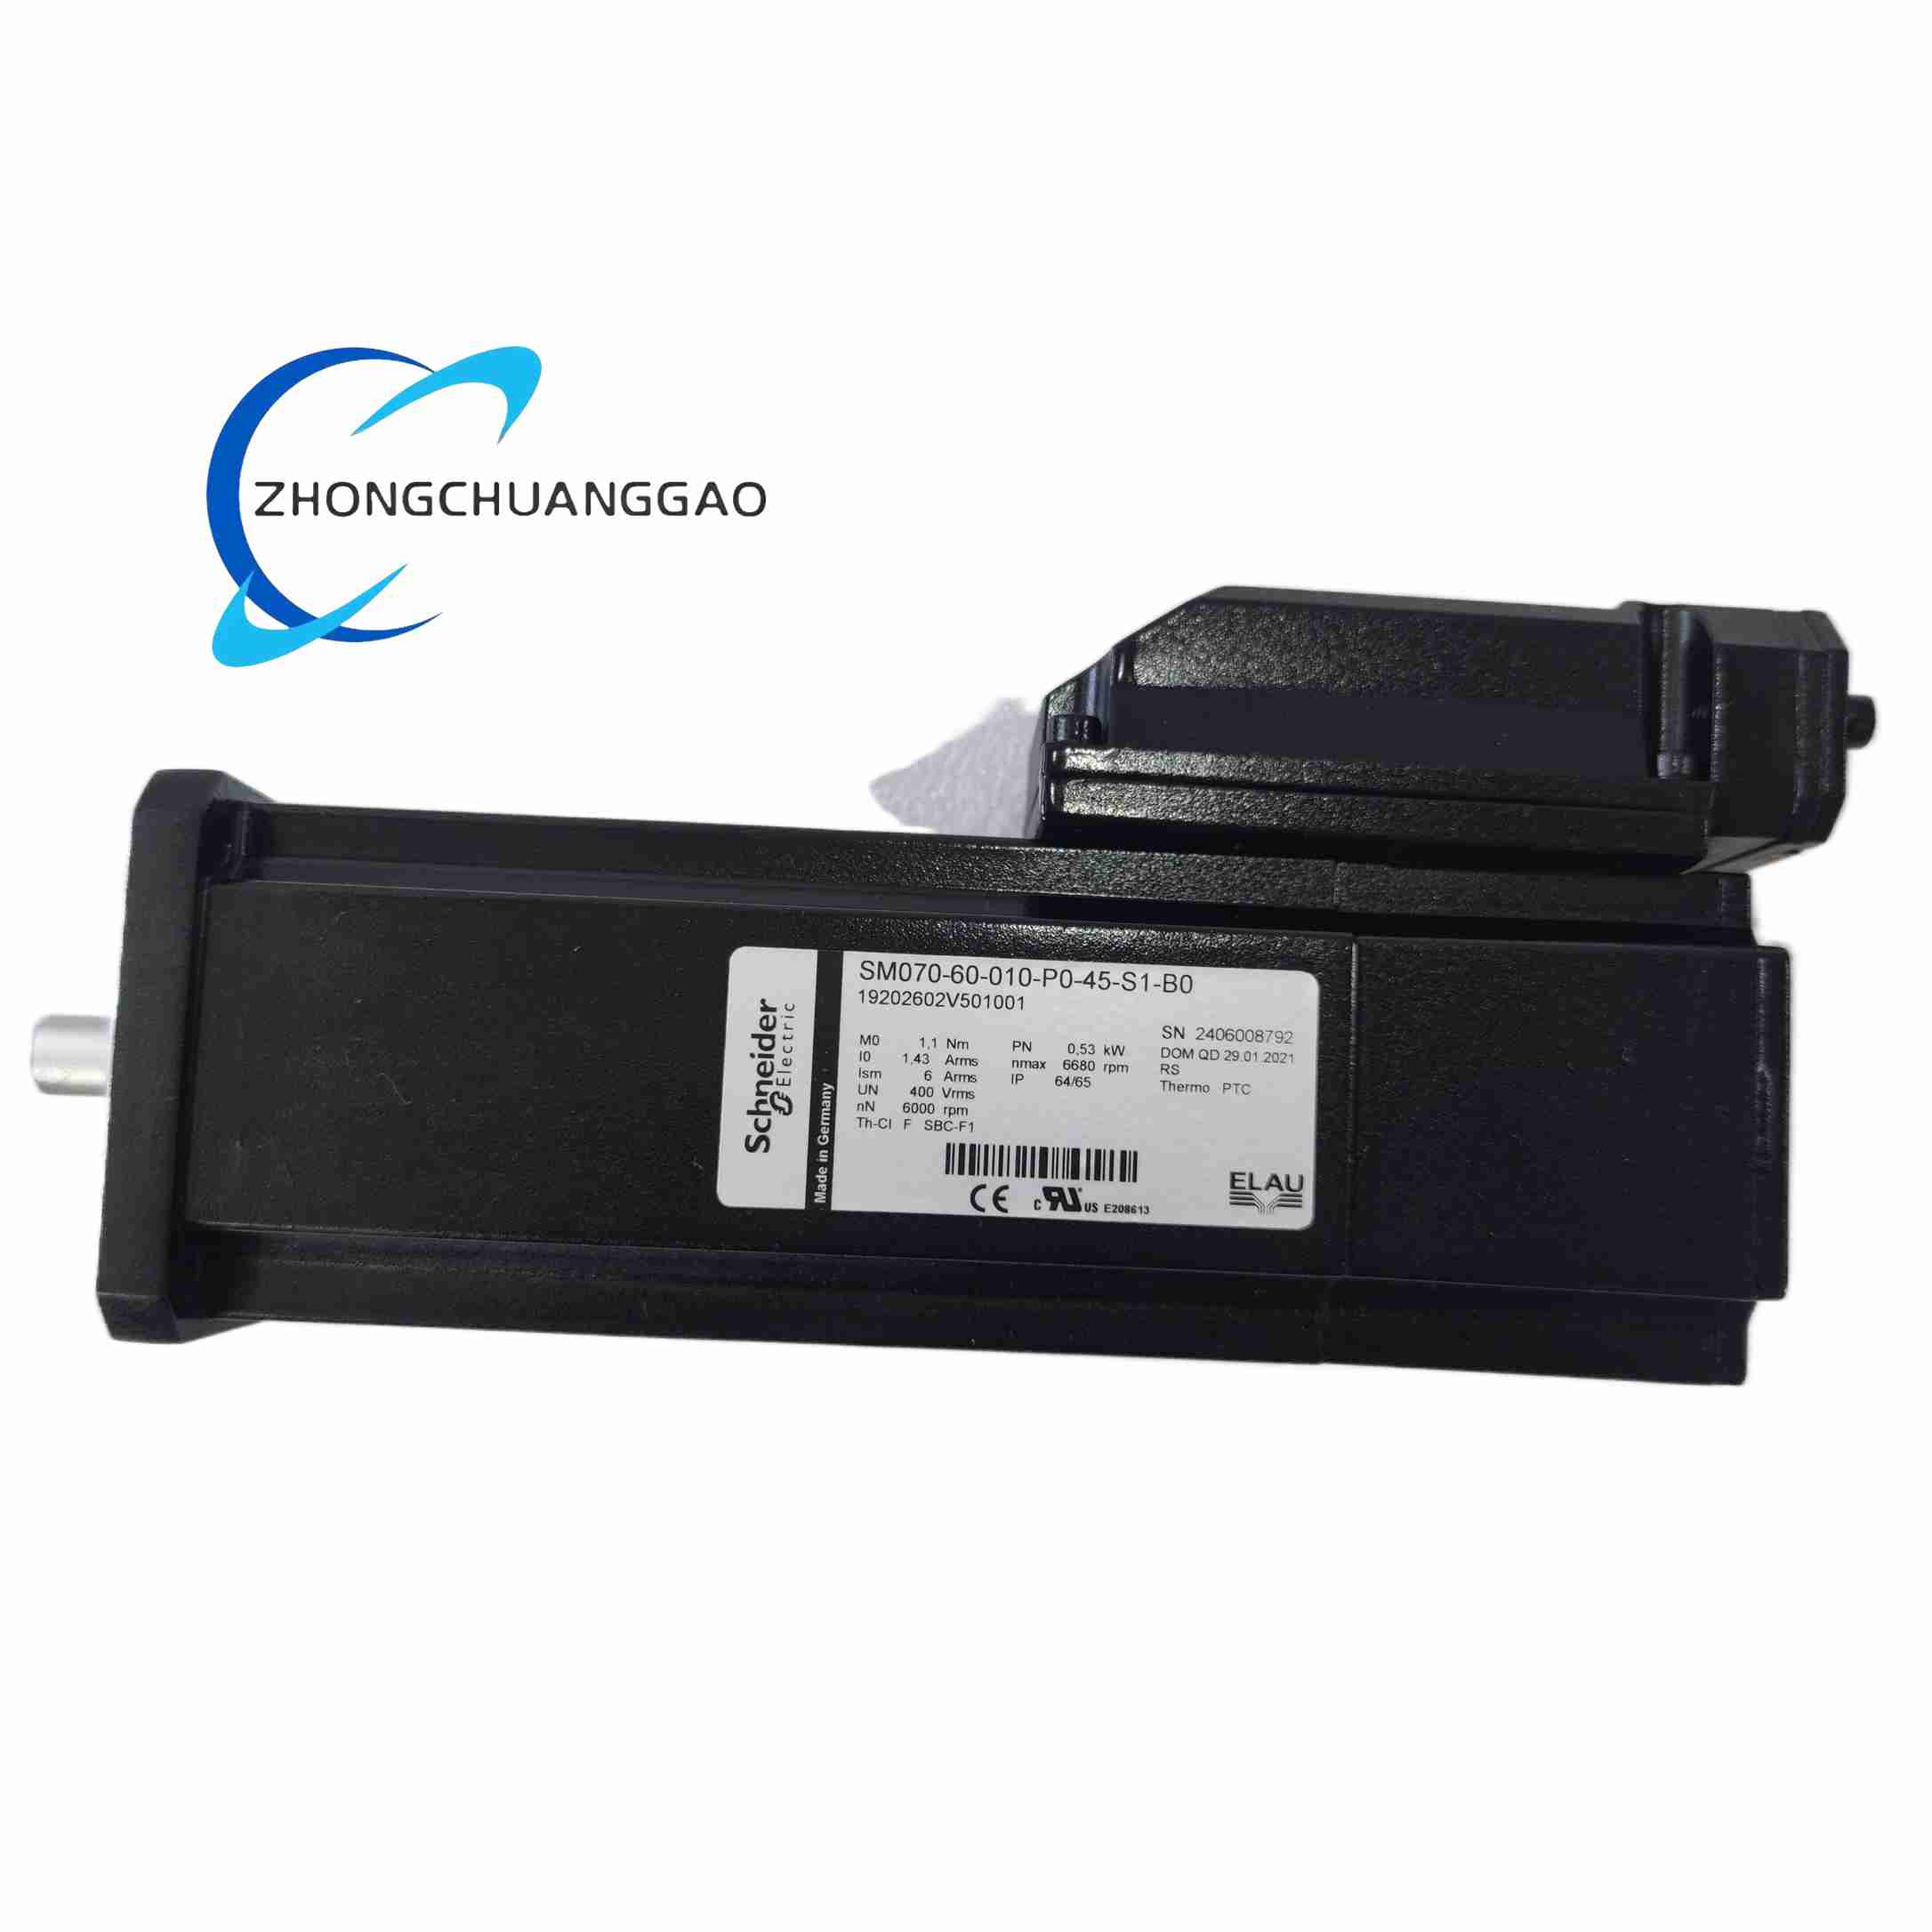
This motor belongs to ELAU PacDrive SM series high-precision synchronous servo motor, specially matched with PacDrive servo drive system, widely used in food, pharmaceutical, packaging high-speed automated production lines. The model coding represents 70mm frame size, 6000rpm maximum speed, 1.1Nm rated torque, P0 absolute encoder interface, 45mm standard shaft length, S1 continuous duty cycle, B0 standard brake-free configuration.
Description
Technical Specifications
- Motor Type: Three-phase permanent magnet synchronous servo motor (PMSM), 4 magnetic poles, Y-type winding connection
- Power & Torque Parameters: Nominal continuous power 600W; continuous rated torque 1.1Nm; peak transient torque 3.3Nm; torque constant 0.86Nm/A at 20°C
- Speed Parameters: Rated continuous speed 3000rpm; maximum no-load speed 6000rpm
- Power Supply Matching: Matched with 3AC 400V PacDrive servo drive system
- Winding Electrical Parameters: Winding resistance 12.39Ω at 120°C; winding inductance 21.9mH at 20°C; back EMF constant 52V at 1000rpm
- Encoder Configuration (P0 Code): High-resolution single-turn absolute encoder, 131072 pulses per revolution, digital serial servo interface, support EtherCAT, CANopen, Profinet bus feedback transmission
- Mechanical Structure Parameters: Frame outer diameter 70mm; motor total length 120mm; standard solid output shaft diameter; shaft extension length 45mm; net weight 2.75kg
- Duty Cycle Class: S1 continuous operation duty cycle, long-term stable operation under full load condition
- Protection Grade: Standard IP54; optional IP65 sealed waterproof and dustproof structure
- Thermal Parameters: Motor thermal time constant 46 minutes; built-in winding temperature switch, over-temperature protection trigger temperature 130°C
- Environmental Working Range: Operating ambient temperature -20°C ~ +60°C; storage temperature -30°C ~ +80°C; relative humidity 10% ~ 90% non-condensing
- Mechanical Vibration Standard: Comply with IEC 60034 mechanical vibration grade N standard
Functional Features
- Ultra-high dynamic response performance: Low rotor moment of inertia, fast acceleration and deceleration, acceleration time only 5ms, adapt to high-speed frequent start-stop motion scenes
- High-precision absolute position feedback: Single-turn 17-bit absolute encoder, power-off position memory function, no zero return operation required after equipment power-on restart, improve production efficiency
- Low torque ripple design: Optimized stator winding and rotor magnetic steel layout, torque ripple less than 3%, realize ultra-smooth low-speed constant torque operation
- S1 full continuous load operation capability: Optimized motor heat dissipation channel, can run continuously under 100% rated load for long time without over-temperature
- Multi-industry bus adaptive encoder interface: P0 standard encoder supports mainstream industrial real-time Ethernet and fieldbus protocols, seamless matching with ELAU PacDrive multi-axis motion control system
- Compact integrated mechanical structure: Integrate stator winding, permanent magnet rotor, absolute encoder and temperature detection switch into one compact housing, reduce equipment installation space occupation
- Optional multi-protection grade structure: Standard IP54 for indoor clean workshop; IP65 optional version with sealed front and rear end covers, suitable for food, pharmaceutical production line water washing and cleaning environment
- Built-in winding over-temperature hard protection: Independent temperature contact switch, directly send over-temperature fault signal to servo drive, cut off motor output power to avoid winding burnout
Working Principle
- Electromagnetic Rotation Driving Principle: The three-phase alternating current output by the matched PacDrive servo drive flows into the motor stator three-phase winding, generating a rotating alternating magnetic field inside the stator cavity. The permanent magnet installed on the motor rotor interacts with the stator rotating magnetic field to generate continuous electromagnetic torque, driving the rotor and output shaft to rotate synchronously with the stator magnetic field.
- Closed-Loop Position Feedback Principle: The absolute encoder installed at the motor rear end rotates synchronously with the rotor, real-time collect the absolute angle position of the rotor, transmit digital position feedback signals to the matched servo drive through serial bus. The servo drive compares the target position command and actual rotor absolute position, adjust the three-phase output current phase and amplitude in real time through closed-loop PID algorithm, eliminate position and speed error, realize high-precision servo positioning control.
- Over-Temperature Protection Working Logic: The temperature sensing switch attached to the stator winding insulation layer real-time detect winding operating temperature; when the temperature rises to 130°C protection threshold, the temperature switch is disconnected, send fault alarm signal to the servo drive, the drive immediately stops outputting three-phase driving current to the motor, prevent winding insulation melting and motor permanent magnet demagnetization damage.
Material & Structural Features
- Motor Outer Housing: High-strength cast aluminum alloy shell, light weight and good thermal conductivity; outer surface electrostatic anti-corrosion spray coating
- Stator Core: High-grade silicon steel laminated iron core, low iron loss, high magnetic permeability; enameled copper wire winding with high temperature resistant 180°C insulation coating
- Rotor Assembly: High-performance rare earth neodymium iron boron permanent magnet magnetic steel, surface-mounted rotor structure; rotor shaft made of high-strength quenched alloy steel
- Encoder Housing: Sealed aluminum alloy rear end cover, internal absolute encoder circuit board with conformal coating moisture-proof protection; encoder signal connector adopts dustproof circular industrial connector
- Bearing System: Double-sided high-precision low-friction sealed ball bearings, long service life grease pre-filled, no regular oil filling maintenance
- Sealing Structure (IP54 Standard): Front output shaft with rubber skeleton oil seal, front and rear end cover assembly with foam sealing gasket, prevent dust and splashing water from entering the motor internal cavity
- Heat Dissipation Structure: Cast aluminum shell with integrated axial strip heat dissipation ribs, rely on natural convection air cooling heat dissipation, no built-in cooling fan, reduce mechanical noise and failure points
Installation Requirements
- Mounting Standard: Standard B5 flange vertical mounting mode, motor front flange with four fixed mounting threaded holes; allow horizontal and vertical two installation directions
- Shaft Coupling Matching: Match elastic diaphragm servo coupling, coupling inner hole tolerance must match motor output shaft tolerance; ensure coaxiality between motor shaft and load driven shaft, coaxiality error less than 0.05mm to avoid bearing wear and vibration noise
- Cable Wiring Specification:
- Motor power cable: Special shielded servo power cable, separate wiring trough from encoder signal cable to avoid power electromagnetic interference affecting position feedback precision
- Encoder feedback cable: Double-shielded high-flexibility absolute encoder dedicated cable, single-point grounding of shielding layer at servo drive cabinet ground bar
- Ambient Installation Environment: Standard IP54 motor must be installed in indoor clean workshop, avoid long-term exposure to splashing water, oil mist and corrosive gas environment; IP65 optional version can be used for production line water washing station installation
- Heat Dissipation Space Reserve: Reserve more than 80mm air circulation gap around the motor shell, cannot install the motor in closed narrow small cavity without air circulation, avoid poor heat dissipation triggering over-temperature fault
- Grounding Specification: Motor flange shell ground terminal must connect to equipment protective ground wire with wire diameter ≥1.5mm² copper wire, eliminate static electricity and electromagnetic interference
Application Scenarios
- Food & beverage packaging machinery: High-speed carton filling machines, bottle labeling equipment, plastic film wrapping machines, food automatic sorting conveying lines
- Pharmaceutical automated production equipment: Medicinal bottle filling and capping machines, tablet blister packaging equipment, pharmaceutical reagent automatic dispensing manipulators
- Consumer goods high-speed assembly lines: Cosmetic bottle automatic assembly equipment, small electronic product high-speed pick-and-place positioning axes
- Printing and paper processing equipment: Small digital label printing presses, paper slitting constant tension control axes
- Automated logistics sorting equipment: Small sorting trolley positioning drive axes, lightweight goods automatic handling manipulators
Operation & Maintenance Precautions
- Before equipment trial run, manually rotate the motor output shaft to check for jamming, abnormal friction noise; strictly prohibit power-on operation when the shaft is stuck
- Regularly check the servo coupling fastening screws every month, prevent loose coupling caused by high-speed vibration leading to coaxiality deviation and motor bearing damage
- Do not disassemble the motor rear end encoder cover privately; disassembly will damage the absolute encoder sealing structure and cause loss of power-off position memory function
- When cleaning production line equipment, standard IP54 motor must avoid direct high-pressure water gun flushing the motor shell and connectors; only use dry cloth to wipe dust on the shell surface
- If the motor reports over-temperature fault frequently during operation, check whether the surrounding air circulation space is blocked by production line fixtures, remove obstacles to restore heat dissipation air flow
- Long-term shutdown storage of spare motors must be placed in dry constant temperature warehouse, motor output shaft coated with anti-rust grease, encoder connector covered with dustproof protective cap
- Motor winding insulation resistance test must be carried out every six months for equipment running all year round; insulation resistance lower than 1MΩ indicates insulation aging, need to replace the motor in time
Reviews
There are no reviews yet.