
Product Short Description
Product Overview
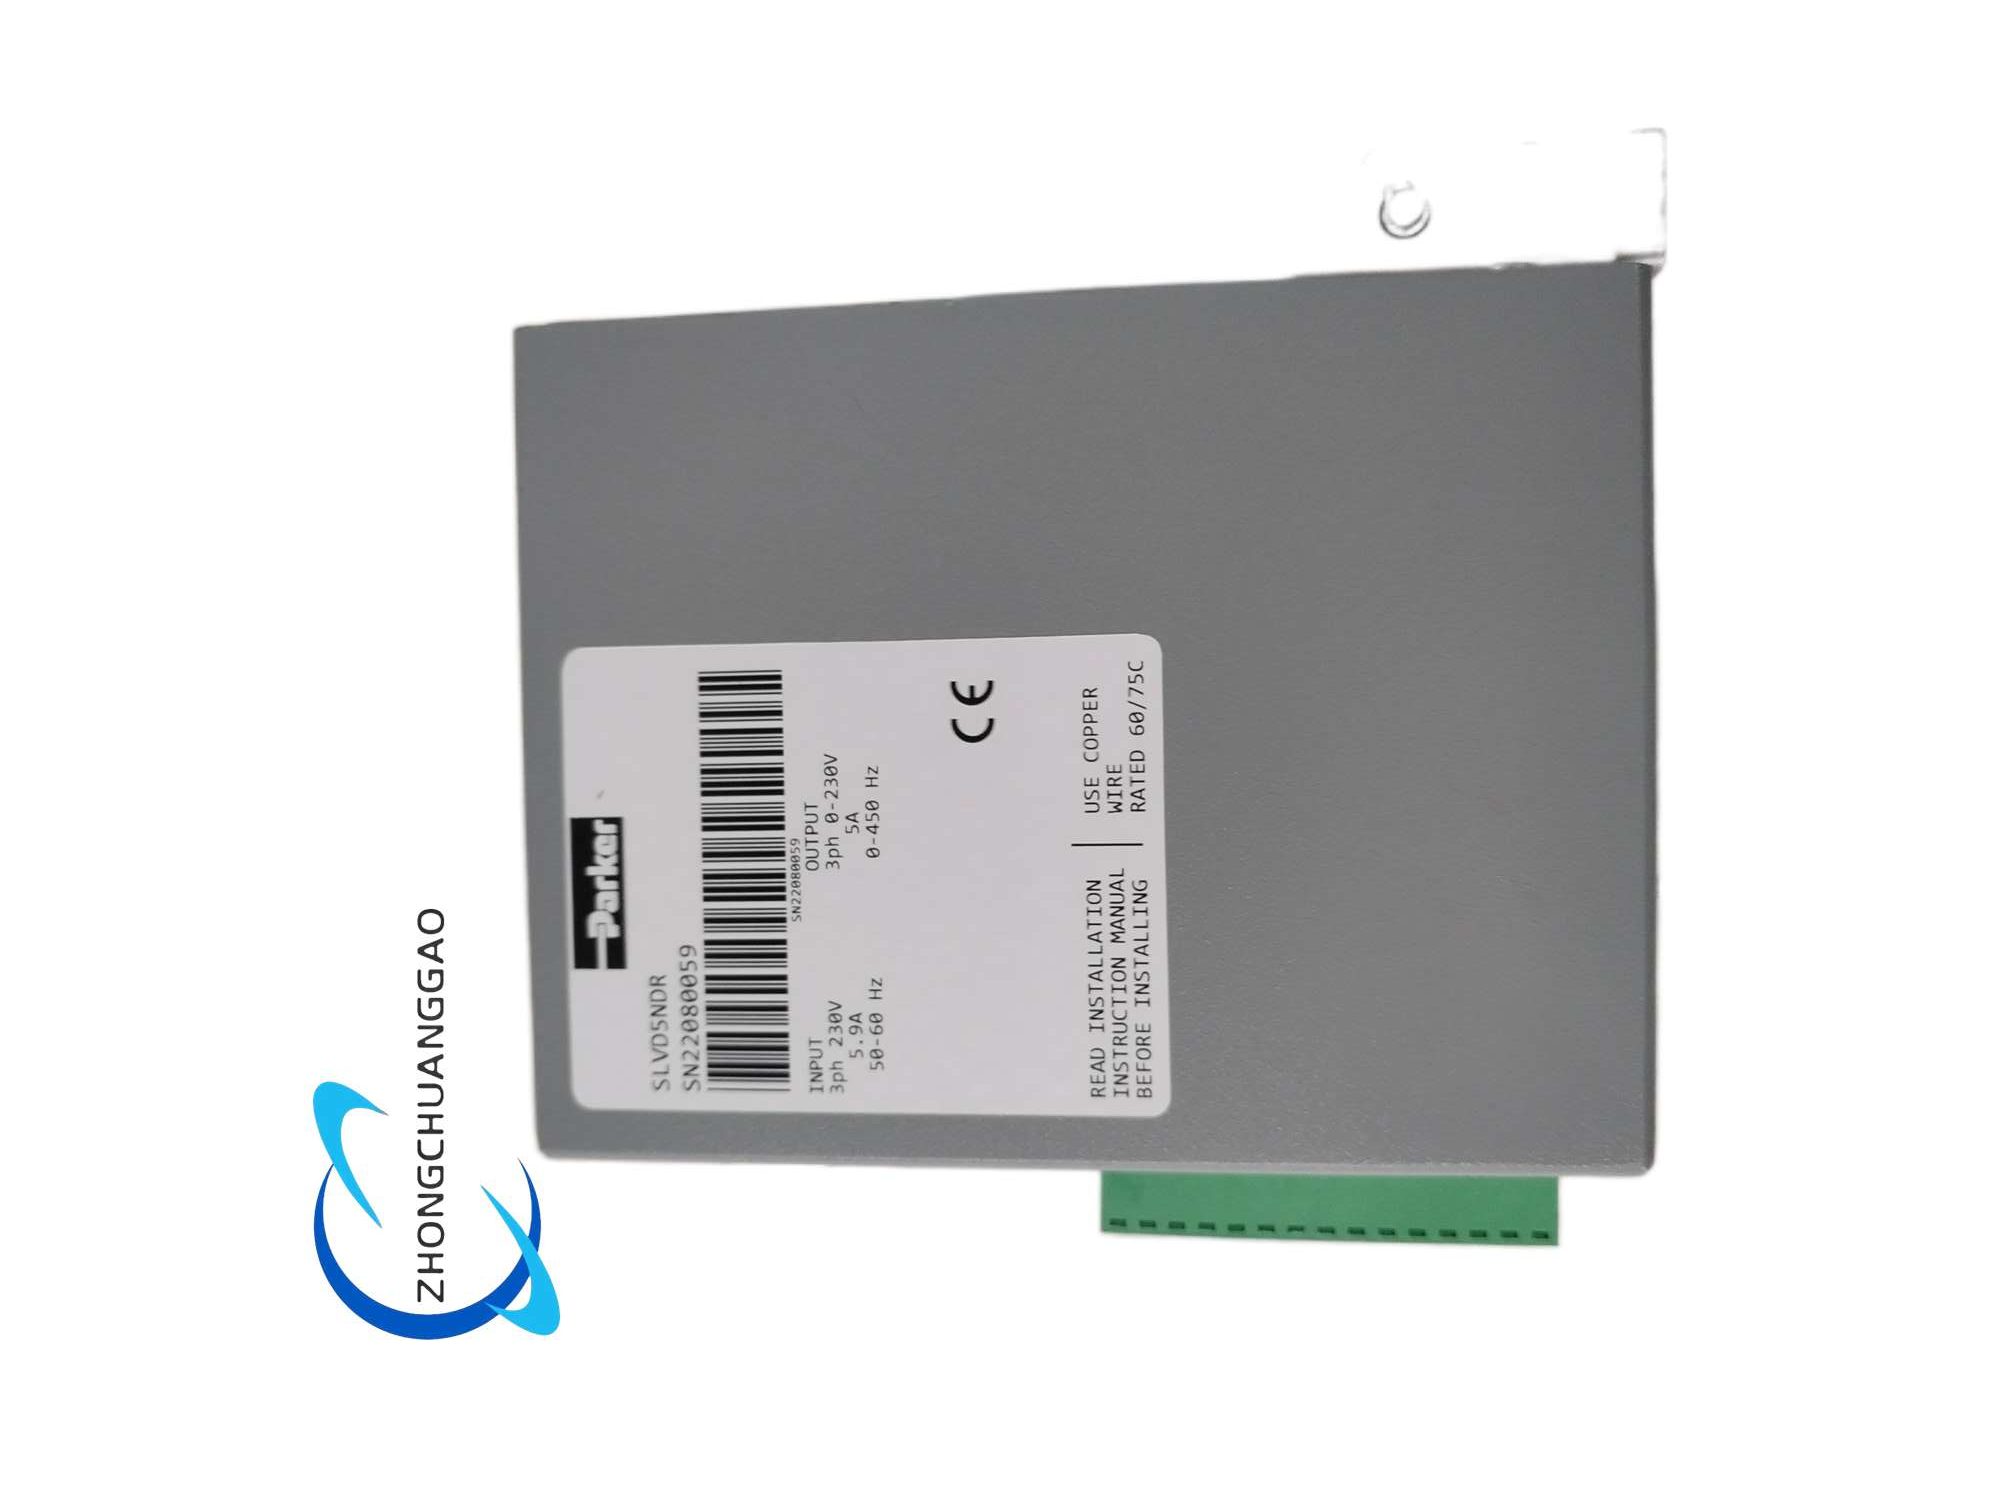
SLVD5NDR belongs to Parker SLVD-N low-power compact servo drive series, a single-axis all-digital brushless servo driver with built-in PLC motion control function. The model DR represents integrated STO safe torque off safety circuit, continuous output current 5A RMS, maximum supporting motor power 1.5kW, widely used in medium and small automation equipment for precise position, speed and torque closed-loop controlParkerGB
Description
Technical Specifications
- Input Power Supply: Single-phase / three-phase 230VAC ±10%, 50/60Hz, input capacity 2.3kVA
- Output Current: Continuous RMS current 5A, peak transient current 10A
- Supported Motor Types: Three-phase brushless permanent magnet servo motor, direct drive linear servo motor
- Feedback Signal Compatibility: Resolver, incremental encoder, EnDat absolute encoder, Hiperface absolute encoder
- Multi-Control Modes: Position closed-loop control, speed closed-loop control, torque closed-loop control; support analog ±10V command, step/direction pulse command
- Motion Function Parameters: Built-in electronic cam, electronic gearing, spindle positioning, trapezoidal motion profile generator
- Communication Interfaces: RS422/RS485 serial bus, CANopen DS402 real-time fieldbus; optional Profibus, EtherCAT communication expansion
- Built-in PLC Performance: Comply with IEC 61131 standard programming, maximum 15 sets of logic instructions, support configurable digital input/output channels
- Environmental Working Parameters: Operating temperature 0°C ~ +45°C; storage temperature -20°C ~ +70°C; relative humidity 5% ~ 90% non-condensing
- Physical Parameters: Dimensions 87mm (width) × 146mm (height) × depth; net weight 1.1kg
- Safety Certification: CE EMC/LVD electromagnetic compatibility and low voltage safety certification, UL industrial electrical certification, STO safe torque off functional safety certification
Functional Features
- Three-loop full closed-loop control architecture: Current loop, speed loop, position loop three-stage closed-loop algorithm, ultra-fast response speed, low positioning overshoot
- Independent STO safety torque off circuit: DR model integrated hardware-level STO function, cut off motor output torque within microseconds when safety signal is triggered, meet machinery safety standard requirements
- Built-in independent motion profile generator: Pre-set multi-group positioning motion programs, realize automatic reciprocating positioning without upper PLC participation
- Electronic cam & electronic gearing function: Realize synchronous follow-up motion between multiple axes, suitable for packaging, printing and other continuous follow-up production equipment
- Internal IEC61131 PLC logic processing: Independently process equipment digital input and output interlock signals, reduce upper controller I/O resource occupation
- Multi-standard industrial bus communication: CANopen DS402 real-time bus supports multi-drive synchronous linkage, single bus can connect up to 32 SLVD series servo drives
- Multiple feedback signal adaptive identification: Automatically identify resolver, incremental and absolute encoder signals, no manual parameter matching
- Flexible torque limit management: Programmable positive and negative torque upper and lower limits, realize overload protection and constant tension control
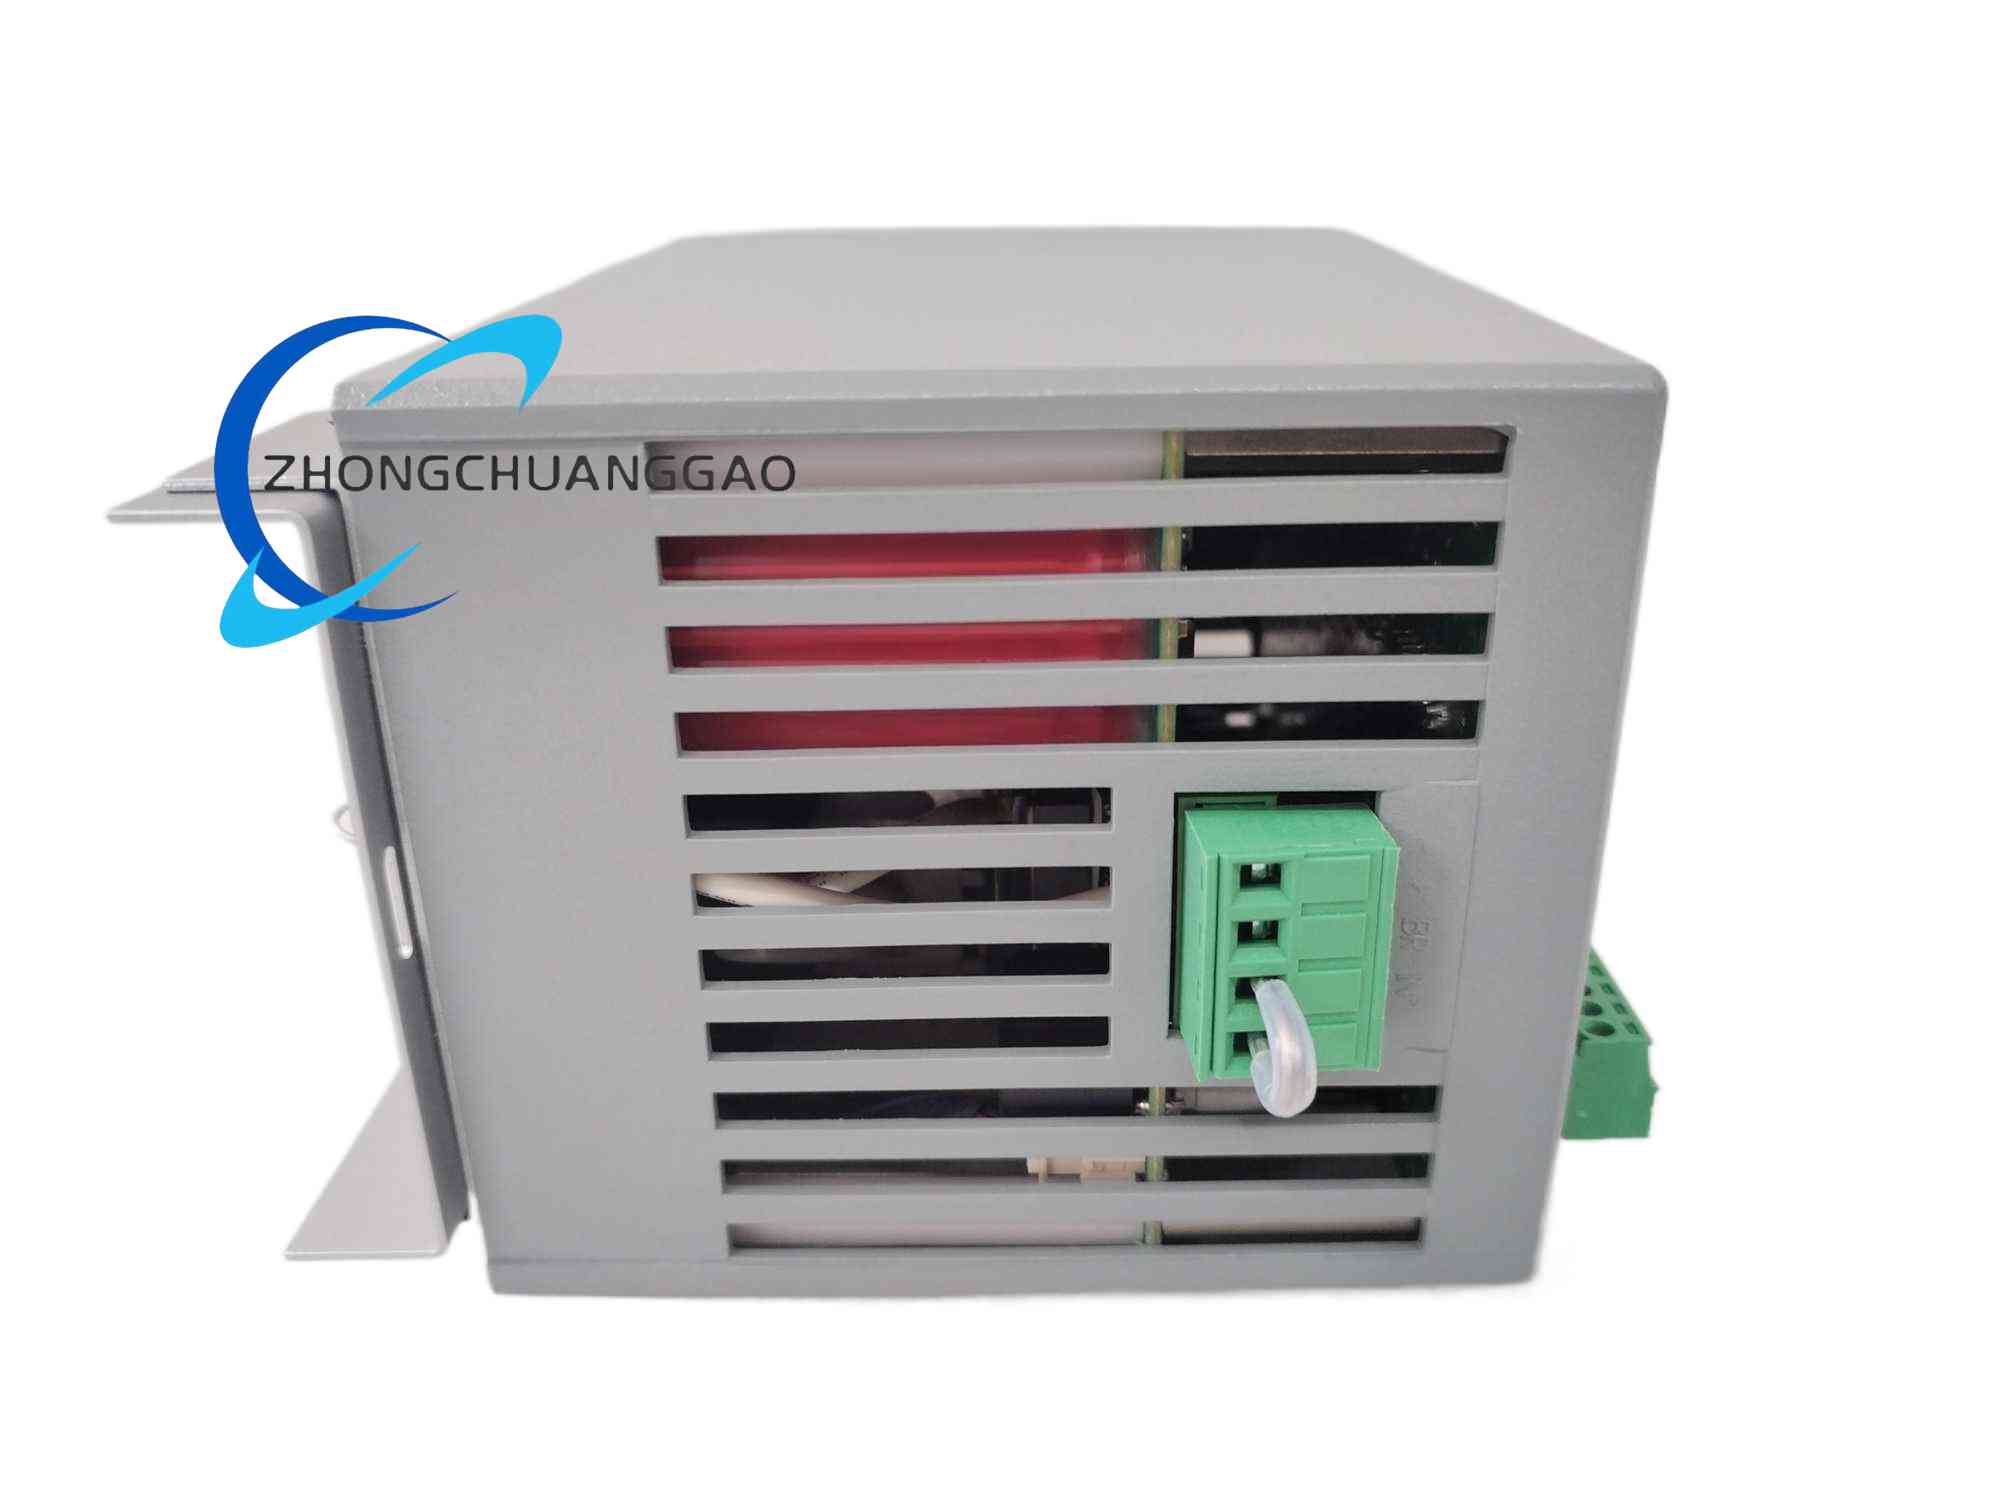
- Removable screw terminal & D-Sub dual connector design: Power circuit adopts anti-loosening screw terminal, feedback and communication signals adopt standard D-Sub connector, convenient wiring and maintenance
- Optional handheld keypad module: Support local parameter setting, real-time operating data monitoring, fault code inquiry without upper computer software
Working Principle
- Power Rectification & Inversion Stage: Input AC power is rectified into DC bus voltage through internal rectifier circuit; DSP digital chip outputs PWM pulse width modulation signal to control IGBT power tube inversion, output three-phase adjustable frequency and adjustable voltage AC power to drive servo motor
- Feedback Signal Sampling Stage: Real-time collect motor rotor position and speed signals through encoder/resolver feedback channel, transmit feedback data to main control DSP chip
- Three-Loop Closed-Loop Calculation Stage: DSP chip receives position/speed/torque command signals from upper controller through analog, pulse or fieldbus; compare command value and actual feedback value to calculate error, adjust PWM output signal through PID algorithm to eliminate motion error
- Built-in PLC Logic Operation Stage: Independent PLC processing unit collects digital input signals of equipment limit switch, photoelectric sensor; execute pre-programmed interlock logic, output control signals to relay, solenoid valve and other execution components through digital output channels
- STO Safety Protection Working Logic: When external safety door, emergency stop safety signal is triggered, STO hardware circuit directly cuts off the drive output PWM signal, the motor loses driving torque immediately; the drive keeps fault lock state until manual safety reset
Material & Structural Features
- Outer Housing: Cold-rolled steel sheet metal shell, electrostatic spray anti-rust coating, compact vertical rectangular structure
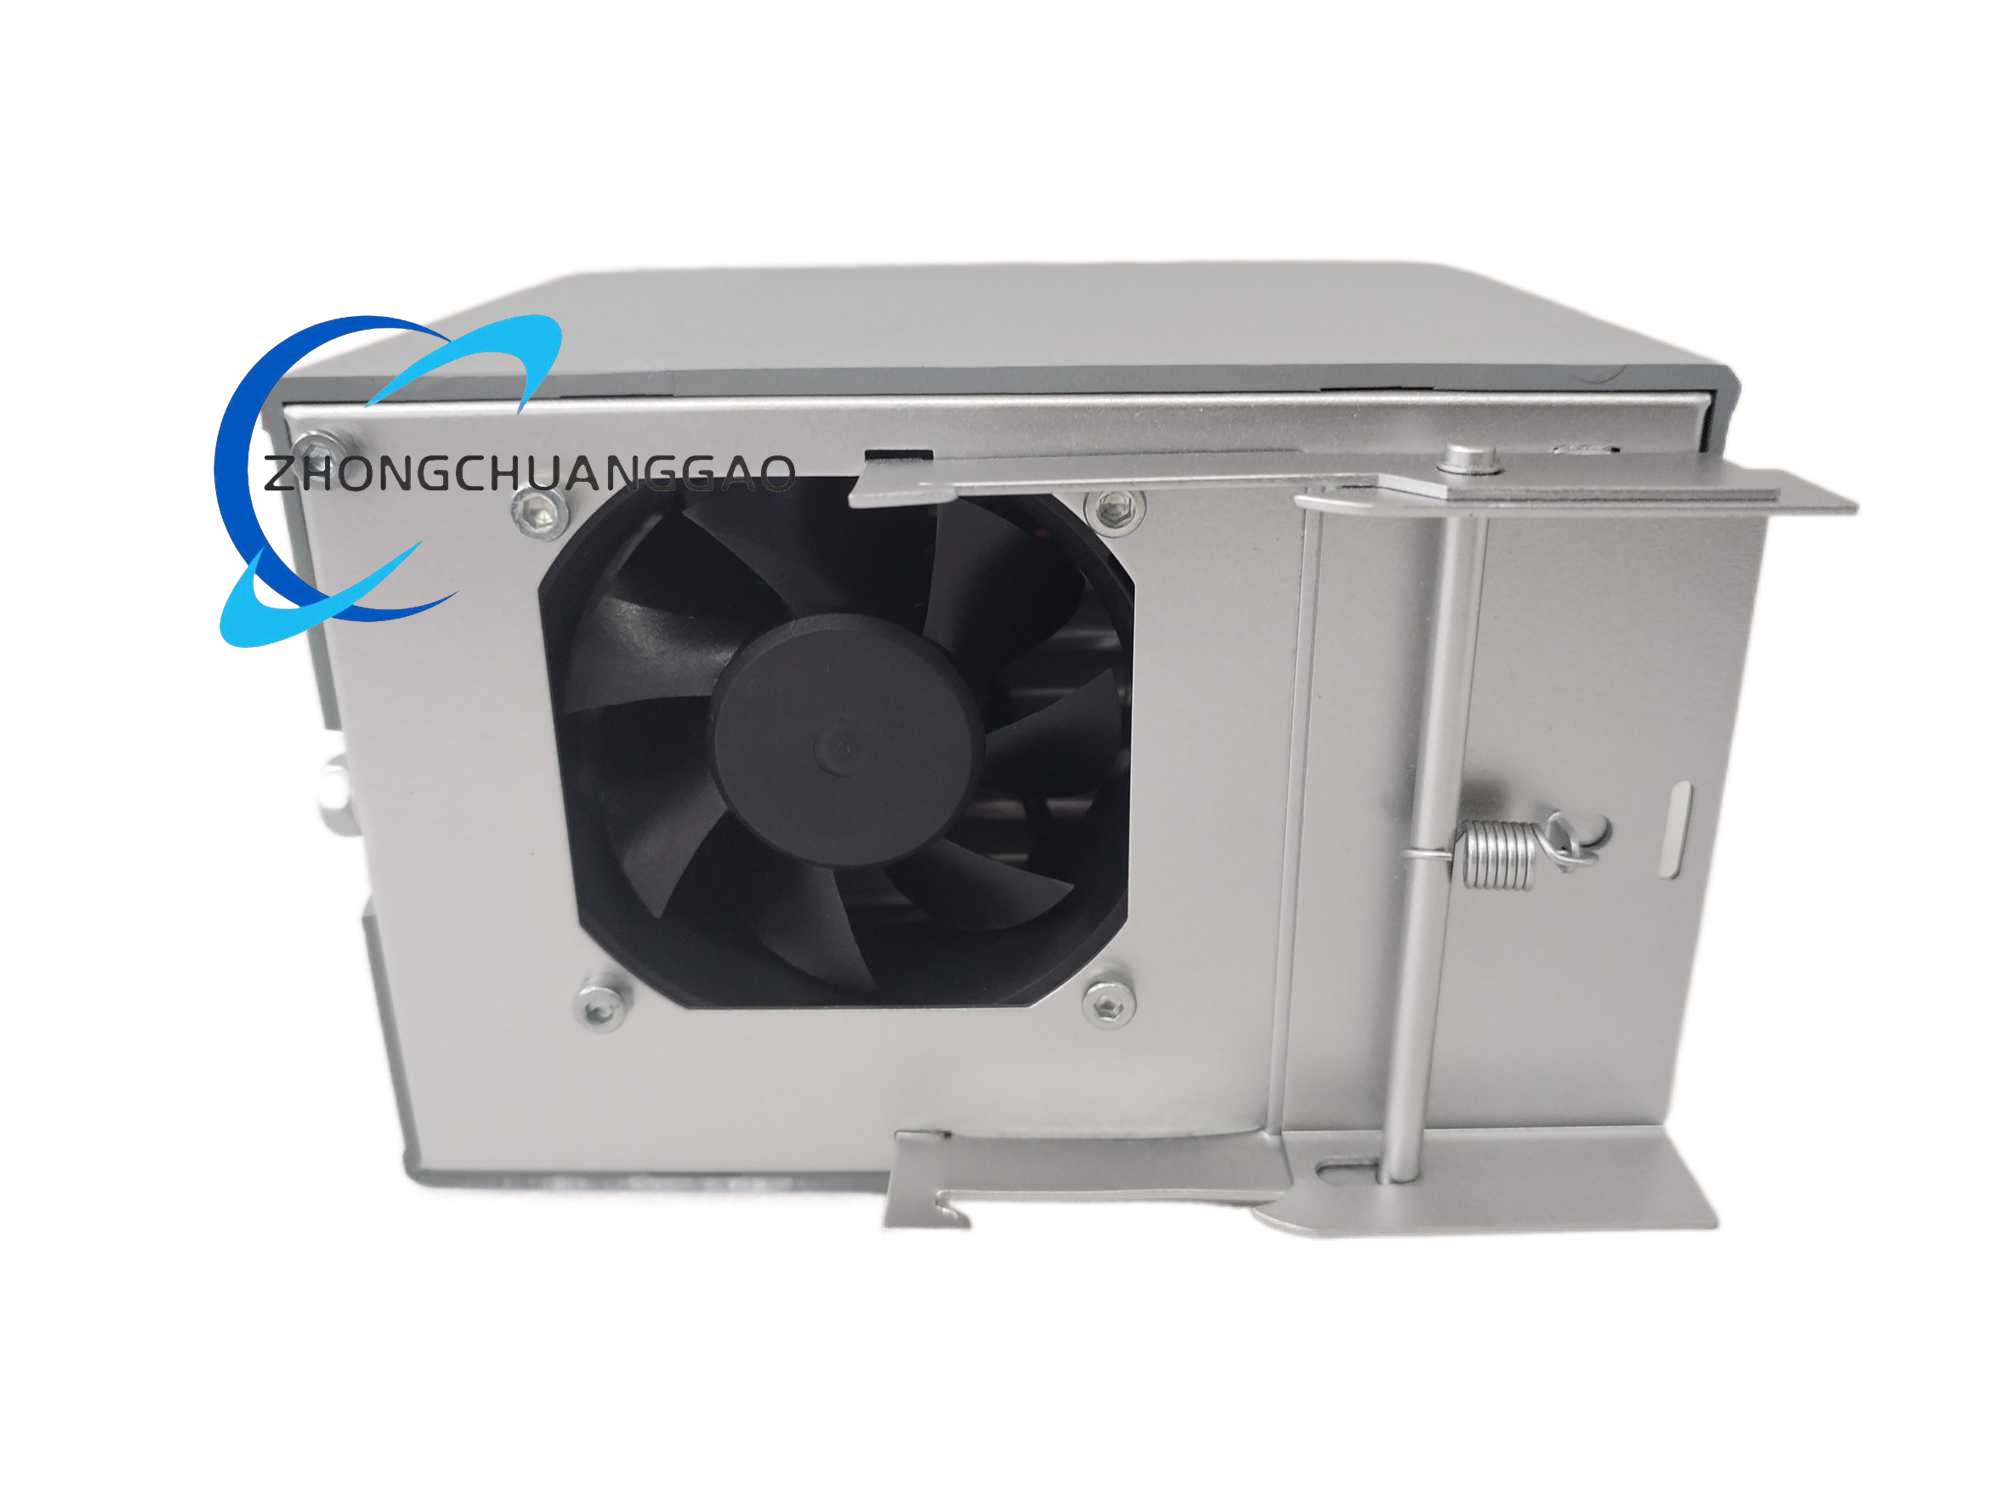
- Internal Power Circuit: High-power IGBT power module, independent heat sink aluminum alloy radiator; radiator with dense heat dissipation fins, passive air cooling heat dissipation design
- Main Control Circuit Board: Multi-layer industrial PCB board, military-grade DSP main control chip, isolated optocoupler chip for signal isolation between power circuit and control circuit
- Connector Structure Classification:
- Power terminal: High-current copper screw terminal block, with anti-loosening spring gasket
- Feedback & communication connector: Standard D-Sub 15-pin industrial connector, dustproof plastic protective cover
- Mounting Structure: Omega guide slide rail fixing structure, vertical installation on cabinet DIN rail, reserved mounting holes on the back of the shell for screw fixed installation
Installation Requirements
- Installation Direction: Must be installed vertically; heat dissipation fins must keep vertical upward air circulation, horizontal or inverted installation is prohibited
- Cabinet Installation Spacing: Reserve more than 50mm heat dissipation gap above and below the drive; when multiple servo drives are installed side by side, the horizontal gap between two drives must be greater than 30mm
- Wiring Specification:
- Power cable: Use shielded three-core copper cable with wire diameter matching output current; shielding layer single-point grounding at cabinet ground bar
- Encoder feedback cable: Special double-shielded high-flex servo encoder cable, separate wiring trough from power cable to avoid electromagnetic interference
- STO safety signal cable: Independent twisted pair shielded cable, cannot be bundled with power cable
- Grounding Requirements: Drive shell ground terminal must connect to cabinet protective ground wire with wire diameter ≥2.0mm² copper wire; separate grounding wire for power circuit and control circuit
- Ambient Installation Environment: Install in sealed industrial control cabinet, install industrial exhaust fan for forced air cooling when multiple high-power drives work simultaneously; avoid installation near heat sources, oil mist, corrosive gas and dust accumulation areas
Application Scenarios
- Packaging machinery: Vertical packaging machines, carton sealing equipment, labeling machines, film slitting constant tension control
- Precision automated assembly equipment: Electronic product pick-and-place manipulators, screw locking machines, connector automatic insertion equipment
- Printing & textile machinery: Small digital printing presses, textile warp feeding synchronous axis, embroidery machine multi-axis synchronous motion control
- Medical automation equipment: Medical reagent automatic dispensing equipment, small medical inspection manipulators
- General industrial automation equipment: Small CNC drilling and milling machines, cutting equipment, automatic conveying positioning trolleys
Operation & Maintenance Precautions
- Before power-on, check whether the STO safety circuit wiring is intact; emergency stop and safety door signals must be connected to STO dedicated terminals, cannot use ordinary digital input terminals instead
- Do not plug or unplug encoder feedback cables when the drive is powered on; hot plug will cause permanent damage to the feedback signal chip
- Regularly clean the radiator heat dissipation fins every three months, remove accumulated dust and lint to avoid poor heat dissipation triggering over-temperature fault alarm
- When modifying electronic cam, electronic gearing motion parameters, stop the equipment axis operation first, parameter modification during high-speed operation will cause axis runaway risk
- The built-in PLC program modification must save the program file to the upper computer for backup; after program loss due to power failure, the backup file needs to be re-downloaded
- If over-current, over-voltage fault codes appear frequently, check whether the servo motor winding insulation is damaged, whether the power cable has short-circuit hidden dangers
- Storage environment of spare drives must keep dry, avoid long-term storage in high-humidity and low-temperature environment to prevent circuit board moisture corrosion
Reviews
There are no reviews yet.