
Product Short Description
Product Overview
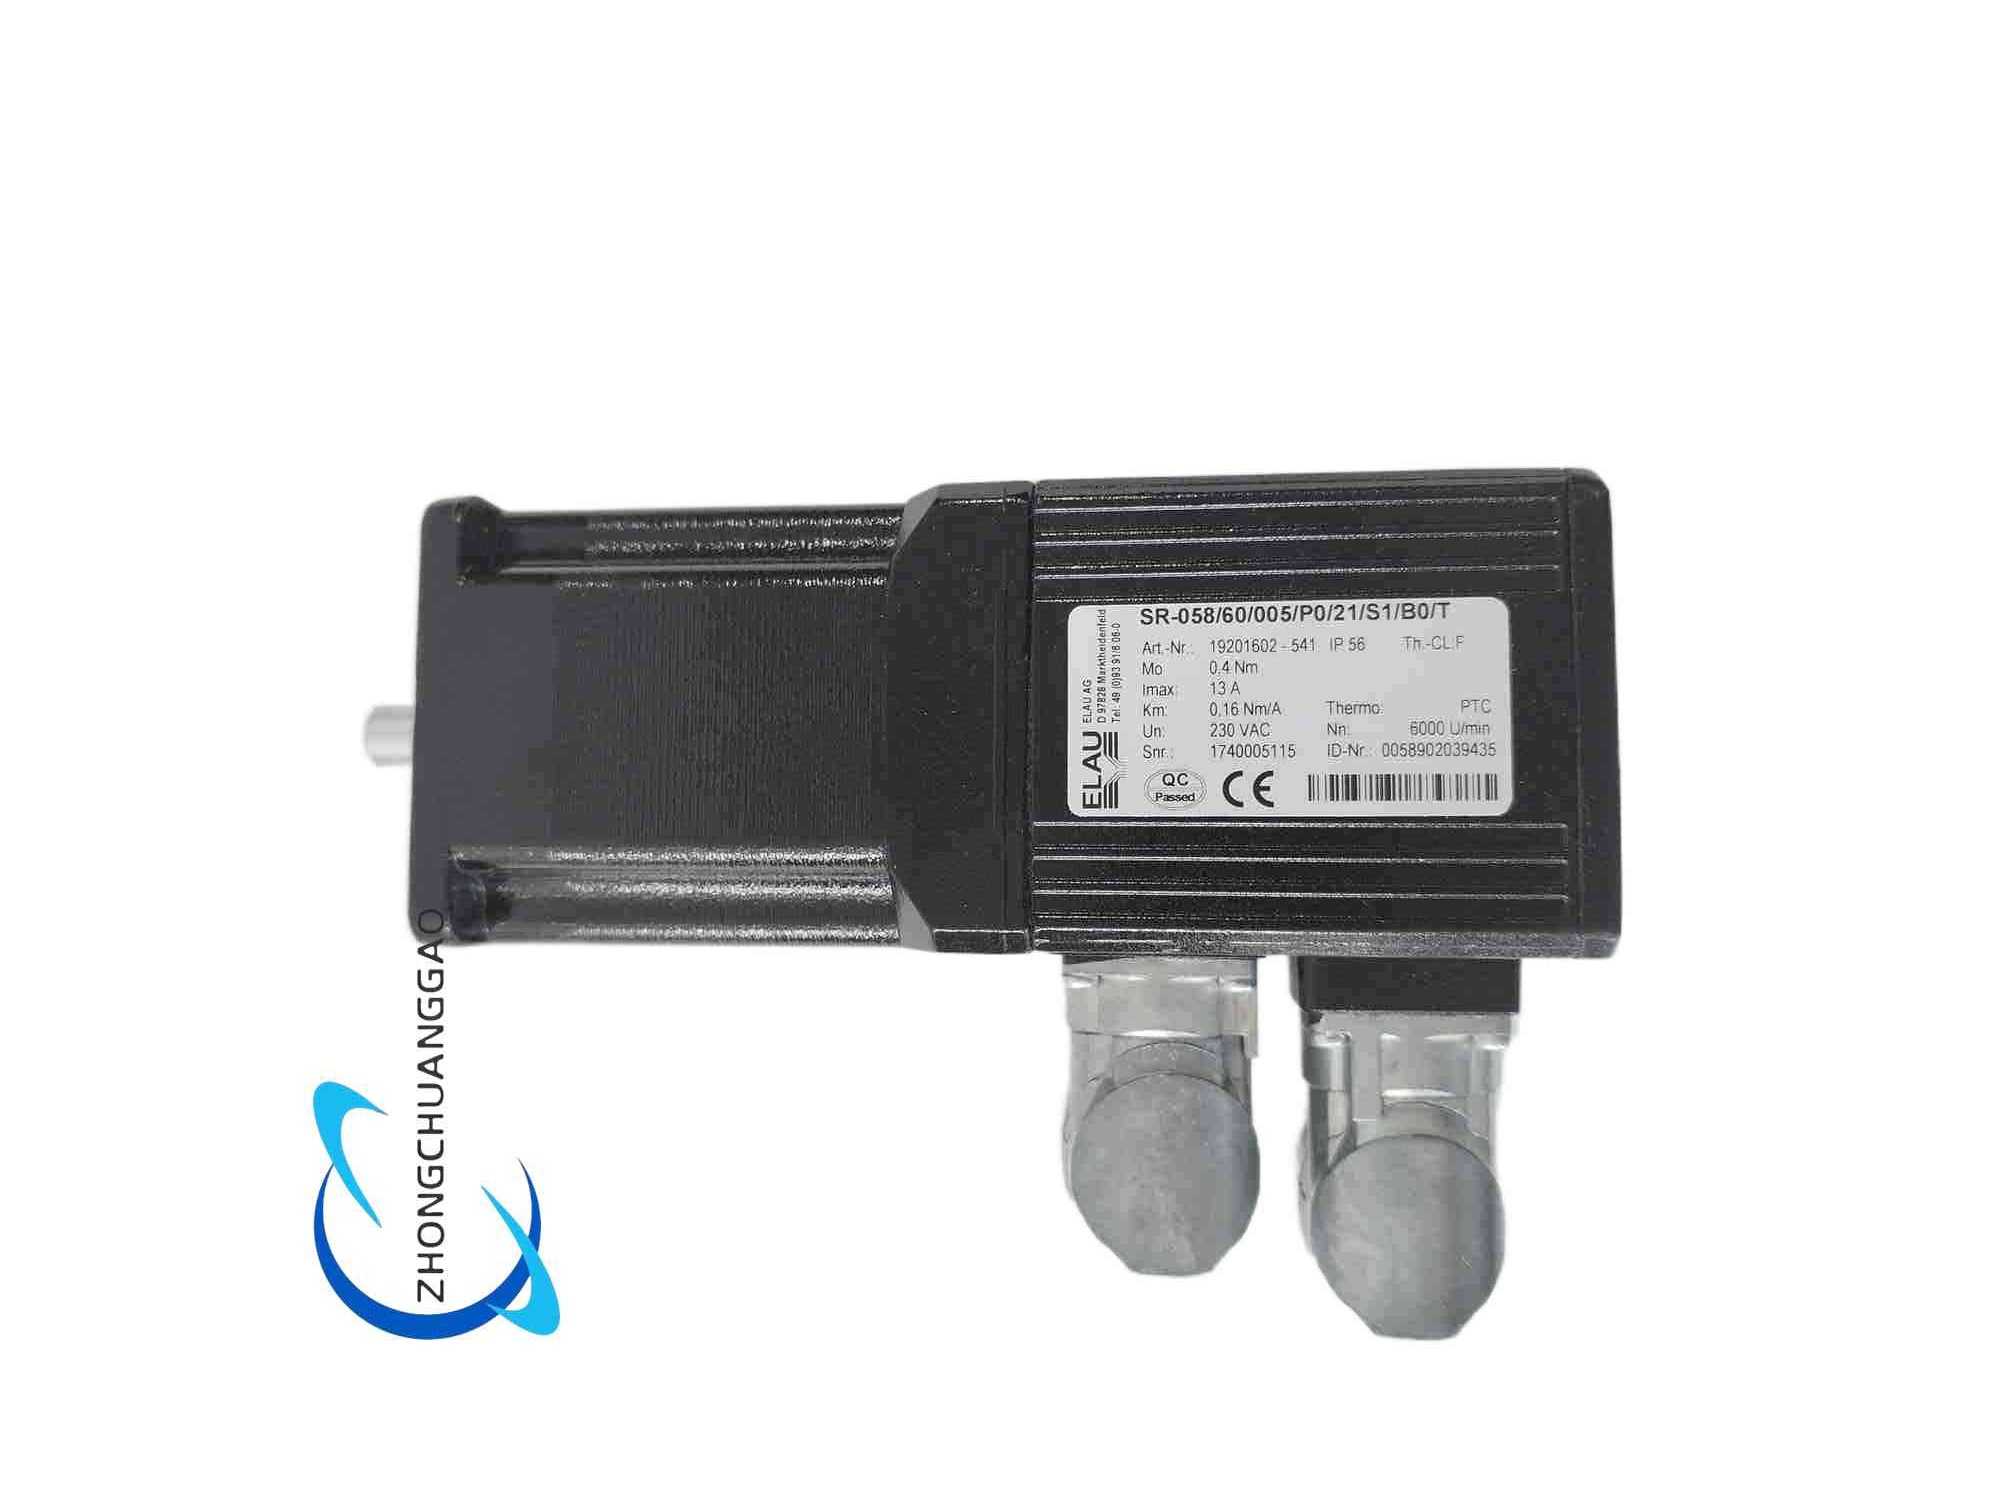
This model is a compact low-inertia permanent magnet synchronous servo motor manufactured by ELAU AG (Schneider Electric Motion Division), specially optimized for high-speed cyclic motion control of packaging machinery, food processing automation and light industrial robotics. The full model coding SR-05860005P021S1B0T encodes complete motor specification information: SR series servo motor, stator frame size 58mm, rated power 0.5kW, P0 standard shaft flat key, 21 standard flange mounting size, S1 continuous duty operation rating, B0 standard brake-less configuration, T standard 20-bit absolute multi-turn encoder interface.
Description
Core Technical Specifications
- Rated Mechanical Output Power: 0.5 kW
- Rated Torque: 2.7 N·m continuous; Peak Overload Torque: 8.1 N·m (3× rated torque, 30s maximum overload duration)
- Rated Rotational Speed: 3000 rpm; Maximum Mechanical Speed: 6000 rpm
- Rotor Inertia: Ultra-low 0.00012 kg·m² for rapid cyclic acceleration
- Encoder Configuration: 20-bit absolute multi-turn optical encoder (1,048,576 position pulses per revolution), battery-free single-turn position retention
- Rated Input Voltage: Three-phase AC 230 V
- Rated Continuous Current: 13 A RMS
- Insulation Class: Class F (maximum allowable stator winding surface temperature 155°C)
- Protection Rating: IP65 motor housing and output shaft; IP54 electrical connector terminal area
- Operating Ambient Temperature: -20°C ~ +40°C; Maximum allowable motor surface operating temperature +100°C
- Vibration Resistance Standard: IEC 60068-2-6, 10–500Hz frequency sweep, 8g peak vibration acceleration
- Shock Resistance Standard: IEC 60068-2-27, 25g peak shock acceleration, 11ms shock pulse duration
- Mechanical Dimensions: Flange mounting 58mm square frame, output shaft diameter 14mm, motor overall axial length 30mm
- Net Weight: 1.2 kg
- Certifications: CE, UL 1004-1, IEC 60034-1, RoHS, ISO 13485 medical equipment compatibility certification
Material Composition & Structural Features
- Motor Stator Housing: High-precision extruded aluminum alloy cylindrical housing with integrated axial cooling rib structure, hard anodized anti-corrosion surface treatment
- Stator Winding Core: Silicon steel laminated stator core with high copper fill factor enameled copper wire windings impregnated with high-temperature epoxy varnish
- Rotor Assembly: Rare-earth NdFeB permanent magnet surface-mounted rotor, balanced precision dynamic balancing treatment to eliminate high-speed vibration
- Output Shaft & Sealing: 40Cr alloy steel quenched and tempered output shaft with standard flat key slot; nitrile rubber double-lip shaft oil seal to achieve IP65 dust and water spray resistance
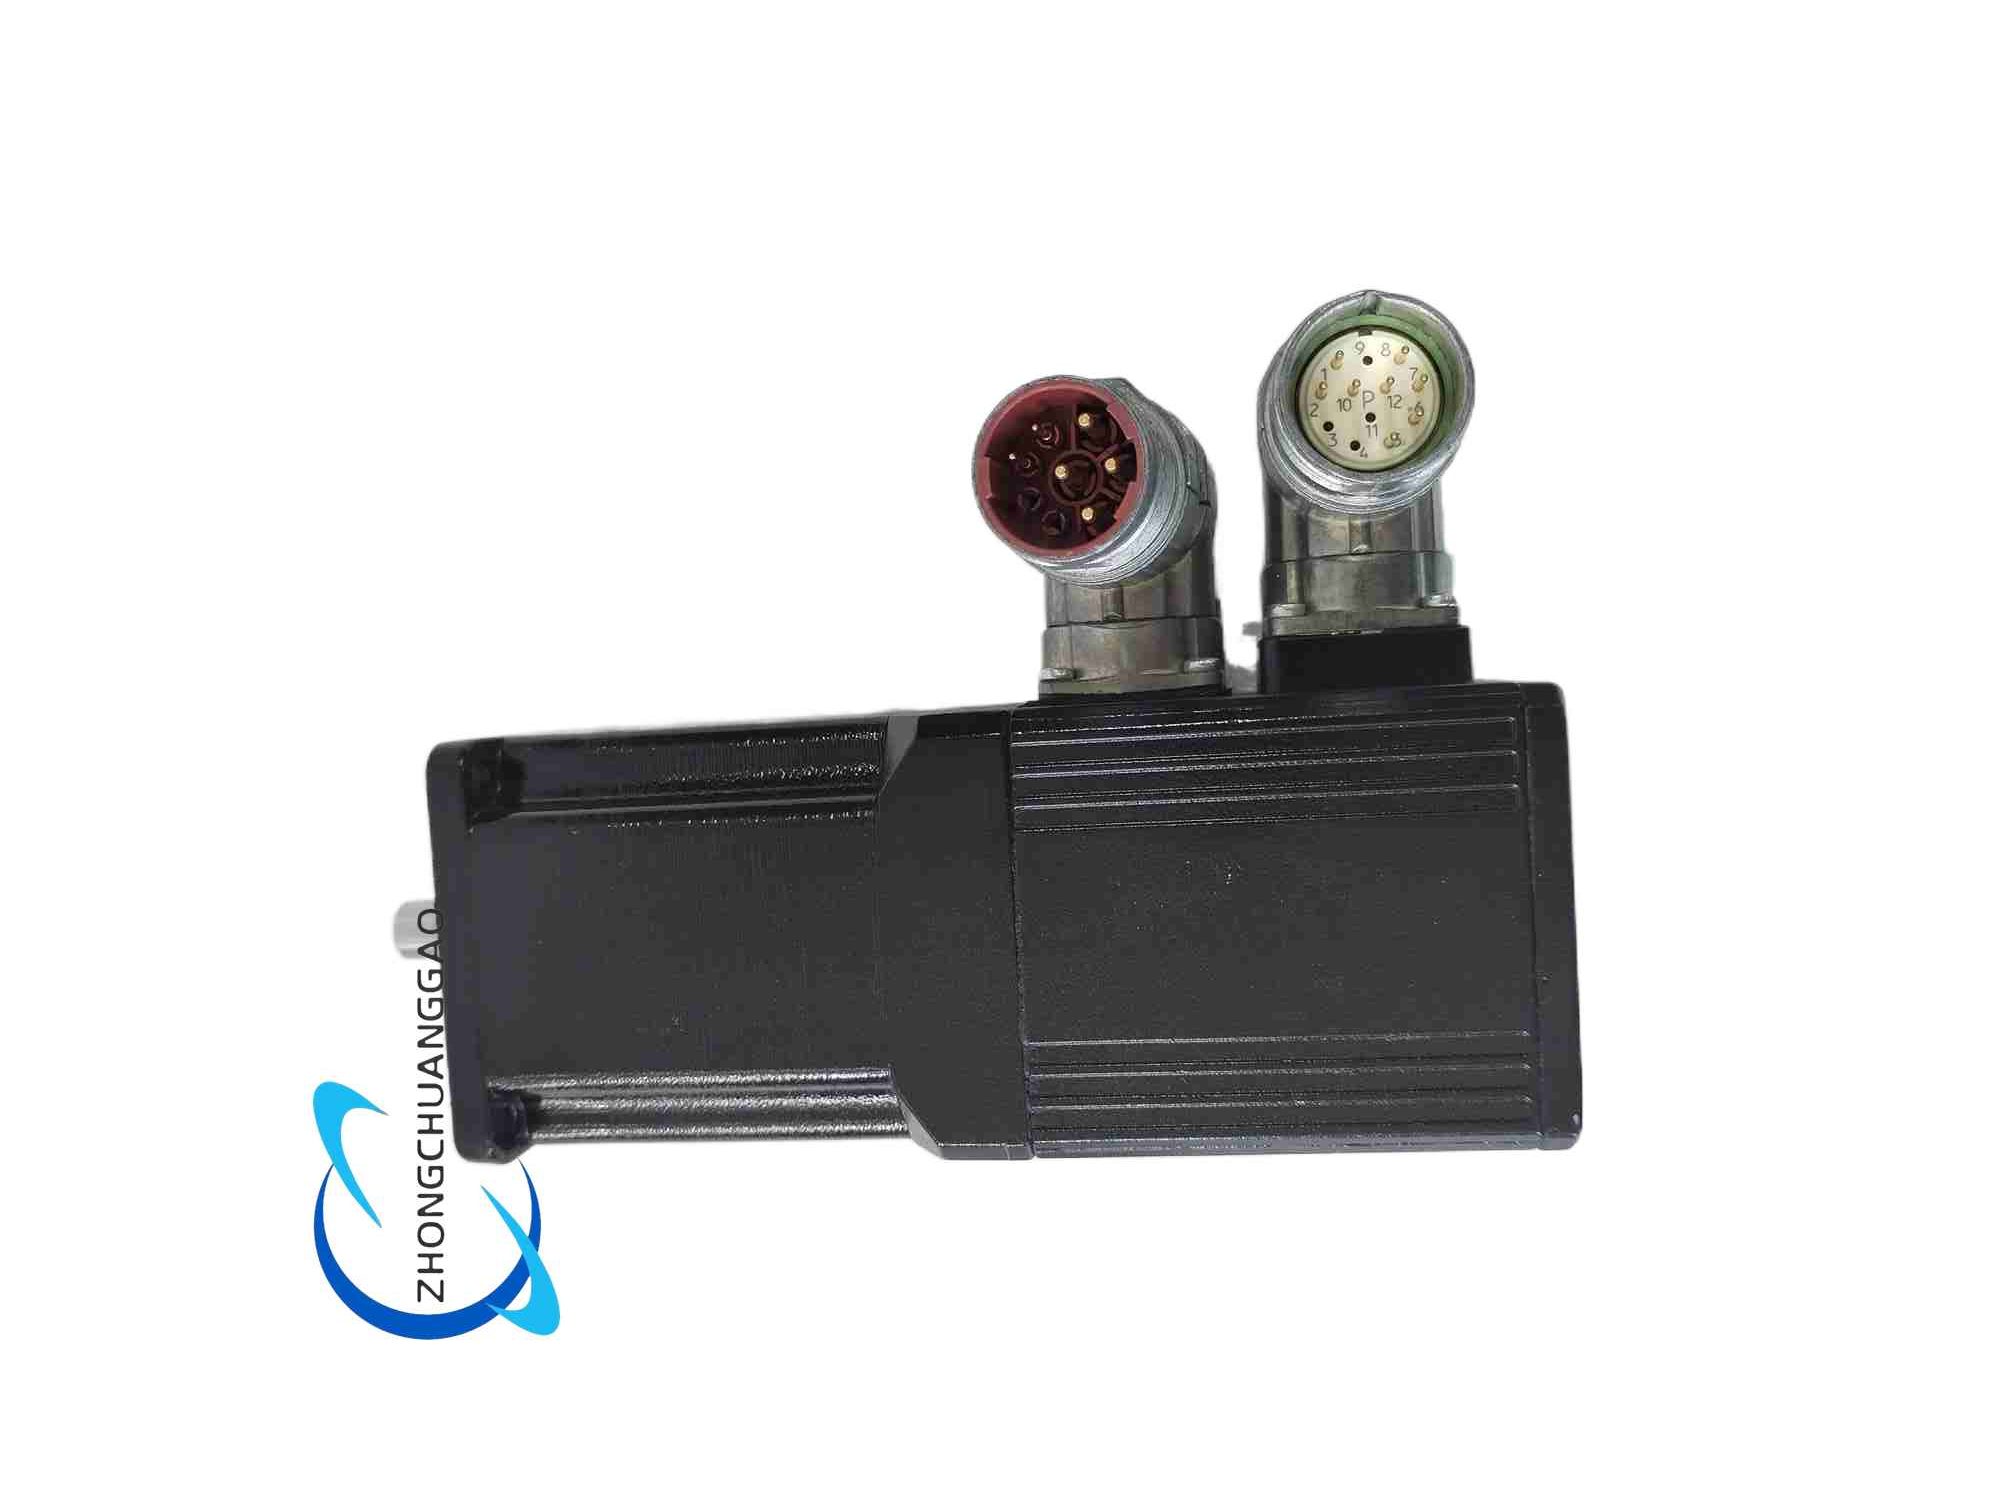
- Electrical Connection Structure: Dual independent quick-disconnect circular industrial connectors; one power connector for three-phase stator winding power transmission, one encoder connector for absolute encoder position signal feedback
- Mounting Flange: Die-cast aluminum square mounting flange with four symmetrical M4 mounting bolt holes, flat precision machined flange mounting surface
- Internal Bearings: Double-row high-precision sealed ceramic ball bearings at front and rear shaft ends, low friction coefficient for long high-speed service life
Working Principle
- ELAU PacDrive servo drive outputs three-phase sinusoidal variable frequency variable amplitude alternating current to the motor stator three-phase windings
- Three-phase alternating current generates rotating electromagnetic magnetic field inside the stator laminated core, rotating speed proportional to input AC frequency
- Surface-mounted rare-earth permanent magnets on the rotor form fixed permanent magnetic poles; stator rotating magnetic field generates electromagnetic traction torque acting on rotor permanent magnets, driving rotor and output mechanical shaft to synchronously rotate with stator rotating magnetic field
- 20-bit absolute multi-turn optical encoder installed at the motor rear shaft end synchronously captures real-time rotor absolute angular position and rotational speed data, transmits digital position feedback signal back to servo drive via dedicated encoder cable
- Servo drive internal position loop, speed loop and current loop triple closed-loop control algorithm compares encoder actual position feedback value with motion control target position command value; dynamically adjusts output three-phase AC current amplitude and frequency to eliminate position deviation, realizing high-precision positioning and smooth speed regulation
- When transient overload working conditions occur (machine rapid acceleration, impact load), the permanent magnet synchronous motor can output 3 times rated peak torque within 30 seconds to meet short-cycle high dynamic motion demand; built-in stator winding temperature thermistor continuously monitors winding temperature, triggers drive current limiting protection when winding temperature exceeds Class F insulation limit temperature
Application Scenarios
- High-speed horizontal/vertical packaging machinery: carton forming, bottle filling, sealing, labeling, film wrapping multi-axis motion axes
- Food processing automation equipment: pastry molding machine, beverage bottle sorting conveyor, food cutting positioning axis
- Light industrial delta parallel robots, SCARA four-axis assembly robots for electronic component sorting and assembly
- Printing and paper processing equipment: label printing press, paper slitting machine precision traction and cutting axes
- Pharmaceutical automatic blister packaging, tablet counting and bottle filling automation lines
Installation Requirements
- Flange Mounting Surface Requirement: Machine frame mounting plane flatness error ≤ 0.1mm per 100mm length; thoroughly clean mounting surface metal burrs, dust and oil stains before installation
- Mounting Bolt Torque Standard: Four M4 stainless steel flange mounting bolts tightened to fixed torque 4 N·m; strictly prohibit over-tightening bolts to avoid aluminum flange deformation and bearing shaft misalignment
- Shaft Load Connection Standard: Connect motor output shaft to mechanical load only through zero-backlash flexible coupling; rigid direct shaft connection without coupling will generate radial and axial offset load, rapidly wearing front motor bearing
- Cable Wiring Separation Rule: Separate motor three-phase power cable and encoder signal cable with minimum 20cm wiring spacing; power cable carries high-frequency high-current which generates strong electromagnetic interference, easily distorting encoder precise position signal
- Connector Installation Sealing Requirement: Fully tighten both power and encoder circular quick-disconnect connectors after cable wiring; ensure built-in rubber sealing gaskets are fully compressed to maintain IP65 protection rating at connector joint surfaces
- Heat Dissipation Installation Restriction: Do not install the motor in fully enclosed sealed cavities without air circulation; maintain minimum 30mm natural convection air gap around motor aluminum cooling housing
Operation & Maintenance Precautions
- Startup Pre-Check Rule: Before servo system power-on, manually rotate motor output shaft by hand to confirm no mechanical jamming or excessive rotational resistance; mechanical stuck load will trigger servo drive over-current fault and risk stator winding burnout
- Overload Duration Limit: Continuous peak torque overload operation exceeding 30 seconds is prohibited; long-term high overload will cause stator winding temperature to exceed Class F insulation limit, accelerating insulation aging and permanent magnet demagnetization
- Shaft Seal Regular Inspection: Conduct quarterly visual inspection of output shaft nitrile rubber oil seal; if oil leakage, crack or hardening aging is observed, replace the shaft oil seal immediately to prevent dust and cooling water from penetrating into internal bearings and stator windings
- Encoder Cable Maintenance: Avoid repeated bending, pulling or sharp-angle extrusion of the encoder signal cable; internal fine multi-turn encoder signal wires are fragile, cable damage will cause position feedback loss and servo out-of-control runaway risk
- Long-Term Shutdown Storage: For motors stored as spare parts for more than 6 months, rotate the output shaft manually once per month to prevent bearing lubricating oil solidification and shaft rusting; store in temperature-controlled dry warehouse (10°C ~ 30°C, relative humidity ≤ 60%)
- Winding Temperature Protection Response: If servo drive triggers motor over-temperature protection and shuts down motion axes, cut off servo power supply and allow the motor to naturally cool to ambient temperature; do not forcibly restart the system while the motor remains high-temperature to avoid permanent magnet irreversible demagnetization

Reviews
There are no reviews yet.