
Product Short Description
Product Introduction
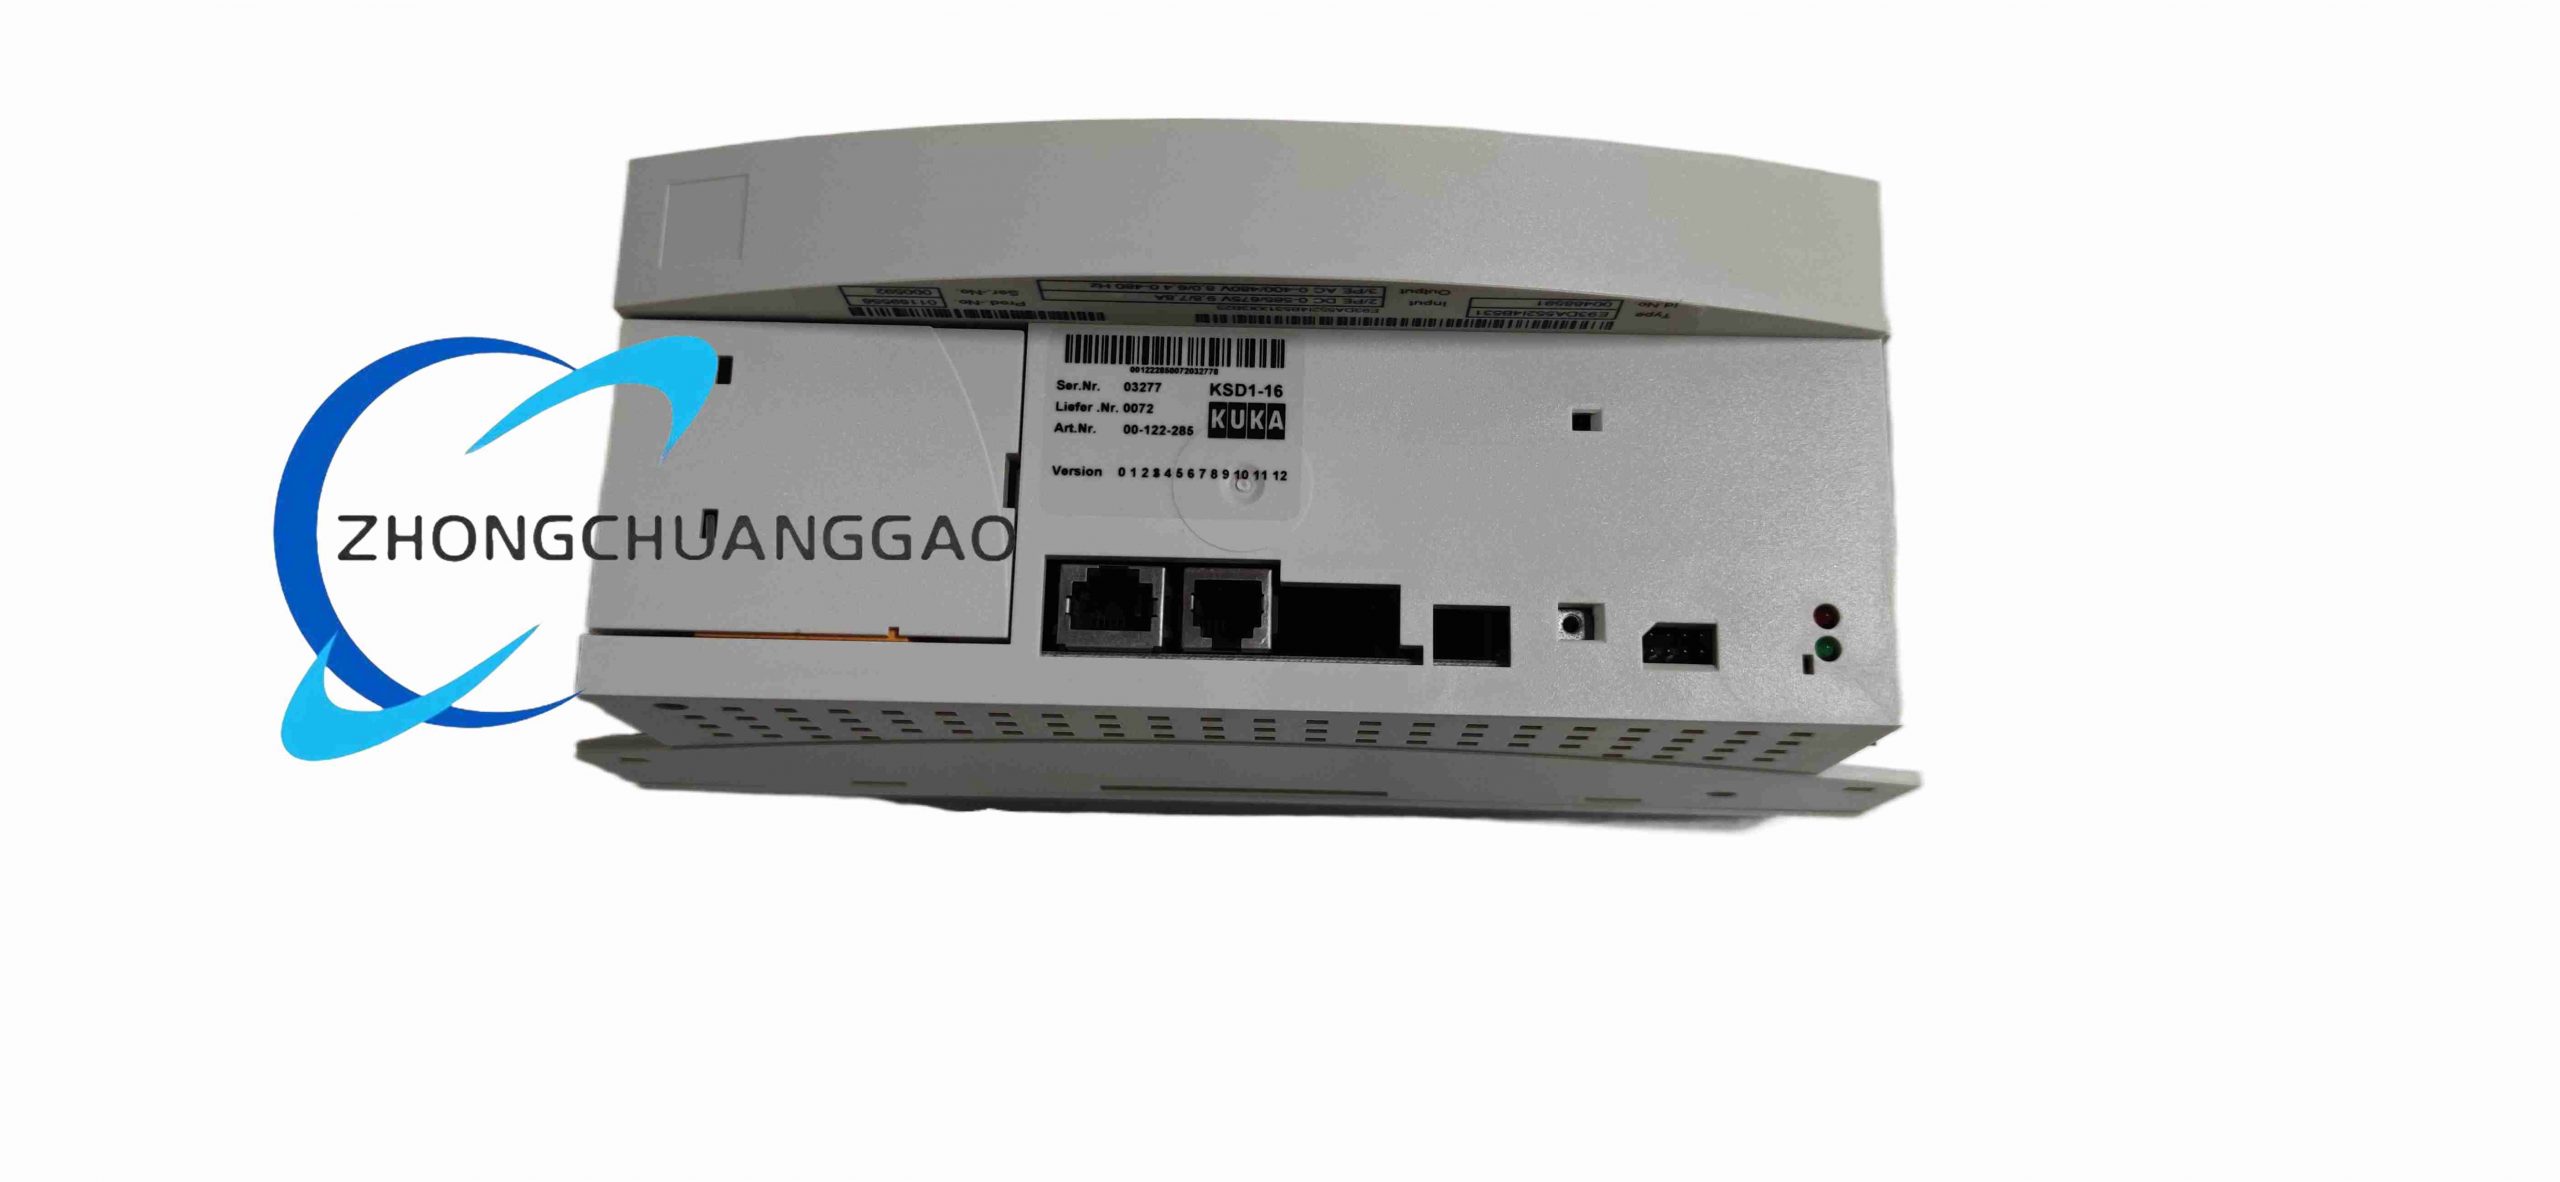
The KSD1-16 is a dedicated modular servo drive exclusively designed for KUKA KRC2 industrial robot cabinets, acting as the power and motion control core for single robot joint axes. It converts DC bus voltage into precise three-phase AC output to drive KUKA synchronous robot servo motors, delivering closed-loop position, speed and torque control for low-to-medium load robot arms used in assembly, handling and light welding applications.
Description
Technical & Performance Specifications
- Electrical Parameters
- DC Link Input Voltage: 0–770 VDC shared bus from KPS power supply
- Rated Continuous Output Current: 8 Arms
- Peak Short-Time Output Current: 16 Arms (model naming basis)
- Three-Phase AC Motor Output: 0–480 VAC, 0–480 Hz frequency bandwidth
- Standstill Holding Current: 8.5 Arms
- Power Matching: Supports robot servo motors up to 7.5 kW rated power
- Control Switching Frequency: 16 kHz high-speed PWM modulation
- Physical Dimensions & Weight
- Form Factor Width: 88 mm standard KSD1 single module width
- Overall Size: 88 mm (W) × 240 mm (D) × 180 mm (H)
- Net Weight: 1.36 kg
- Environmental Ratings
- Operating Temperature: 0°C to +55°C inside control cabinet
- Storage Temperature: -25°C to +70°C
- Protection Class: IP20 (indoor cabinet installation only)
- Vibration Resistance: 10–150 Hz, 10 m/s² compliant with IEC 60068
- Communication Interfaces
- X13 Interbus IN / X14 Interbus OUT daisy-chain robot bus
- 24 VDC auxiliary power terminal X1 for internal cabinet logic
- X2/X3 heavy-duty motor power terminals with shield grounding
- Motor encoder feedback port for resolver / sine-cosine encoder signals
Function Features
- Full closed-loop triple control loop: torque loop (fastest), speed loop, position loop
- Integrated multi-layer hardware protection: overcurrent, overvoltage, undervoltage, overtemperature, motor short-circuit, encoder fault monitoring
- Built-in thermal temperature sensor with automatic power derating before shutdown
- Real-time axis diagnostic data transmission to KRC2 robot controller for fault logging
- Smooth torque ripple suppression algorithm for ultra-precise low-speed robot joint movement
- Dynamic braking resistor control interface for fast deceleration of robot moving axes
- Modular hot-swappable mechanical lock design for cabinet maintenance
- Automatic motor parameter identification on power-up for fast commissioning
Working Principle
High-voltage DC power from the KPS600 cabinet power supply enters the DC link circuit. Internal IGBT power switches perform high-frequency PWM modulation to generate variable-frequency three-phase alternating current matching motor motion demand. Encoder signals fed back from the robot motor rotor are compared with position setpoints from the KRC2 main CPU; the drive adjusts output current/torque in real time to eliminate position deviation. Internal temperature and current sensors continuously monitor operating status and trigger protective cut-off if thresholds are breached.
Material & Structural Composition
- Housing Shell: Cold-rolled steel with matte white anti-corrosion powder coating
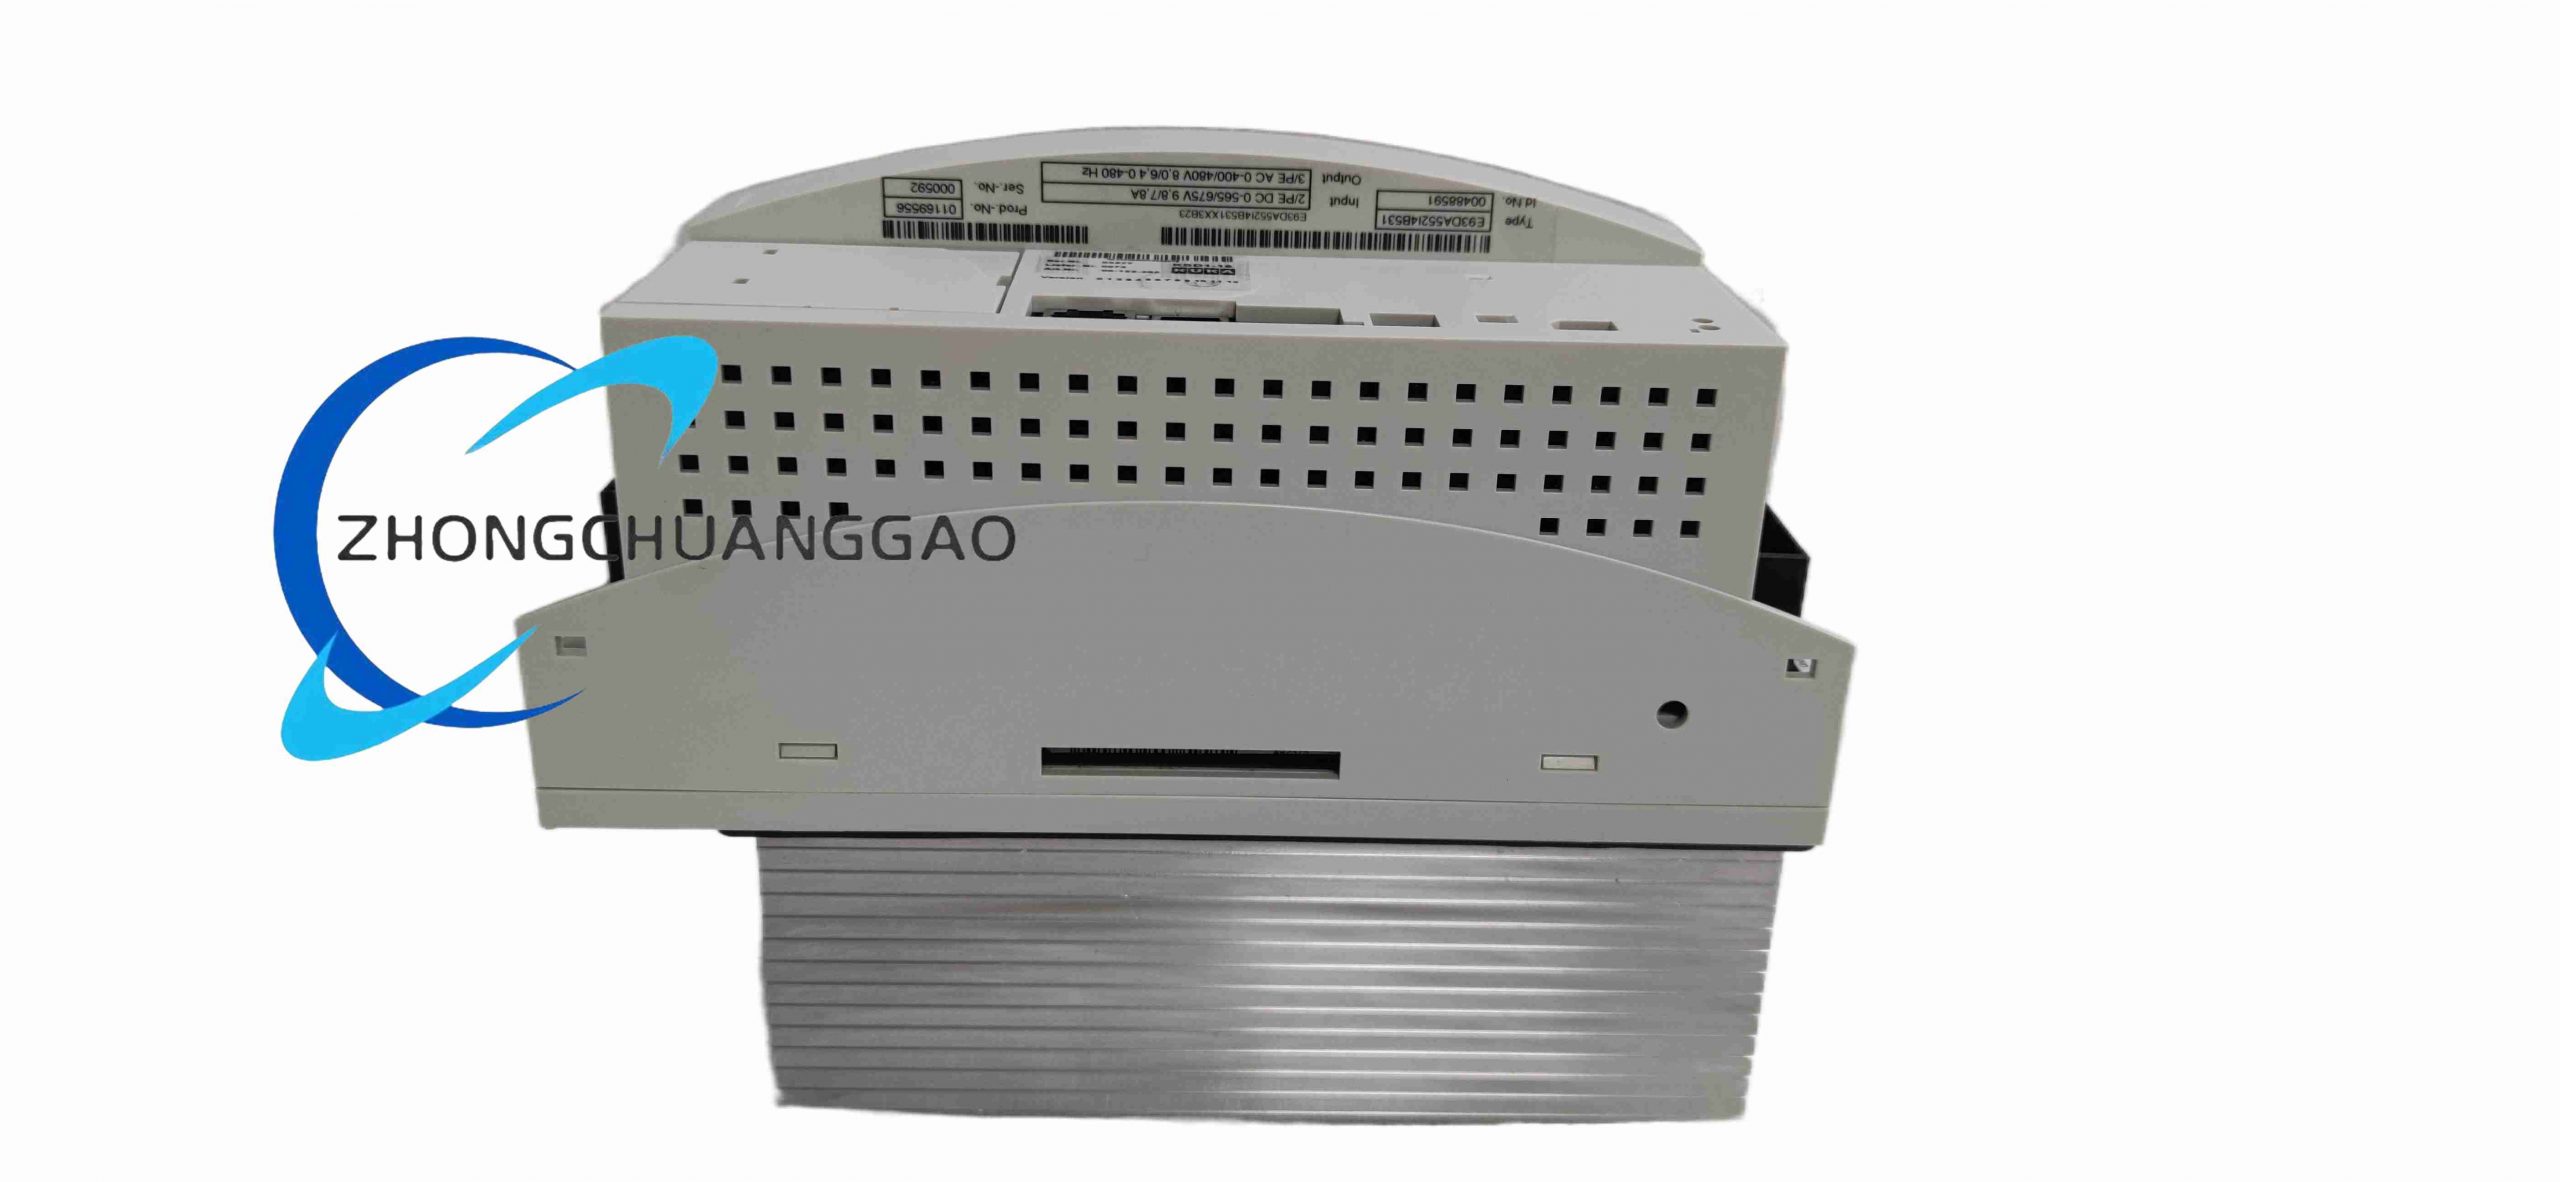
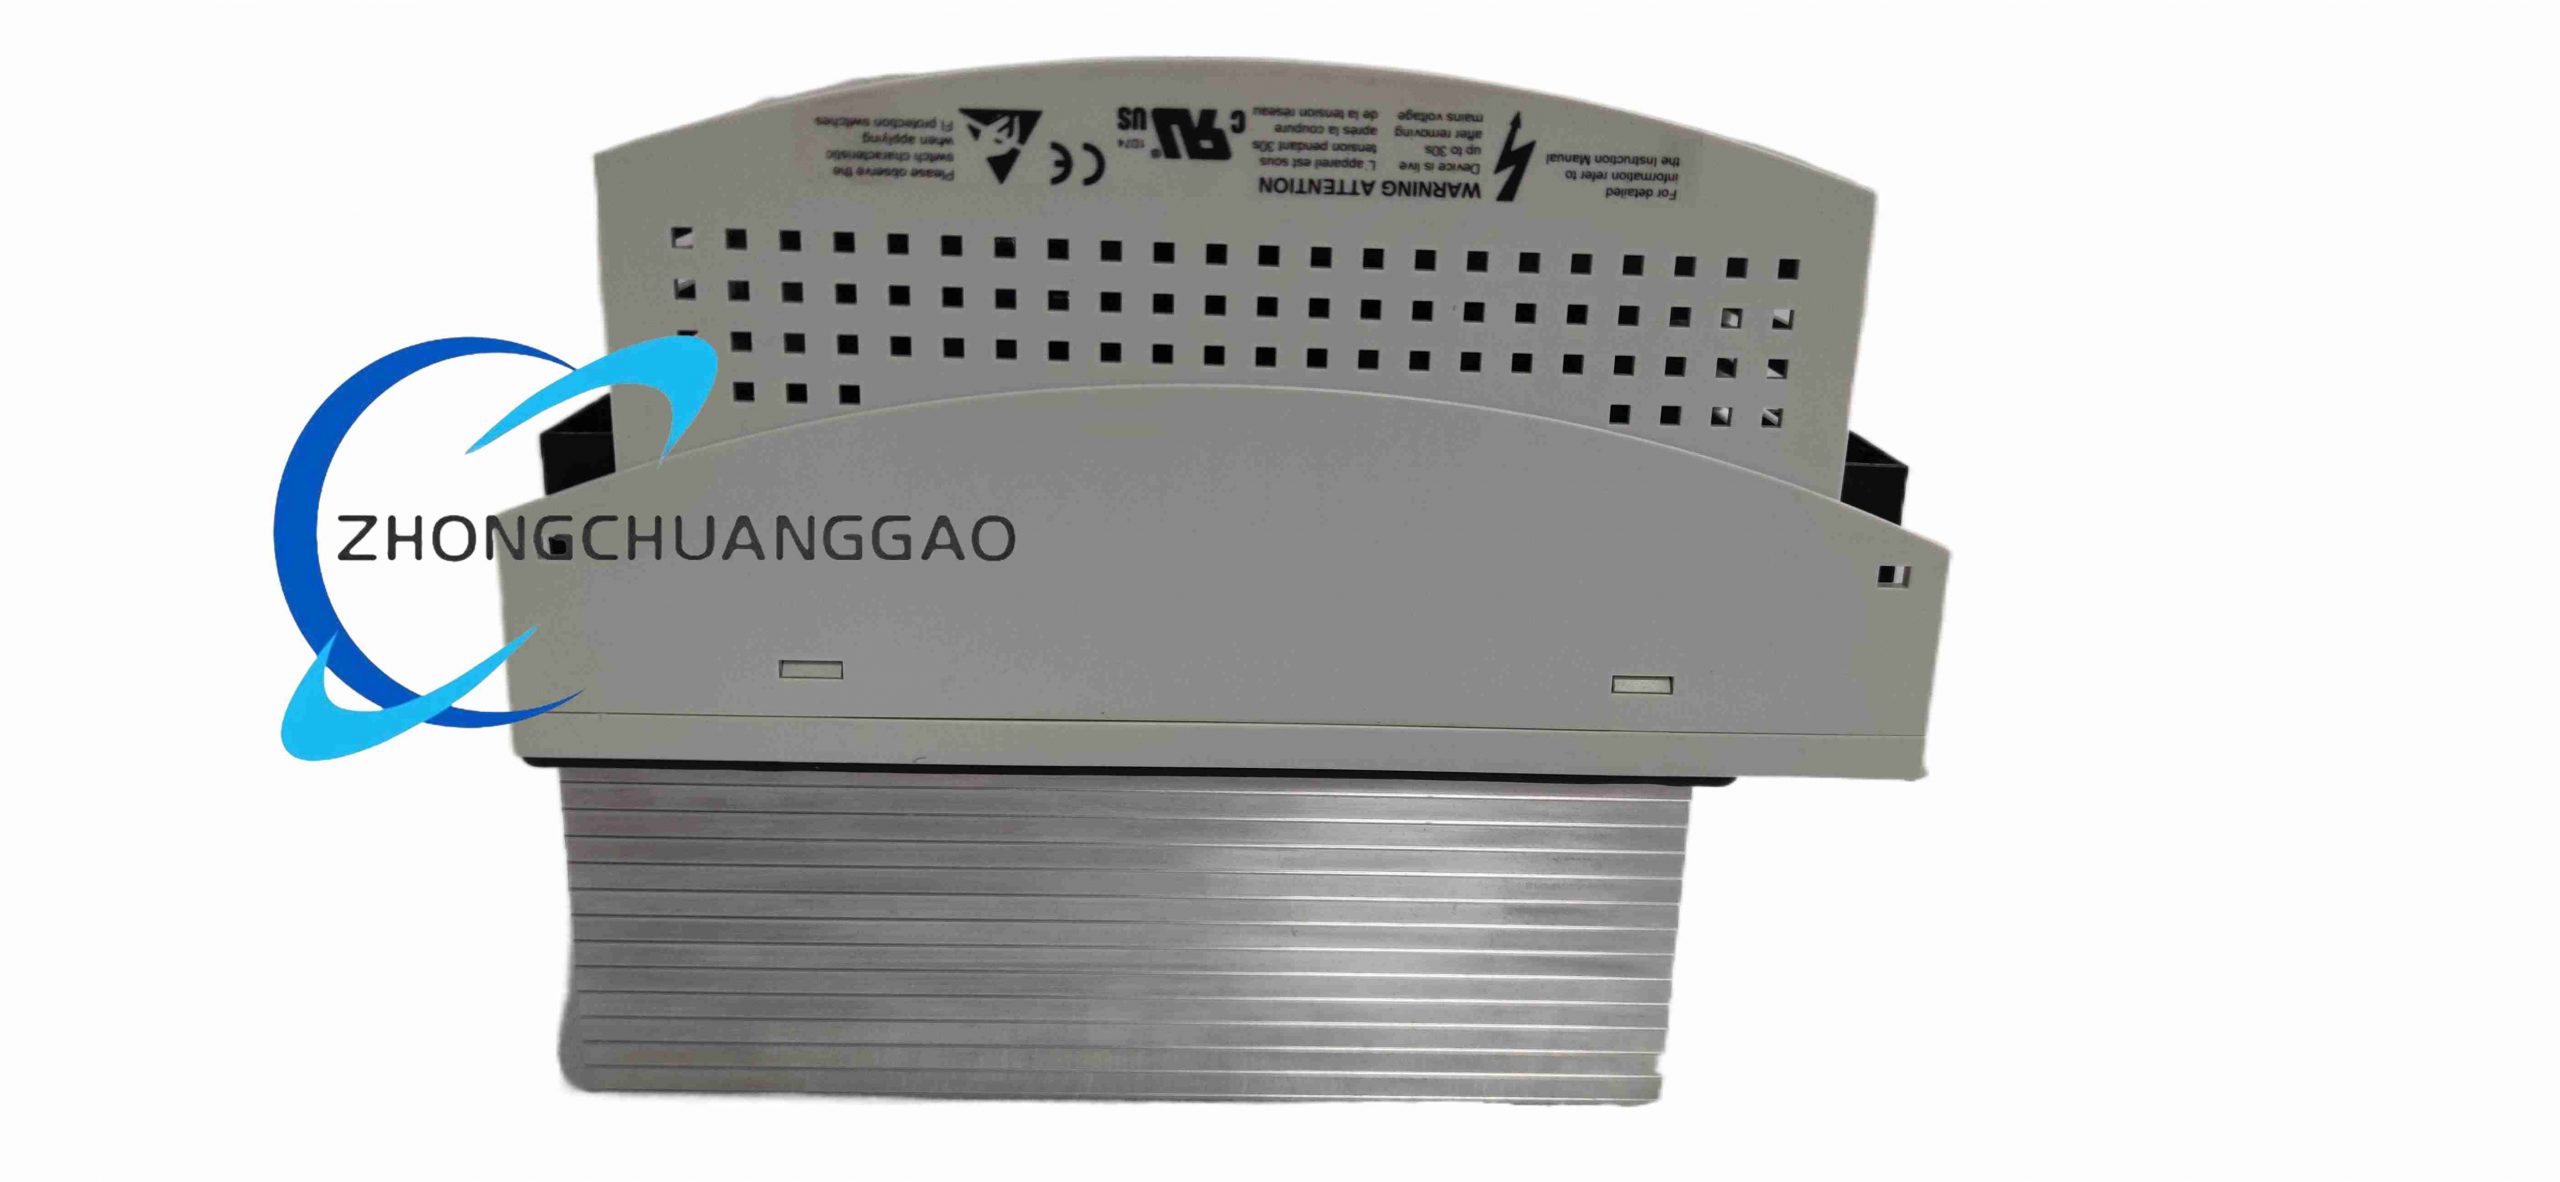
- Heat Dissipation Structure: Extruded aluminum alloy vertical fin heat sink at bottom for passive convection cooling
- Internal PCB: Multi-layer FR4 industrial circuit board with tin-lead-free high-temperature solder
- Power Semiconductors: Silicon IGBT power modules with insulated base plates
- Terminal Blocks: Nickel-plated copper screw terminals with plastic flame-retardant PA66 insulation
- Locking Mechanism: Spring steel slide lock for rack mounting
Installation Requirements
- Must mount vertically on dedicated D mounting plate inside KUKA KRC2 cabinet; maximum 3 KSD1 series drives per standard rack
- Maintain minimum 20 mm vertical clearance above and below drive for air convection heat dissipation
- Motor cable shielding must connect to PE ground terminal on X2/X3 connectors; cable length limited to maximum 15 m
- Interbus communication wiring requires twisted shielded cable, daisy-chain wiring sequence strictly followed
- DC bus wiring torque specification: 2.5 N·m to avoid loose high-current terminals
- Cabinet ambient air circulation fan mandatory to keep internal temperature below 50°C
Application Scenarios
- KUKA KR C2 small-to-medium payload industrial robots (5 kg – 30 kg payload)
- Electronic component assembly robot axes, pick-and-place handling arms
- Light arc welding, glue dispensing and screw fastening robot joints
- Packaging line robotic manipulators with medium dynamic motion demand
Usage Precautions
- Disconnect main cabinet AC power before removing/installing the drive to avoid high-voltage DC link electric shock
- Do not operate without connected motor encoder; drive will trigger hard fault lockout
- Avoid running at 100% peak current continuously for over 30 seconds to prevent thermal overload
- Do not block heat sink ventilation fins with wiring or cable bundles
- If overvoltage fault occurs, check cabinet braking resistor circuit integrity first
- Store in dry, low-dust environment; humidity must stay below 85% non-condensing
Reviews
There are no reviews yet.