
Product Short Description
Product Brief Introduction
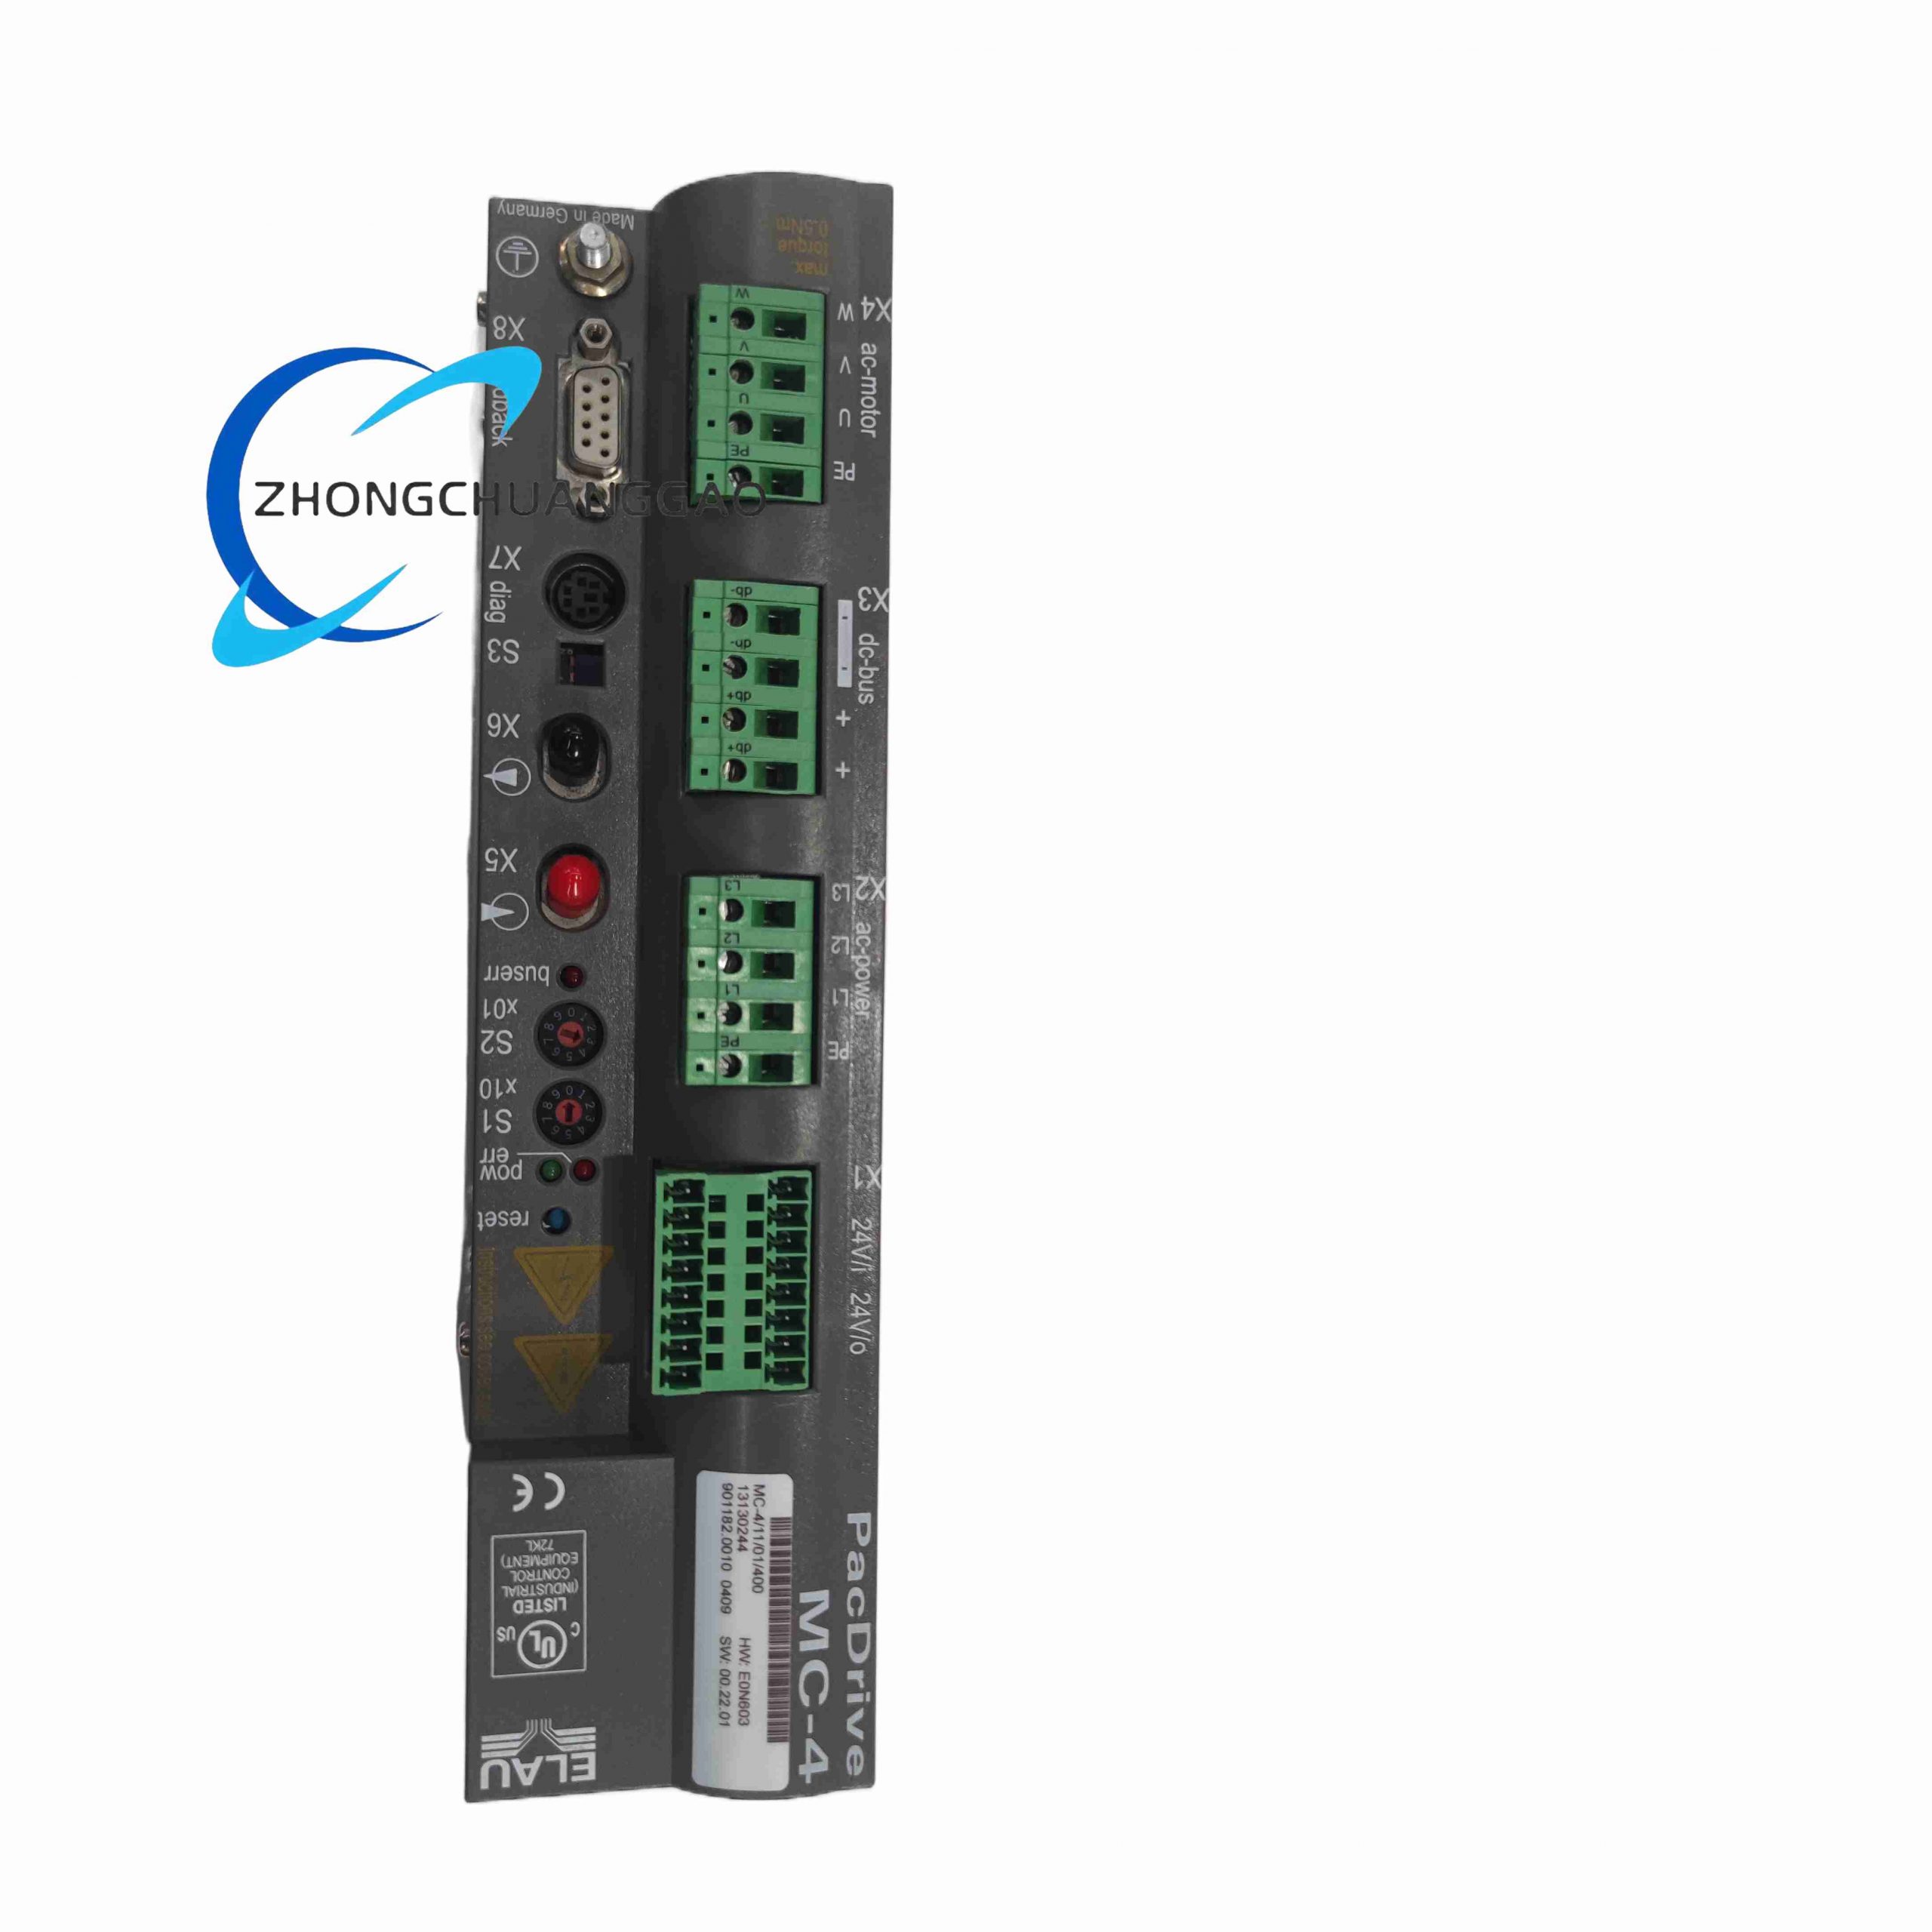
MC-41101400 is single-axis compact servo drive under Schneider PacDrive motion control ecosystem, designed to pair with MAX-4 series central motion controllers via SERCOS real-time bus for independent single AC servo motor closed-loop control. It integrates power conversion circuit, position/speed/torque triple closed-loop control algorithm, safety stop circuit and multi-channel encoder feedback interface, optimized for low-to-medium power single-axis positioning tasks on packaging and converting machinery. Fully backward compatible with legacy ELAU PacDrive system architecture after Schneider acquisition of ELAU motion division.
Description
Core Technical Performance Parameters
- Control Axis Quantity: 1 independent AC servo motor axis
- Control Modes: Position closed-loop, speed closed-loop, torque closed-loop switchable
- Communication Bus Interface: SERCOS II real-time motion bus for synchronization with MAX-4 master controller
- Encoder Feedback Support: Incremental encoder, sine/cosine encoder, absolute single/multi-turn encoder
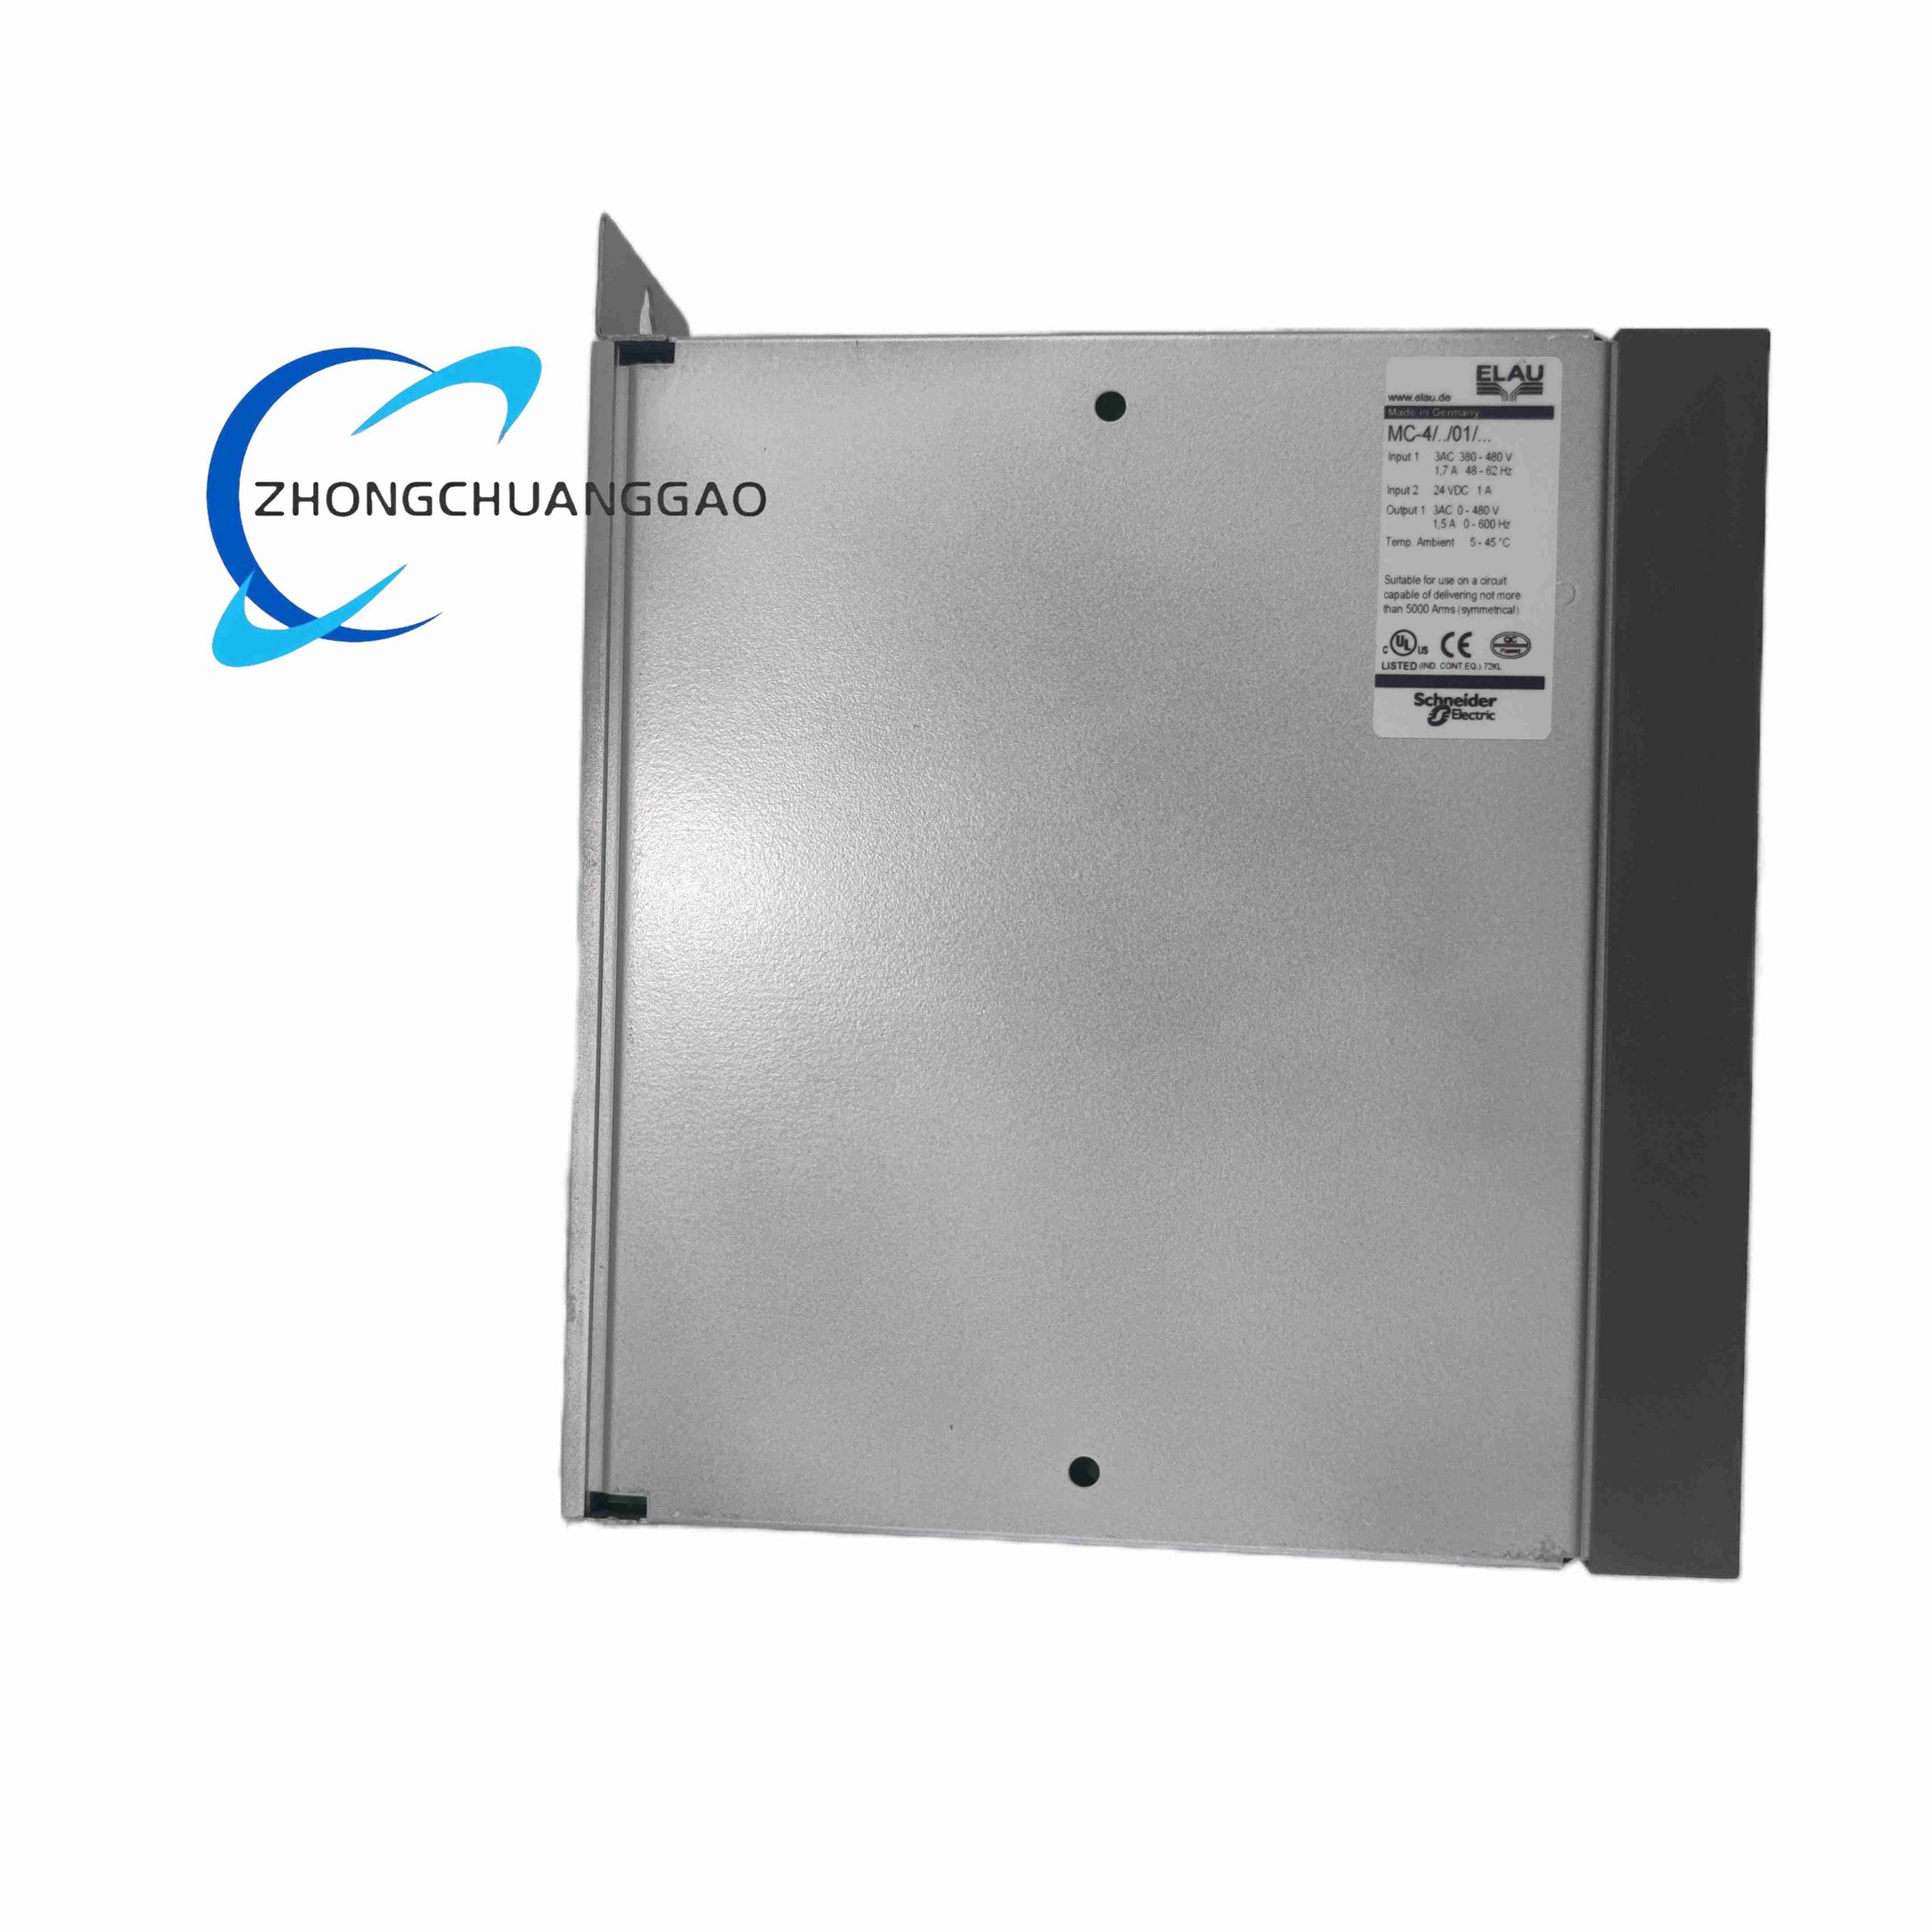
- Power Input Standard: 3-phase 200–240 VAC industrial power supply
- Built-in Safety Function: Safe Torque Off (STO) Category 3 safety stop compliant with EN 60204-1
- Environmental Operating Range: 0 °C ~ +50 °C with forced cabinet cooling
- Mounting Standard: TS35 DIN rail vertical installation
Material Composition
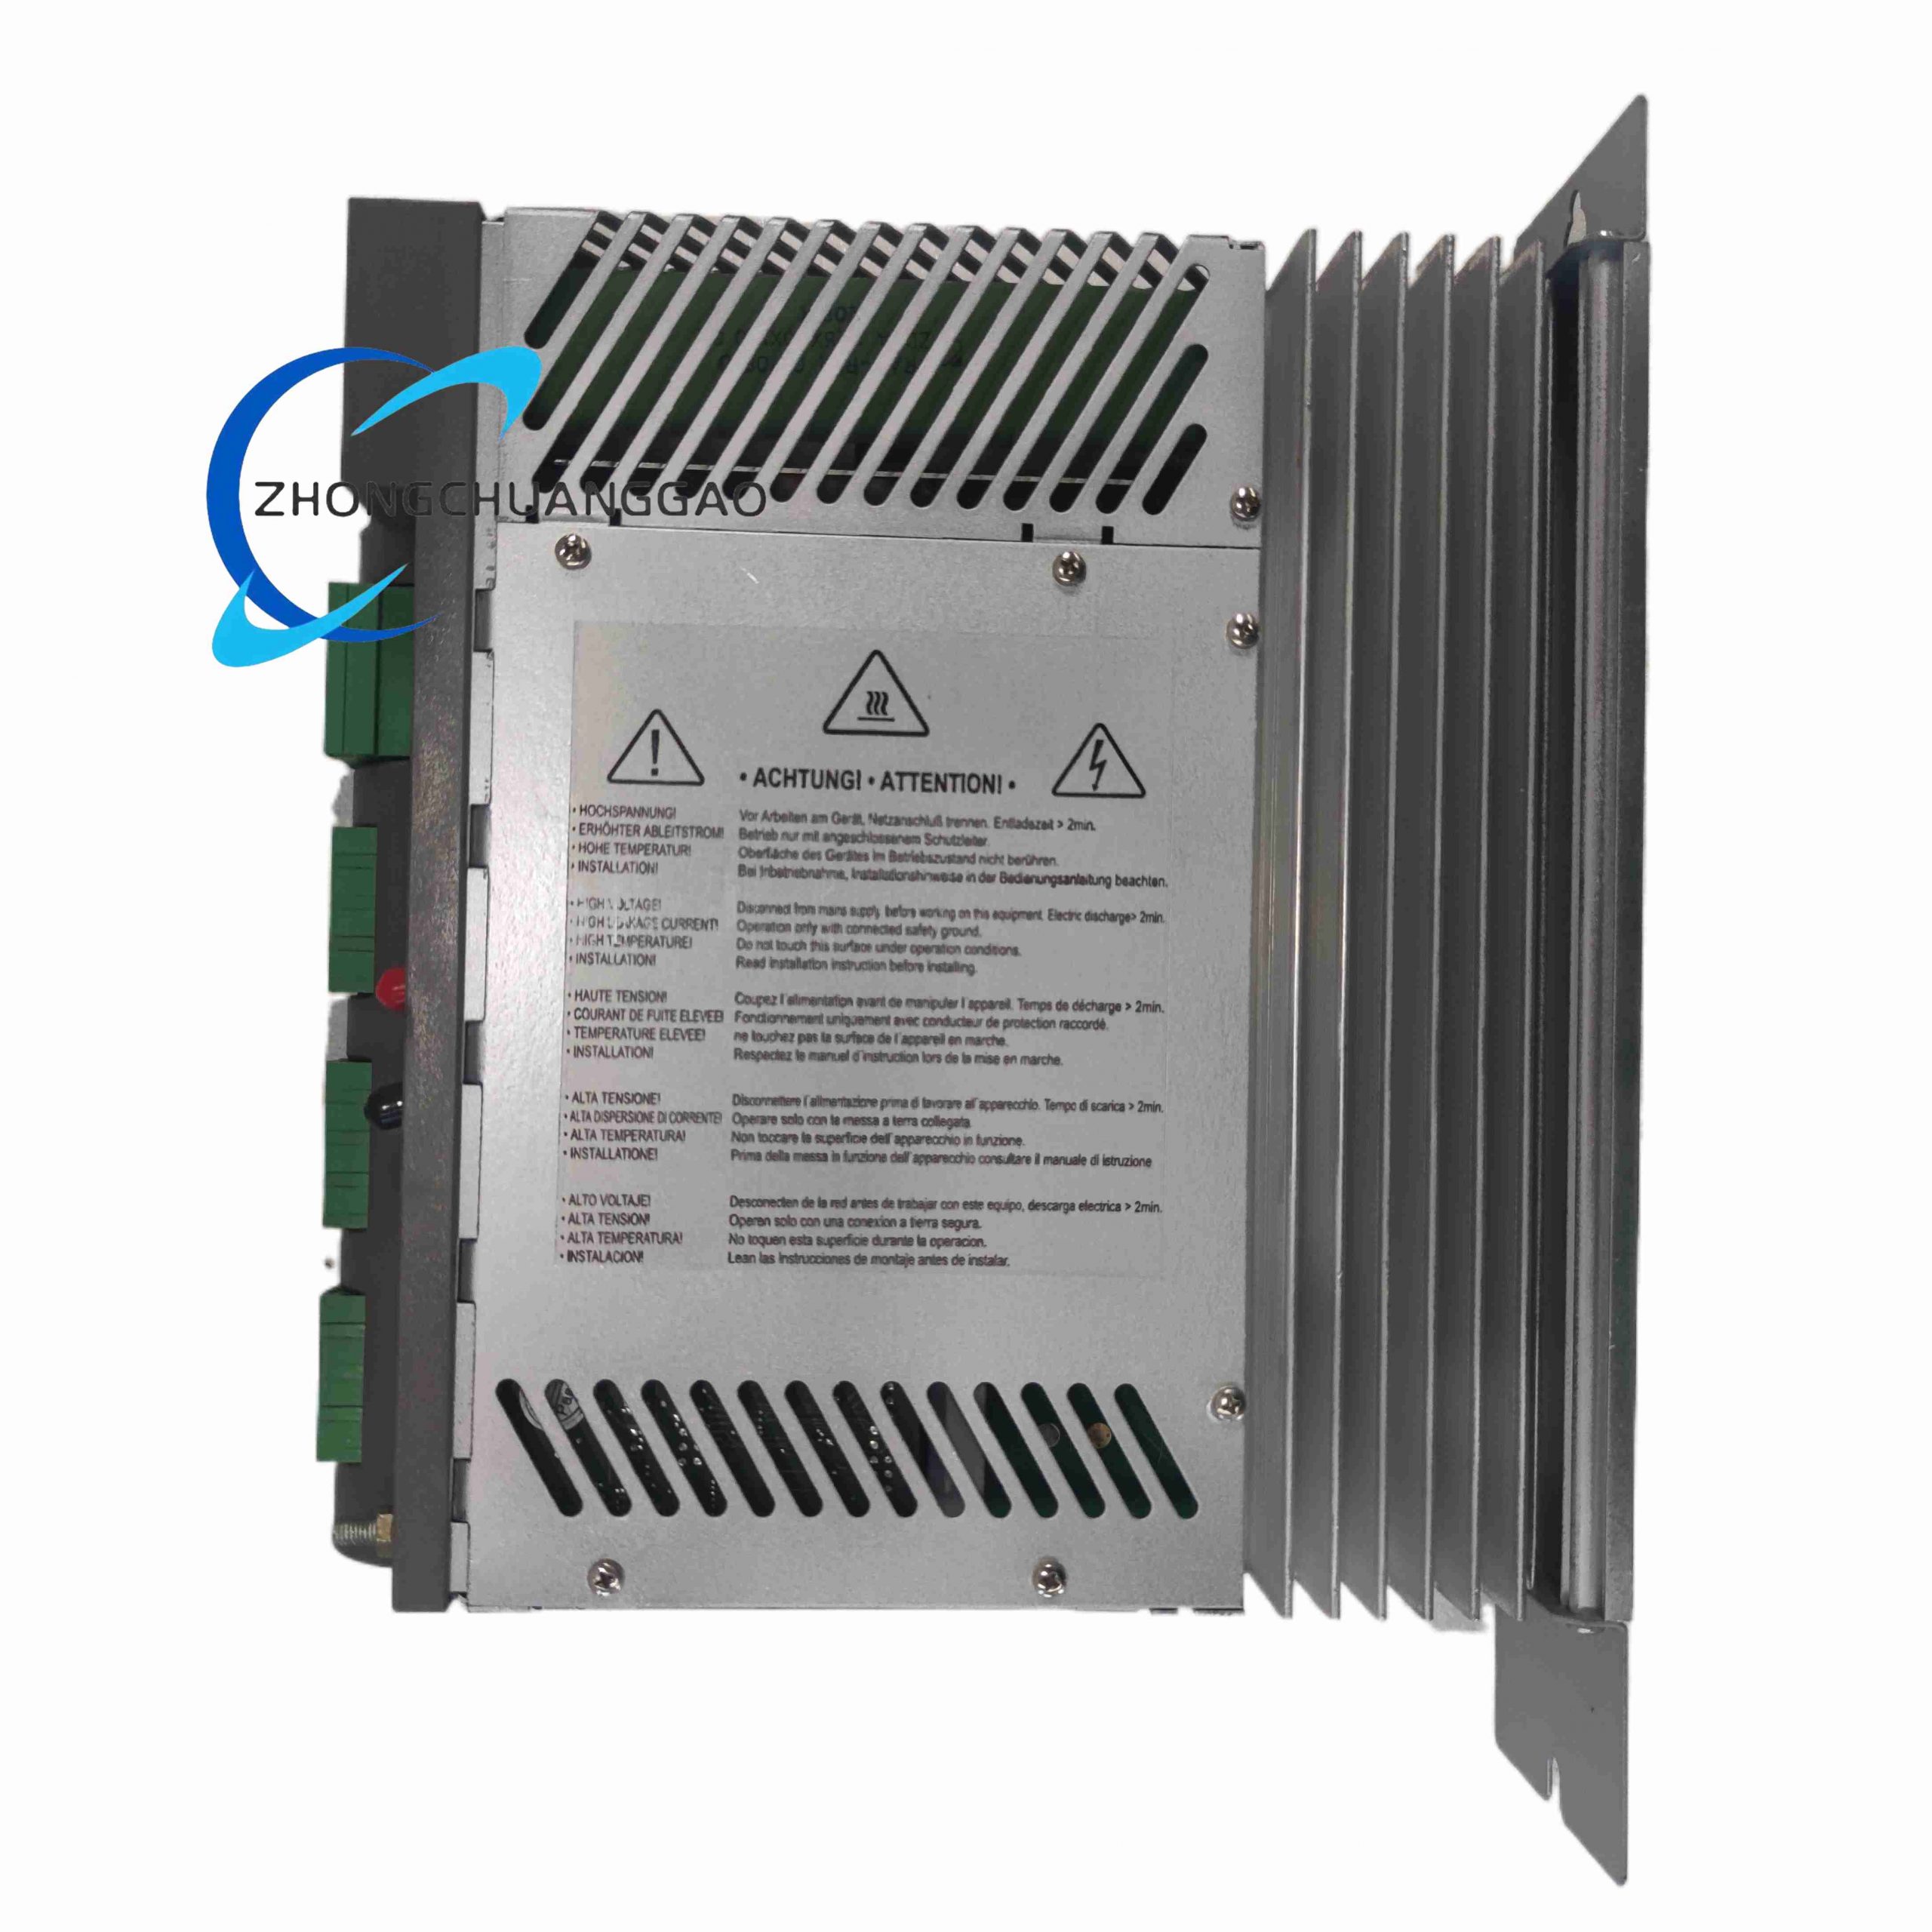
- Enclosure Shell: Cold-rolled galvanized steel sheet with oil-resistant matte coating
- Power Heat Dissipation Unit: Aluminum extruded alloy heat sink with vertical air convection fins
- Control PCB: Flame-retardant FR4 circuit board with anti-moisture conformal coating
- Terminal Connectors: Tin-plated copper spring-cage terminals with PA66 insulating base
- Bus Port Shield Housing: Nickel-plated alloy anti-EMI shielding shell
Structural Characteristics
- Slim compact single-axis DIN rail drive module, small width to save cabinet installation space
- Front panel partition layout: Power wiring terminals, motor output terminals, SERCOS bus communication port, encoder feedback port, fault status LED indicators
- Internal metal shielding partition isolates high-power drive circuit and low-signal encoder circuit to eliminate signal crosstalk
- Integrated STO safety torque-off circuit independent of main control chip, hardware-level safety protection without software dependency
- Daisy-chain SERCOS bus interface allows series connection of multiple MC-4110 series drives to single MAX-4 master controller
Working Principle
- SERCOS real-time bus receives synchronized position trajectory commands sent by upper MAX-4 motion controller every microsecond control cycle.
- Internal DSP chip compares target position value with real-time position feedback signal transmitted from motor encoder.
- Position loop, speed loop and torque loop operate sequentially to calculate required output current, driving internal IGBT power module to convert alternating current for servo motor operation.
- If STO safety circuit is triggered, power supply to motor winding is physically cut off at hardware level to eliminate output torque immediately.
- Built-in fault monitoring circuit continuously samples current, temperature and voltage parameters. Once exceeding preset limits, the drive locks output and activates corresponding fault indicator light for troubleshooting.
Installation Requirements
- Install vertically on standard TS35 DIN rail; horizontal mounting is prohibited as it obstructs natural convection cooling of the aluminum heat sink.
- Maintain minimum 15 mm vertical clearance between adjacent servo drives inside control cabinets.
- Separate motor power cables and encoder signal cables into different wiring channels. Shielded twisted-pair cables are mandatory for encoder wiring, with single-point grounding of shielding layer.
- SERCOS bus cable must follow official wiring specifications. Daisy-chain wiring terminal sequence cannot be reversed. Terminating resistor should be mounted on the last drive of the bus chain.
- Connect PE protective earth terminal reliably to cabinet ground bar to suppress electromagnetic interference.
- Ensure cabinet ambient temperature stays within rated range; install exhaust fans for continuous high-load operation.
Function & Feature Highlights
- Triple closed-loop control modes: position, speed and torque, freely switchable to satisfy diverse mechanical motion demands.
- Independent hardware-based Safe Torque Off safety function, reaching Category 3 safety level for machinery applications.
- Compatible with multiple encoder types, supporting incremental, sine/cosine and absolute encoder feedback.
- SERCOS II high-speed real-time bus enables nanoscale synchronized coordination with ELAU MAX-4 master controller.
- Built-in auto-tuning function to identify motor parameters and optimize control gain rapidly during commissioning.
- Comprehensive fault detection including overcurrent, overvoltage, undervoltage, overheating, encoder loss and wiring breakage.
- Slim DIN rail design reduces cabinet space occupation for multi-axis packaging machinery layouts.
Typical Application Scenarios
- High-speed packaging machines coordinated with PacDrive MAX-4 controller
- Pharmaceutical cartoning, filling and blister forming equipment
- Labeling machines, slitting and winding converting machinery
- Food and beverage bottling, capping and conveying automated lines
- Printing industry register control servo positioning axes
- Automated handling and palletizing auxiliary servo axes
Operation & Maintenance Precautions
- Disconnect three-phase main power and wait at least 5 minutes before opening enclosure, to allow internal DC bus capacitors to fully discharge.
- Prevent conductive dust, oil mist and water vapor from entering the drive housing.
- Use dry compressed air to clear dust accumulated on heat sink fins every three months.
- Do not disconnect encoder cables while equipment is powered on; hot plugging may damage encoder interface circuits.
- Verify STO circuit integrity regularly after machine maintenance to guarantee safety protection effectiveness.
- Avoid long-term continuous operation above 80% rated output current, which accelerates aging of internal power semiconductors.
- Firmware upgrade must be performed under stable power supply; power interruption during flashing results in firmware corruption.
Reviews
There are no reviews yet.