
Product Short Description
Product Overview
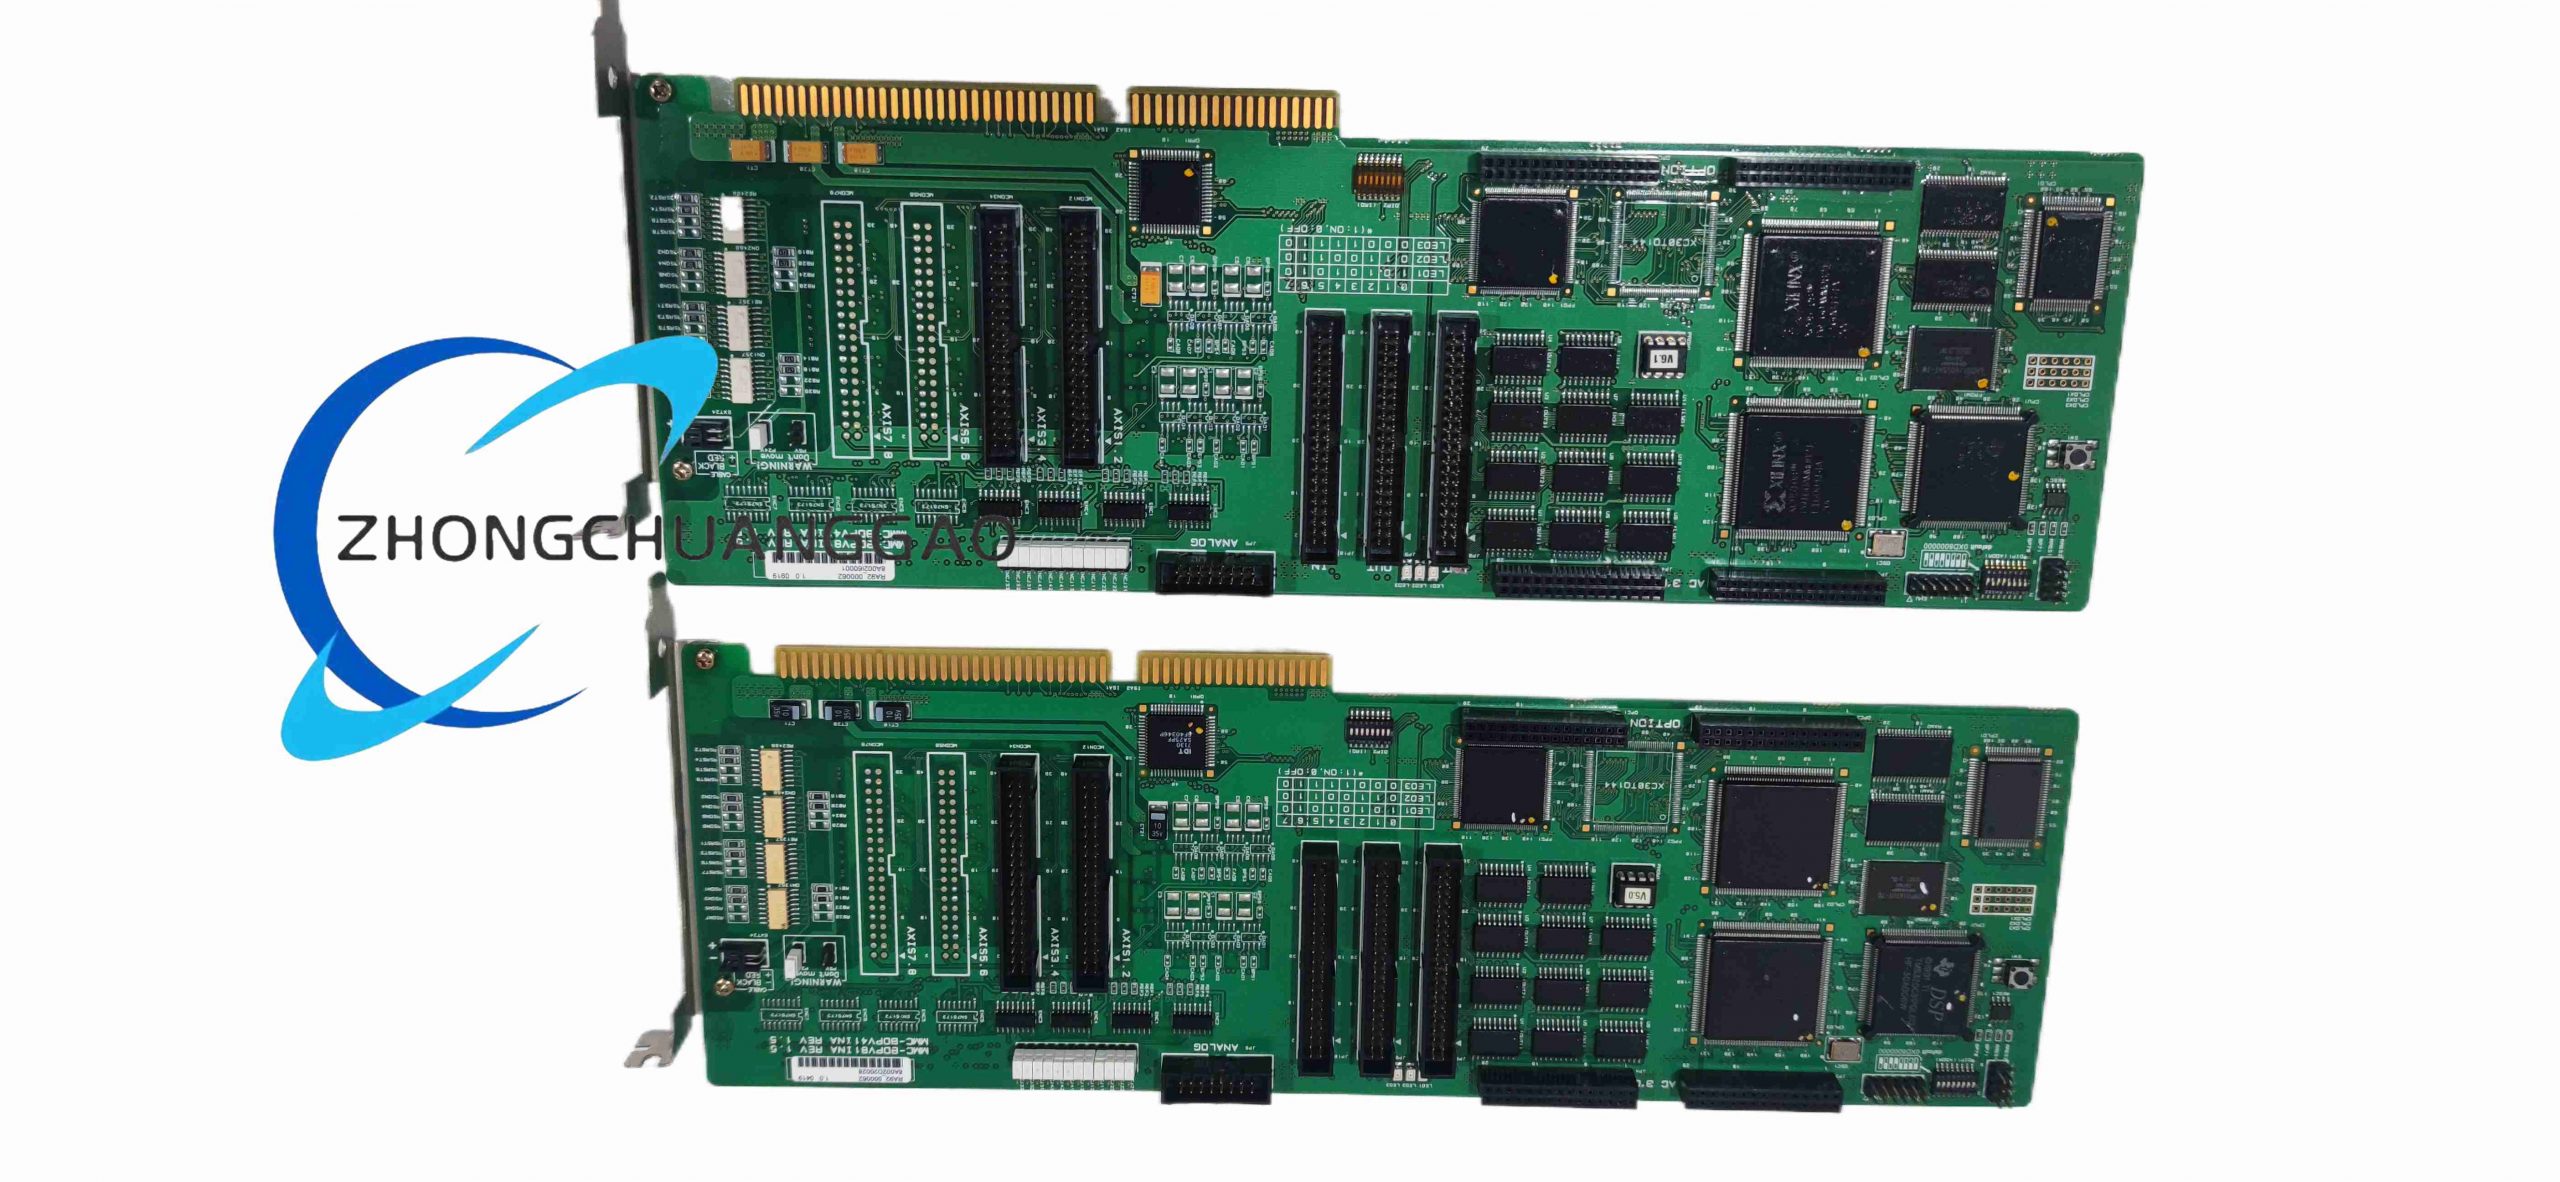
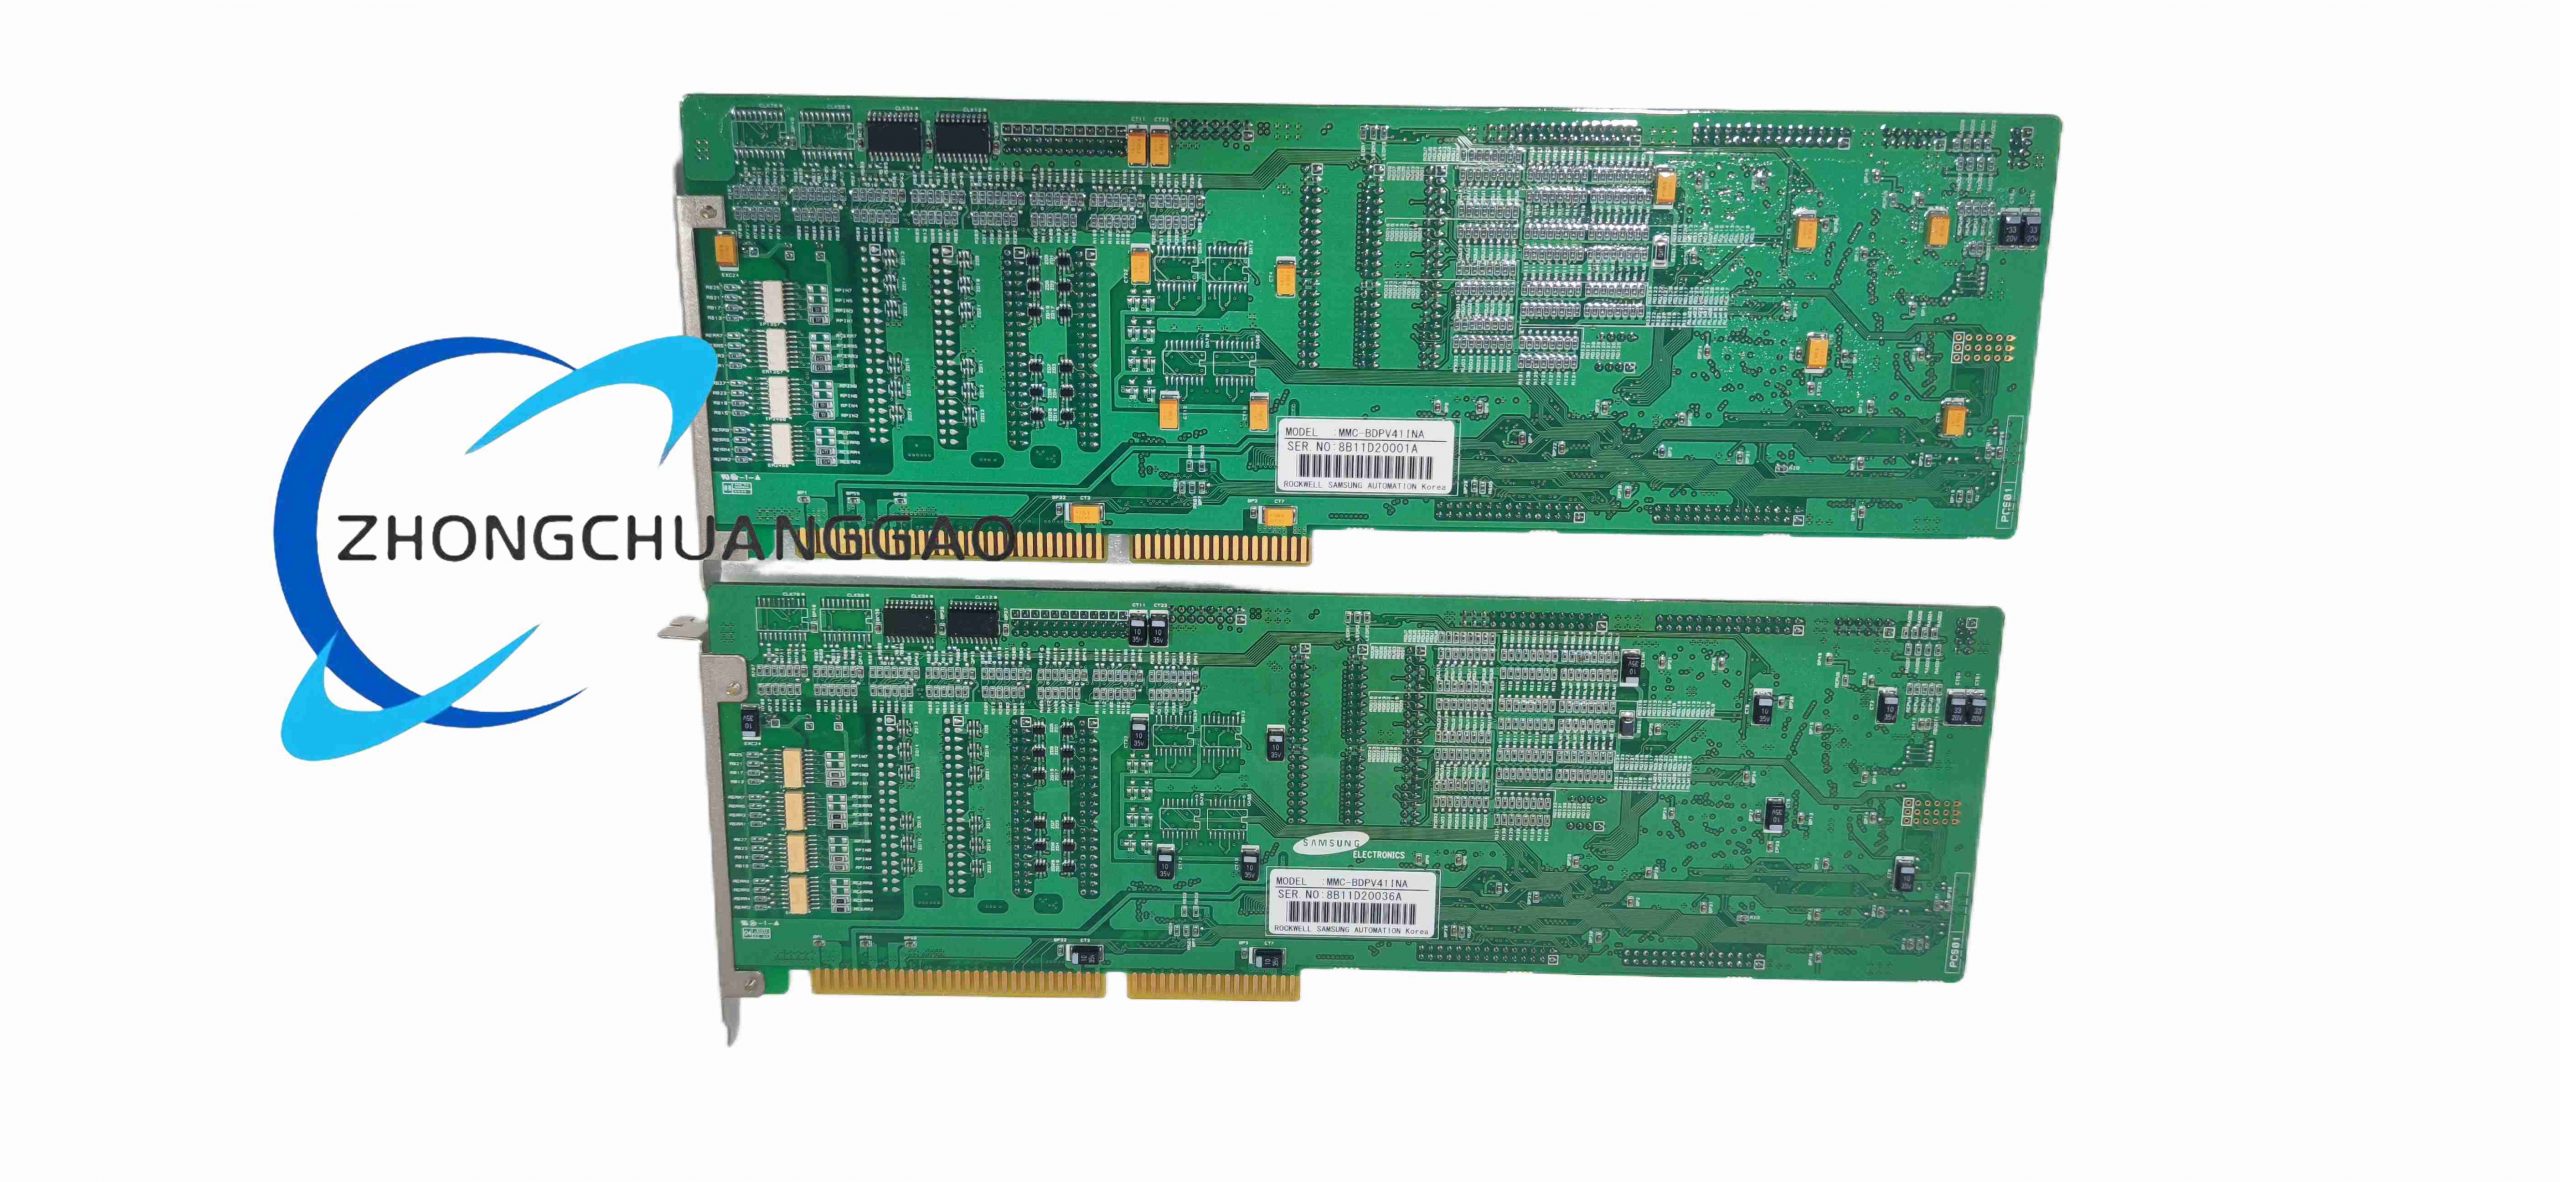
This is a dedicated closed-loop motion control processor module under Rockwell MMC motion control platform, designed for multi-servo axis synchronous coordinated control. The suffix INA denotes analog + digital hybrid I/O expansion variant, 8B15D60024A is unique factory serial trace code for hardware batch calibration. It executes complex motion algorithms including electronic cam, electronic gear, linear interpolation, circular interpolation
Description
Core Technical & Performance Parameters
- Maximum controllable axis quantity: 4 independent servo axes with synchronous interpolation
- Motion bus interface: SERCOS III high-speed digital motion bus, cycle time 125 μs minimum
- Control loop refresh rate: 8 kHz closed-loop position/torque/velocity loop calculation
- Analog I/O: 4 × ±10 V analog output, 4 × 4–20 mA analog input, 16-bit resolution
- Digital I/O: 16 sink/source configurable digital inputs (24 VDC), 12 high-speed digital outputs
- Encoder feedback support: Incremental TTL, EnDat absolute, resolver, SSI serial encoder
- Power supply: 24 VDC logic power, 1.8 A typical consumption
- Processor core: 32-bit floating-point DSP motion processor, 1 GHz clock frequency
- Onboard memory: 512 MB RAM, 1 GB non-volatile flash memory for motion program storage
- Operating temperature: -10°C ~ +55°C; Storage temperature: -30°C ~ +70°C
- Mounting standard: Rockwell standard backplane rack slot mounting, hot-plug supported
- Positioning repeatability: ±0.001 pulse unit; Electronic gear ratio range: 1:10000 ~ 10000:1
Function Features
- Independent DSP motion core offloads all trajectory planning and servo closed-loop computation from main PLC controller, eliminating real-time delay of multi-axis interpolation.
- Rich motion function library: Linear/circular/spiral interpolation, electronic cam curve generation, master-slave electronic gearing, flying shear synchronization, multi-axis gantry synchronous control.
- Hybrid analog/digital I/O integrates sensor signal collection and auxiliary actuator control without separate expansion modules.
- Multi-feedback compatibility: Supports all mainstream servo encoder signal formats for cross-brand servo drive integration.
- Built-in motion fault diagnosis logic: Axis overtravel, following error excess, encoder loss, servo drive communication breakage real-time alarm with fault code storage.
- Support IEC 61131-3 standard programming languages (Structured Text, Ladder Diagram, Function Block Diagram) via Studio 5000 Logix Designer software.
- Hardware fault self-test on power-up, real-time backplane communication health monitoring, redundant backplane communication support for critical equipment.
Material Composition & Structural Characteristics
- Module front panel: Black ABS flame retardant plastic with LED status indicators (Power, Run, Fault, Axis Link) and DIP configuration switches.
- Main control PCB: Multi-layer industrial FR4 board with gold-plated backplane connector pins to resist oxidation under long-term rack operation.
- Internal heat dissipation: Passive aluminum heat sink attached to DSP processor, no fan design to avoid dust accumulation failure.
- Terminal interface block: Spring-clamp screw terminals for analog/digital I/O wiring, UL94-V0 flame retardant plastic housing.
- Rack connector: Nickel-plated copper multi-pin backplane connector with locking latch for secure rack installation.
Working Principle
Motion program logic downloaded from Rockwell Logix controller is stored in onboard flash memory; DSP processor executes trajectory planning at 8 kHz cycle, generates real-time position command values transmitted to servo drives via SERCOS III bus. Encoder feedback signals returned from each servo motor are collected and processed to calculate following error, adjusting torque/velocity command output in closed-loop cascaded control. Analog input channels collect external process sensor signals to modify motion target positions dynamically, digital outputs trigger auxiliary clamping, cutting, and indexing actuators synchronously with axis movement. All fault events are logged to non-volatile memory for post-failure analysis.
Installation Requirements
- Install module into designated slot of Rockwell standard control backplane; fully engage backplane connector and lock front panel latch to prevent loose contact during vibration.
- Backplane power supply must provide stable 24 VDC ±5% logic power; install surge suppression filter on power input for high EMI factory environments.
- Motion bus SERCOS cable must use double-shielded dedicated motion cable, separate from power cables with minimum 30cm routing clearance.
- Analog signal wiring: Use twisted shielded pair cables for 4–20 mA / ±10 V analog I/O; cable shield single-point grounded at module terminal side only to eliminate ground loop noise.
- Maintain 1 slot empty space between high-power modules and this motion control module for heat dissipation.
- Cabinet ventilation requirement: Ambient air circulation speed ≥0.3 m/s if continuous full 4-axis interpolation operation.
Application Scenarios
Semiconductor packaging equipment, automated CNC multi-axis gantry systems, printing press register control, metal stamping flying shear production lines, robotic palletizing multi-joint coordination, lithium battery winding equipment, optical inspection precision positioning platforms.
Operation & Maintenance Precautions
- Motion program download must be completed before automatic production; online program modification during operation triggers axis emergency stop protection.
- Do not hot-swap the module during running production cycle; backplane communication interruption causes uncontrolled servo axis runaway risk.
- Analog input signal wiring cannot be bundled with AC power cables; induced interference leads to motion positioning drift.
- Clear fault history log regularly every 3 months; full log storage occupies flash memory and slows down fault diagnosis response speed.
- Avoid operating at ambient temperature above 55°C for continuous 24-hour production; overheating reduces DSP calculation accuracy and shortens service life.
- Verify SERCOS bus communication cycle parameter matching with servo drive firmware version before commissioning; mismatched cycle time causes axis vibration and following error alarms.

Reviews
There are no reviews yet.