
Product Short Description
Product Brief Introduction
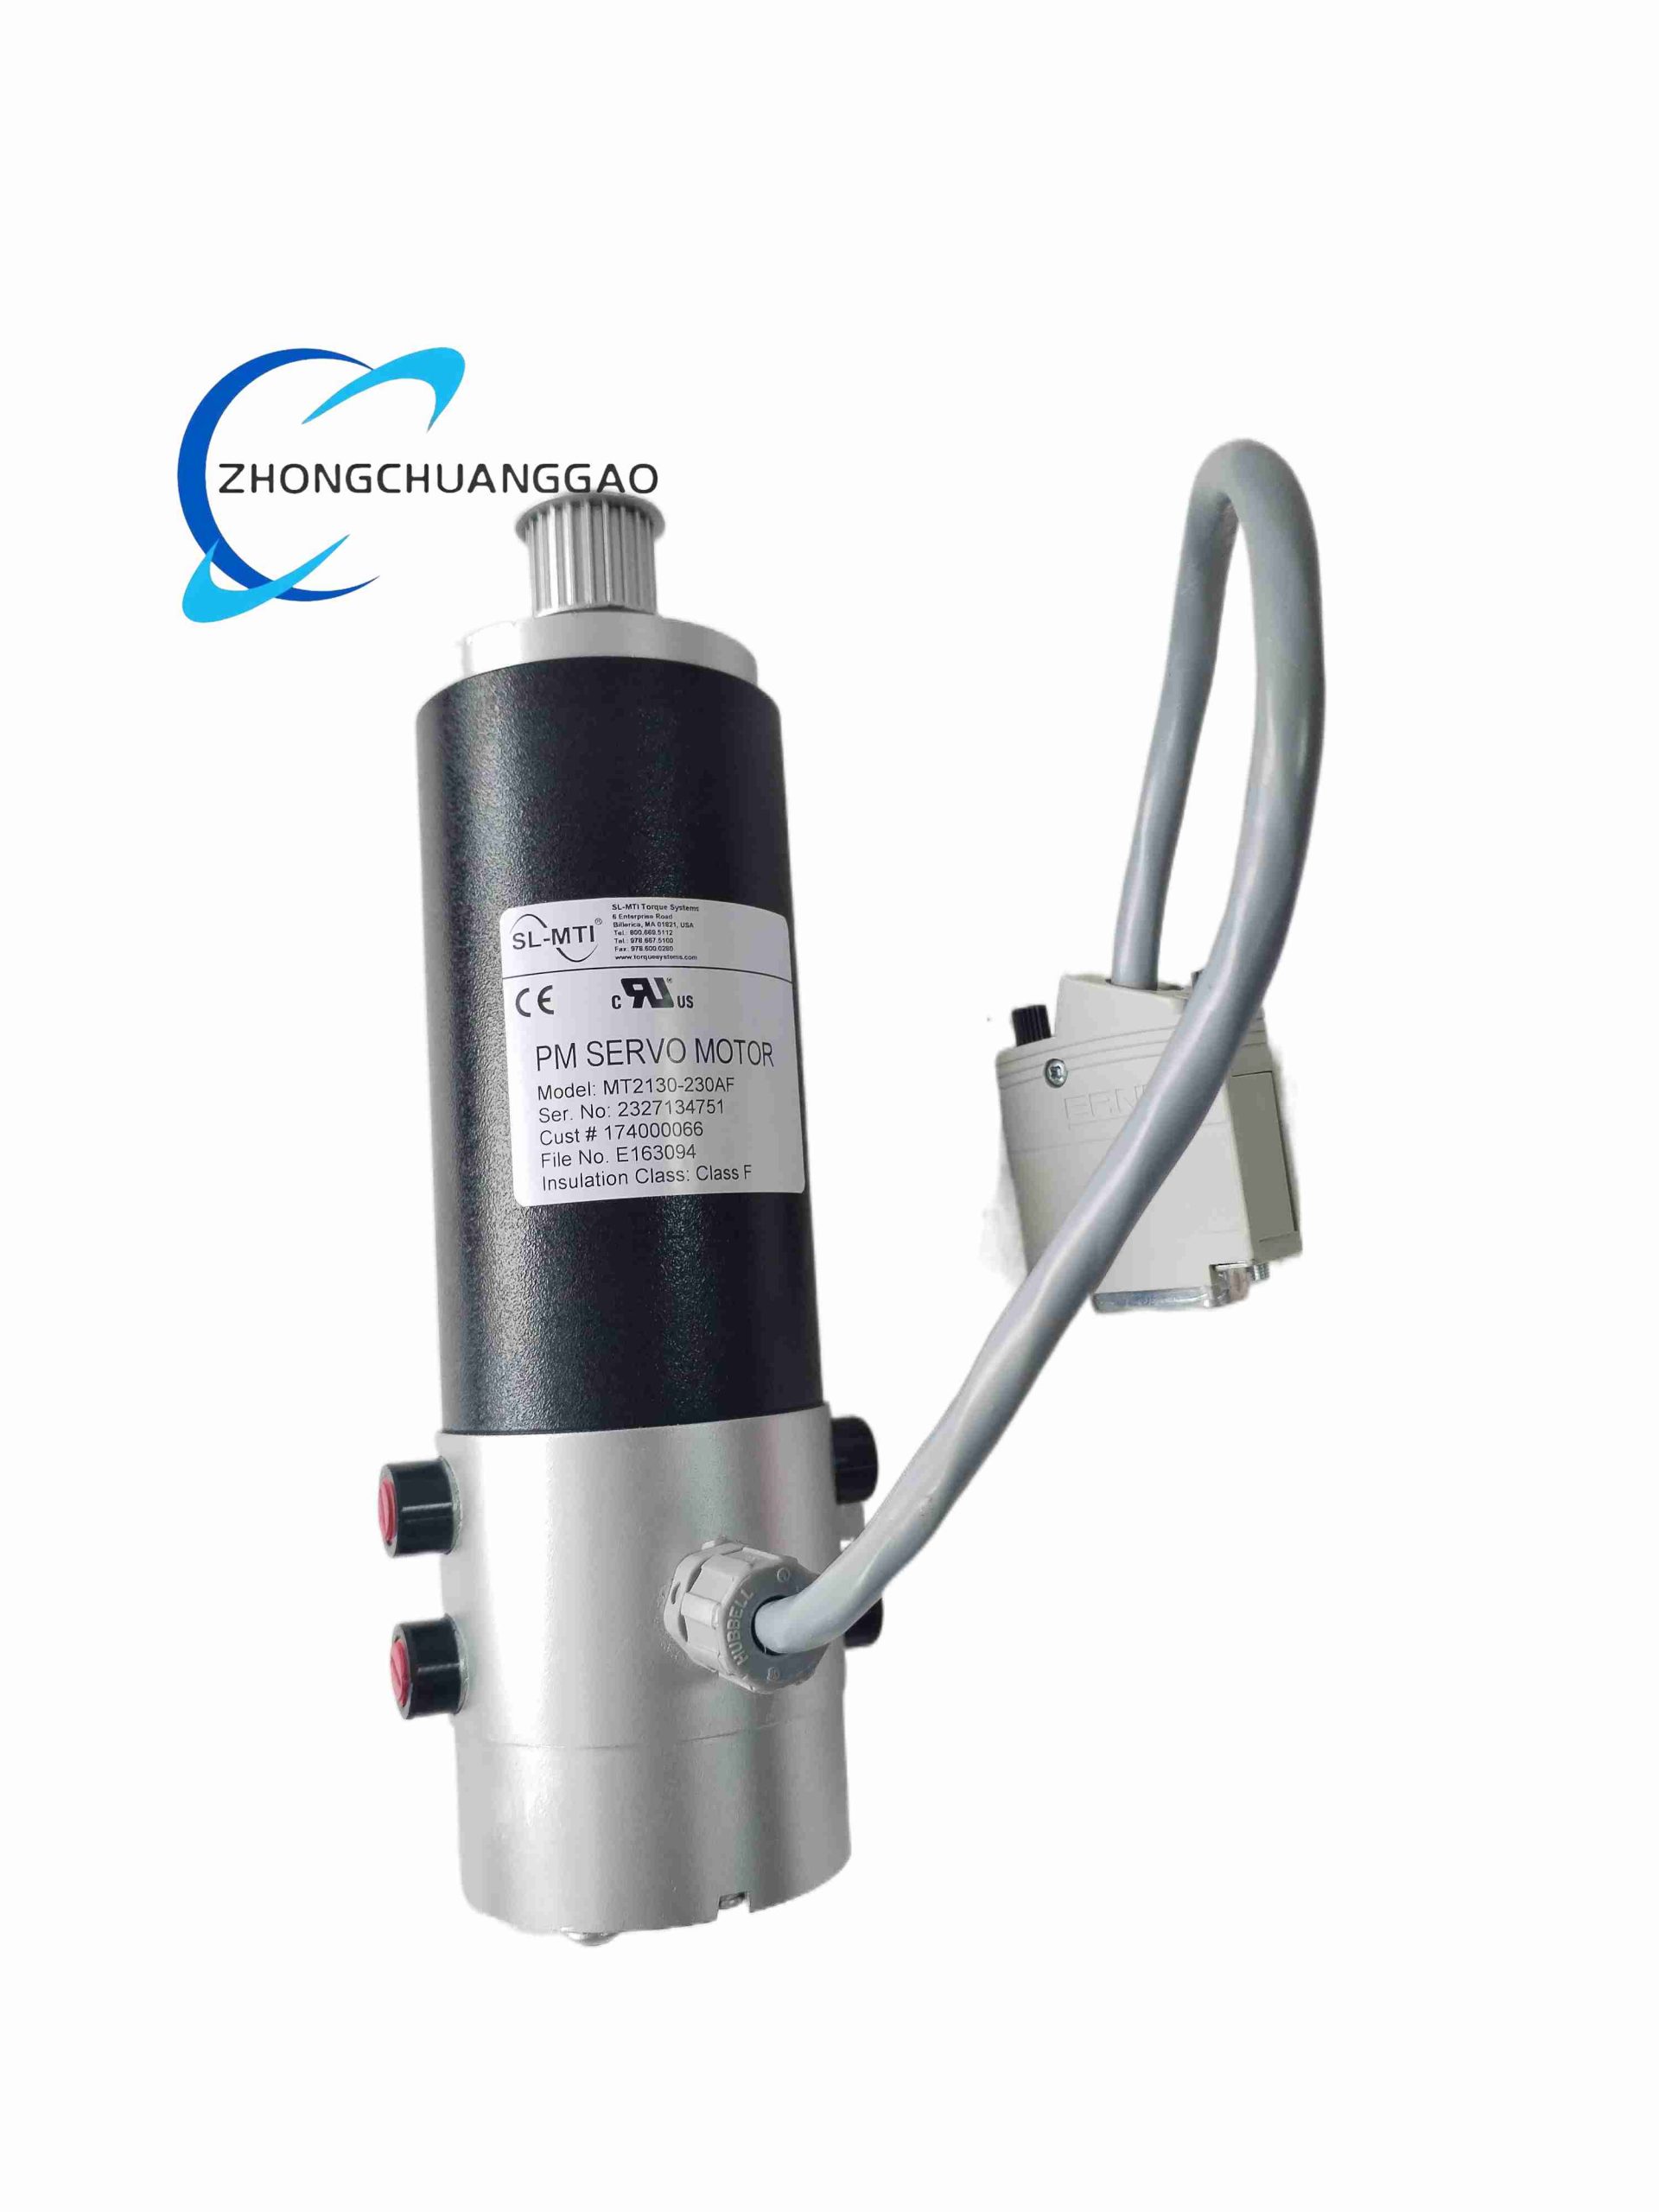
This is a high-torque compact brushed DC servo motor designed by SL-MTI Torque Systems, optimized for continuous low-speed high-torque closed-loop motion control. It delivers stable stall torque with low cogging torque, F-class high temperature insulation, and integrated position feedback mounting interface, widely deployed in precision positioning machinery, test benches and automated rotary actuators.
Description
Core Technical & Performance Parameters
- Model Code: MT2130-230AF
- Motor Type: PM Brushed DC Servo Torque Motor
- Peak Torque Output: 2.11 N·m
- Insulation Class: Class F (155°C maximum winding temperature)
- Net Weight: 1.96 kg
- Frame Size: Standard compact industrial servo frame
- Shaft Configuration: Single solid output shaft with keyway for load coupling
- Enclosure Protection Grade: IP54 (standard factory finish)
- Operating Ambient Temp: -20°C ~ +70°C
- Storage Temperature: -40°C ~ +85°C
- Vibration Resistance: IEC 60034-14 Grade B
- Certification: CE, RoHS, UL recognized winding insulation
Functional Features
- Ultra-low cogging torque for smooth constant-speed rotation at near-zero RPM
- High overload peak torque capacity for rapid acceleration and shock load handling
- Class F high-temperature winding insulation to sustain long continuous duty cycles
- Standard rear encoder mounting flange, compatible with most incremental / absolute rotary encoders
- Robust double ball bearing support for long service life under radial and axial mechanical loads
- Low electromagnetic interference winding design to avoid signal distortion near analog sensors
- Modular terminal wiring block for quick power and feedback harness connection
Working Principle
Permanent magnet rotor generates fixed magnetic field; DC current applied to stator windings creates alternating electromagnetic torque to drive shaft rotation. Built-in magnetic flux compensation minimizes torque ripple during variable load conditions. External encoder provides real-time position/speed feedback to servo drive for closed-loop PID torque, velocity and position regulation. The torque-dedicated winding layout prioritizes stall torque output over maximum rotational speed.
Material Composition
- Motor Housing: Die-cast aluminum alloy with black anodized anti-corrosion coating
- Stator Lamination: High-grade silicon electrical steel sheet to reduce iron loss
- Rotor Magnets: High-energy rare-earth neodymium permanent magnets
- Shaft: High-strength quenched alloy steel, surface ground for precision fit
- Brush Assembly: Copper-graphite composite wear-resistant brushes
- Terminal Block: Flame-retardant PA66 engineering plastic
- Bearings: Chromium alloy steel sealed ball bearings with high-temperature grease
Structural Characteristics
- Cylindrical compact monoblock housing for space-limited equipment integration
- Front flange mounting hole pattern for direct bolt-on installation to machine frames
- Separated power wiring terminal area and encoder feedback connector at rear end cap
- Sealed brush access cover for periodic brush replacement without full motor disassembly
- Integrated heat sink fin structure on housing surface for passive heat dissipation
- Double bearing axial spacing to suppress shaft deflection under offset radial loads
Installation Requirements
- Mount via front flange with Grade 8 alloy steel bolts, evenly torque fasteners to prevent housing deformation
- Maintain minimum 20mm air clearance around motor housing for natural convection cooling
- Shaft coupling must include flexible bellows coupler to eliminate side load and axial thrust on output shaft
- Wire power cables with shielded twisted pair; ground shield single-ended at servo drive cabinet only
- Encoder cable separate from high-current motor power cable, minimum 15cm wiring separation to reduce EMI
- Horizontal mounting recommended; vertical mounting allowed only with factory-specified top-side heat sink orientation
- Ambient installation location must avoid direct liquid splash, oil mist accumulation and continuous UV exposure
Application Scenarios
- Precision rotary test stands for automotive component torque testing
- Automated rotary indexing tables for semiconductor assembly equipment
- Low-speed high-torque valve actuator drive systems
- Medical lab precision positioning rotary stages
- Winding machinery tension control small rotary axes
- Aerospace component durability fatigue test benches
Operation & Maintenance Precautions
- Do not exceed rated peak torque for more than 3 consecutive seconds to avoid permanent magnet demagnetization
- Check brush wear every 1,000 operating hours; replace brushes when residual length < 3mm
- Never run motor without encoder feedback signal, as open-loop operation causes uncontrolled over-speed
- Avoid continuous operation at ambient temperature above 65°C without auxiliary forced air cooling
- Keep shaft keyway and coupling surfaces clean of metal debris to prevent unbalanced rotation
- Do not apply radial impact force directly to output shaft during installation or transportation
- Store unused motors in dry dehumidified environment with shaft horizontal support to prevent bearing indentation
Reviews
There are no reviews yet.