
Product Short Description
Product Brief Introduction
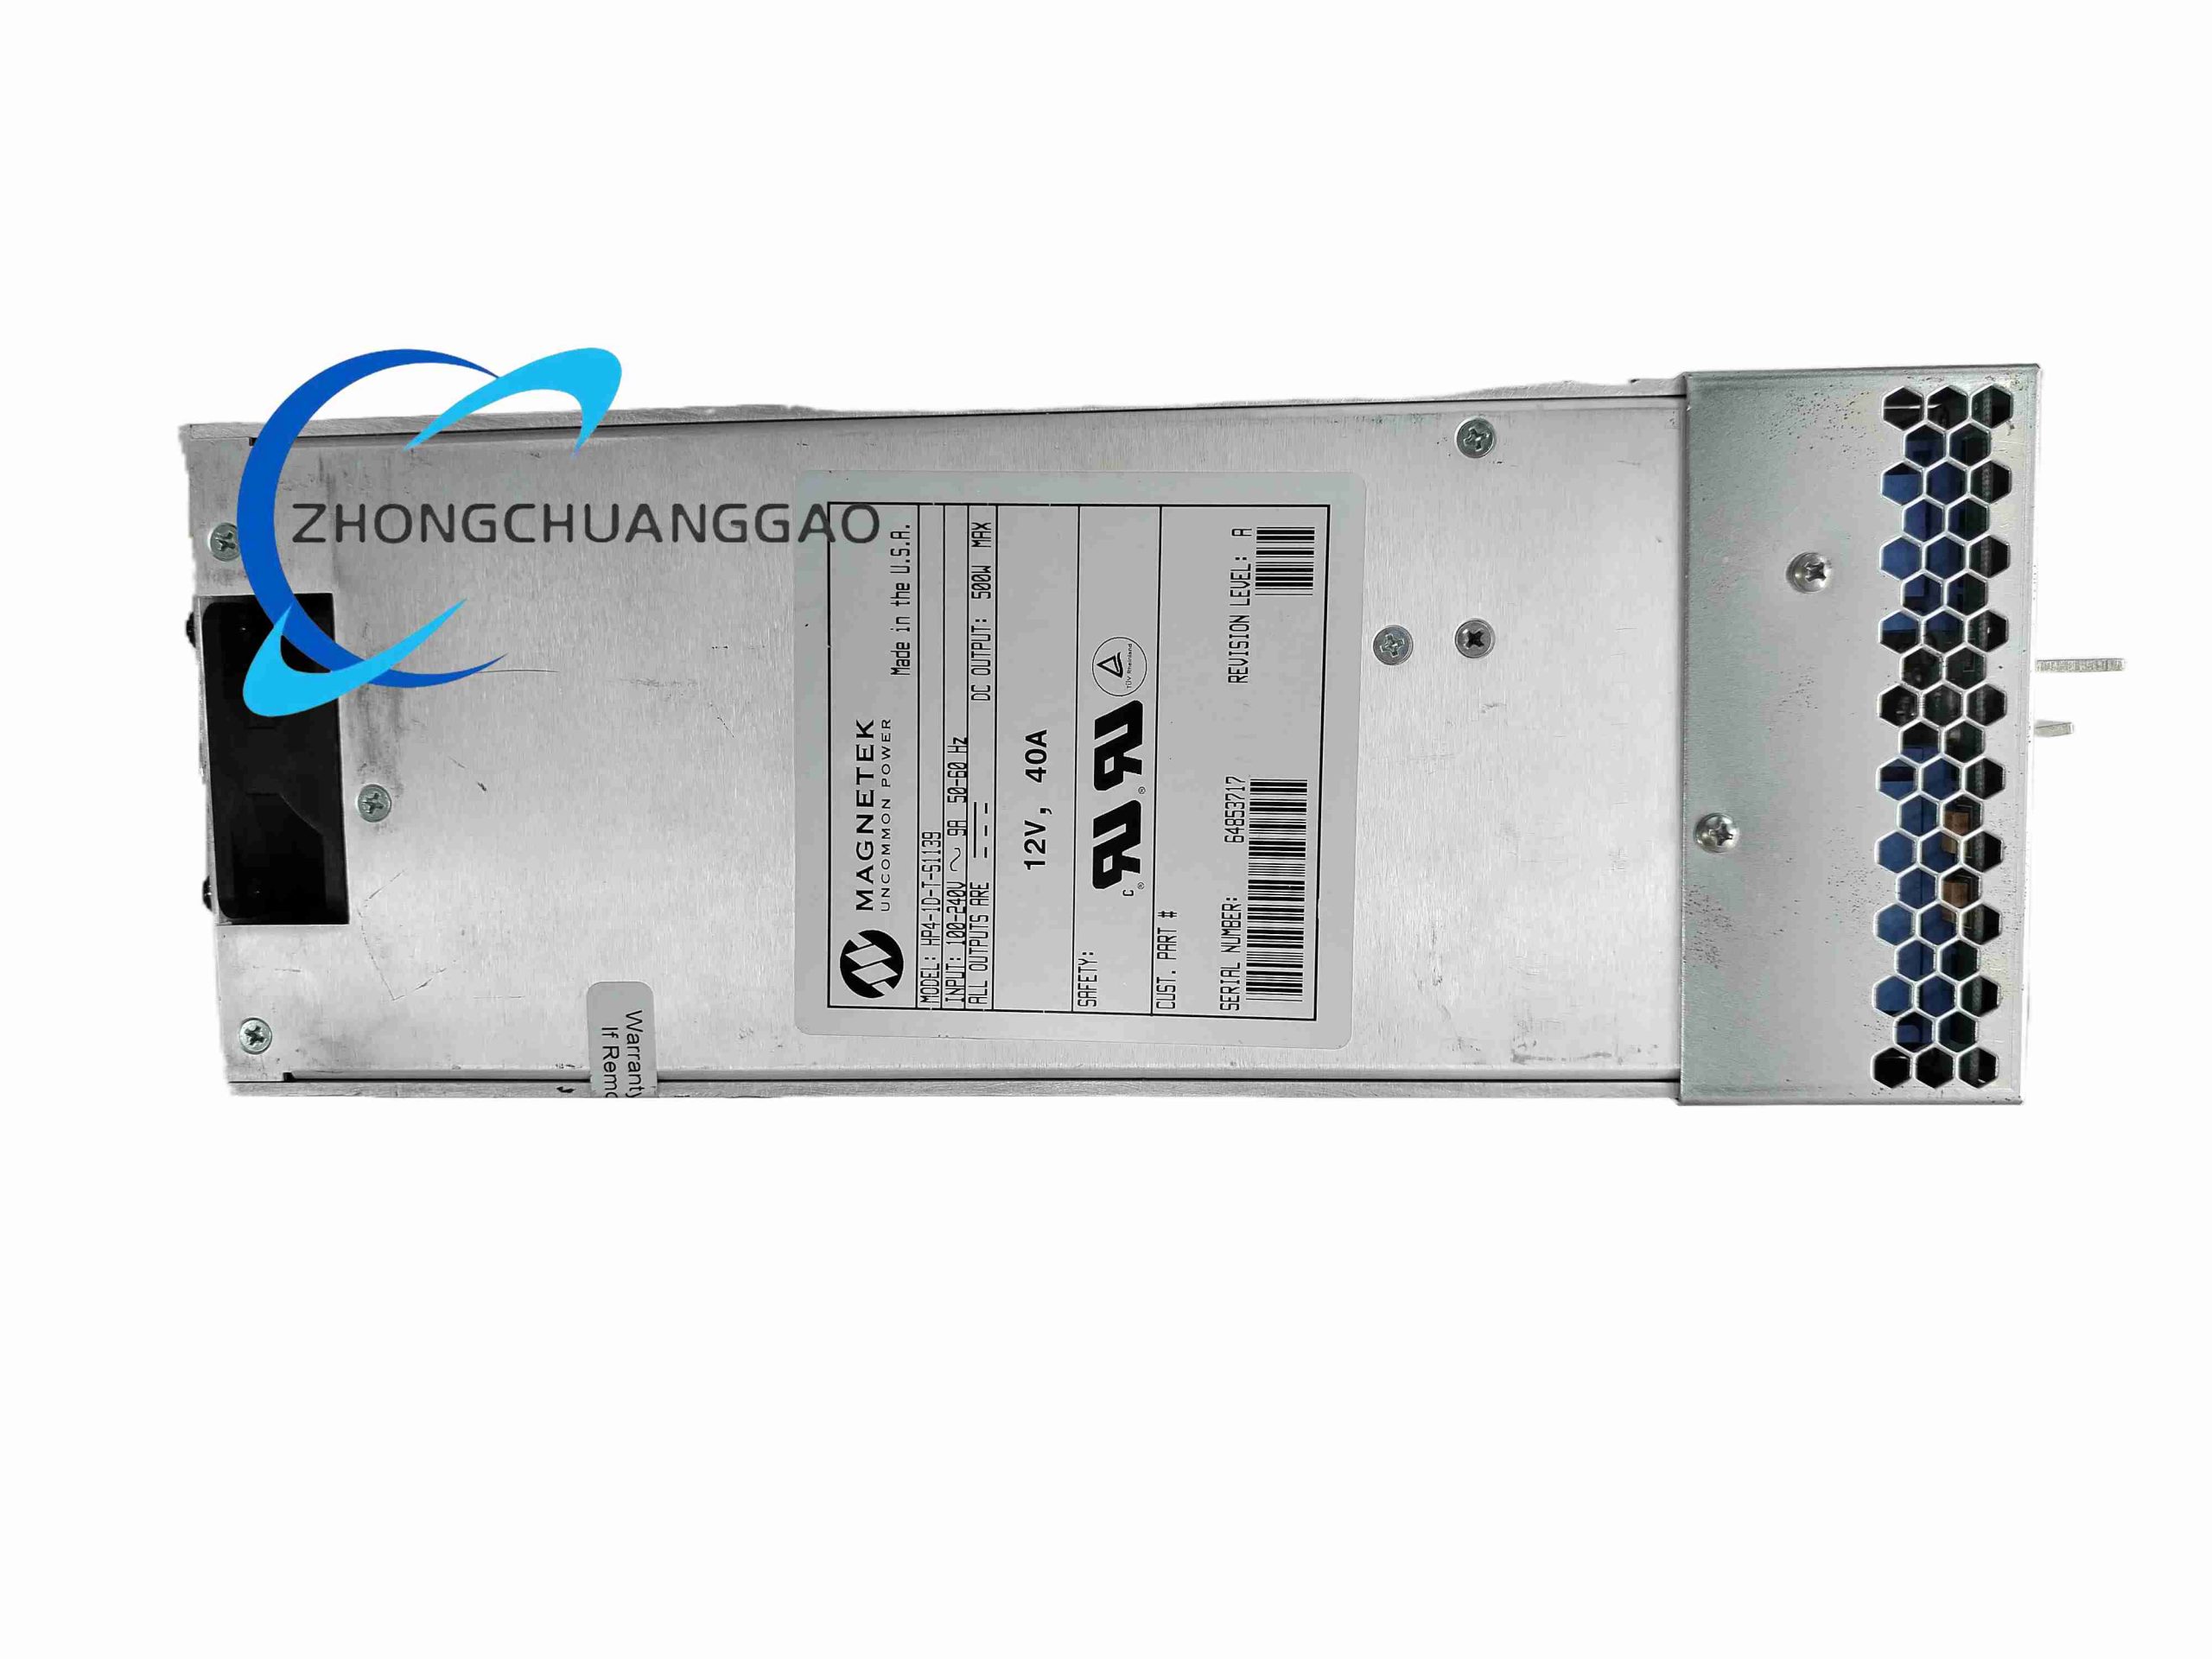
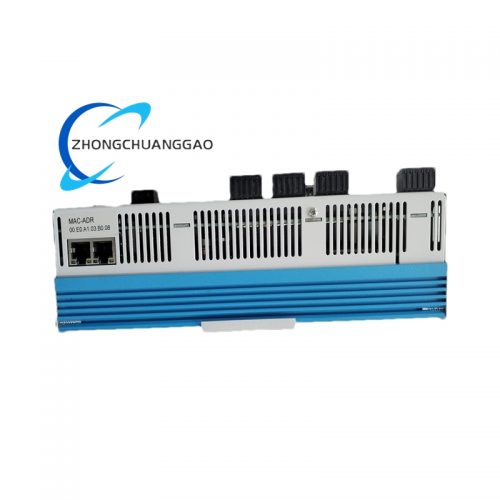
Magnetek HP4-1D-T-S1139 is high-performance four-quadrant DC drive control module designed for heavy industrial DC motor closed-loop speed regulation. It achieves ±0.1% ultra-precise speed stability, supports forward/reverse motoring and regenerative braking four-quadrant operation, integrates analog/digital signal interfaces compatible with GE Series 90-70 PLC systems, widely used in paper mill winding, mining hoist heavy load DC motor control.
Description
Core Technical Specifications
- Control Mode: Full four-quadrant bidirectional DC motor control with regenerative energy braking
- Speed Regulation Precision: ±0.1% steady-state speed error via high-resolution PID closed-loop algorithm
- Control Signal Input: Analog 0–10V, 4–20mA speed setpoint; optional Profibus DP digital communication adapter
- Digital I/O Interface: 8-channel digital input / 8-channel relay output for fault, enable, direction interlock signals
- Power Capacity: Max continuous 500W DC output power for shunt-wound DC armature motors
- Enclosure Protection Class: IP20 cabinet internal mounting design
- Operating Temperature: -15°C ~ +60°C industrial workshop environment
- Communication Compatibility: Seamless signal matching with GE IC697 Series PLC via Profibus DP expansion card
- Physical Structure: Standard rack plug-in module dimension 126(W) × 124(H) × 22(D) mm, CPCI industrial rack mounting
- Weight: 0.1kg single module
Function & Performance Features
- Four-quadrant operation eliminates paper tearing, material stretching defects during winding/unwinding by smooth regenerative braking speed adjustment
- Built-in speed search function detects coasting motor residual rotation speed after momentary power loss, direct restart without full stop
- Multi-stage overcurrent, overvoltage, armature overload thermal protection logic to prevent DC motor winding burnout
- Comprehensive fault diagnostic system: Over-speed, field loss, power phase loss, thermal overload with coded fault register for PLC reading
- Flexible parameter configuration via front panel debug port or upper PLC digital communication bus
- Anti-jitter low-pass filtering algorithm suppresses industrial power grid noise interference to speed setpoint signal
- Regenerative braking energy recycling circuit reduces factory power consumption for continuous winding load equipment
- Modular plug-in hot-swappable design minimizing production line downtime during maintenance replacement
Working Principle
The drive module receives speed reference setpoint signal (analog/digital) from upper PLC controller, compares target speed with armature tachometer feedback signal via high-precision PID controller. Internal power IGBT power stage adjusts armature DC voltage polarity and amplitude to realize forward/reverse rotation and regenerative braking four-quadrant motion. Regenerative kinetic energy from decelerating motor is fed back to DC bus power supply circuit for energy recovery. Built-in real-time current/temperature monitoring circuit triggers protection shutdown and fault output relay signal when exceeding motor rated operating limits, transmits fault status data to PLC via Profibus communication bus.
Material & Structural Characteristics
- Main Circuit Board: Double-sided heavy copper industrial power PCB with high-temperature solder for power IGBT heat resistance
- Housing Frame: Black plastic flame retardant UL94-V0 frame, aluminum alloy heat sink for power semiconductor cooling
- Connection Interface: CPCI gold-plated backplane connector anti-oxidation long-term rack contact stability
- Front Debug Port: Sealed mini USB port with dust cap for parameter tuning and fault data download
- Passive heat dissipation aluminum fin heat sink attached to power IGBT components
Installation Requirements
- Plug into standard industrial CPCI control rack with dedicated power backplane, ensure full gold-plated connector insertion lock
- Maintain ≥15mm vertical gap between adjacent drive modules for heat convection cooling
- Rack cabinet equipped with forced ventilation fan to keep internal ambient temperature below 50°C
- Separate high-current motor armature power wiring and low-voltage control signal wiring into isolated cable trays
- Install external fast-blow fuse rated 10A on DC armature output circuit for short-circuit protection
- Rack protective earth terminal connected to factory ground grid to reduce EMI noise on analog speed signals
Typical Application Scenarios
- Paper mill winding/unwinding DC motor constant tension speed control
- Mining underground hoist four-quadrant lifting/lowering motor regenerative control
- Metal foil slitting, textile fabric winding precision tension regulation
- Printing press main drive DC motor closed-loop speed stabilization
- Elevator heavy-load industrial hoist regenerative braking control
- Plastic film extrusion winding production line constant linear speed control
Operation & Maintenance Precautions
- Complete PID speed loop parameter matching with DC motor tachometer before full load production operation
- Monthly inspection of rack backplane connector gold plating oxidation, clean contact surface with industrial contact cleaner if signal drift occurs
- Disconnect rack main AC power supply before plug/unplug HP4 drive module to avoid IGBT power stage surge damage
- Regular heat sink dust removal every 2 months in paper mill fiber dust environment to prevent over-temperature protection shutdown
- Regenerative braking circuit capacitor aging test annually for long-term continuous production equipment
- Do not modify internal power circuit components; disassembly voids factory performance warranty
- Record all optimized tension/speed PID parameter values before factory reset of module configuration
Reviews
There are no reviews yet.